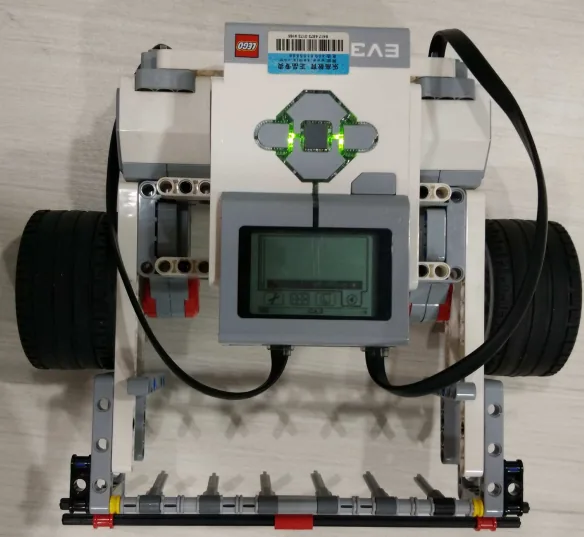
Today you build 5 min

Hi! Balls everywhere. What a mess!
Let’s build a robot to tidy them.
Look at the front. It has a row of fingers.
A ball pushes in. The fingers swing up.
Then they drop down. The ball is caught!
Where do we see it? 5 min
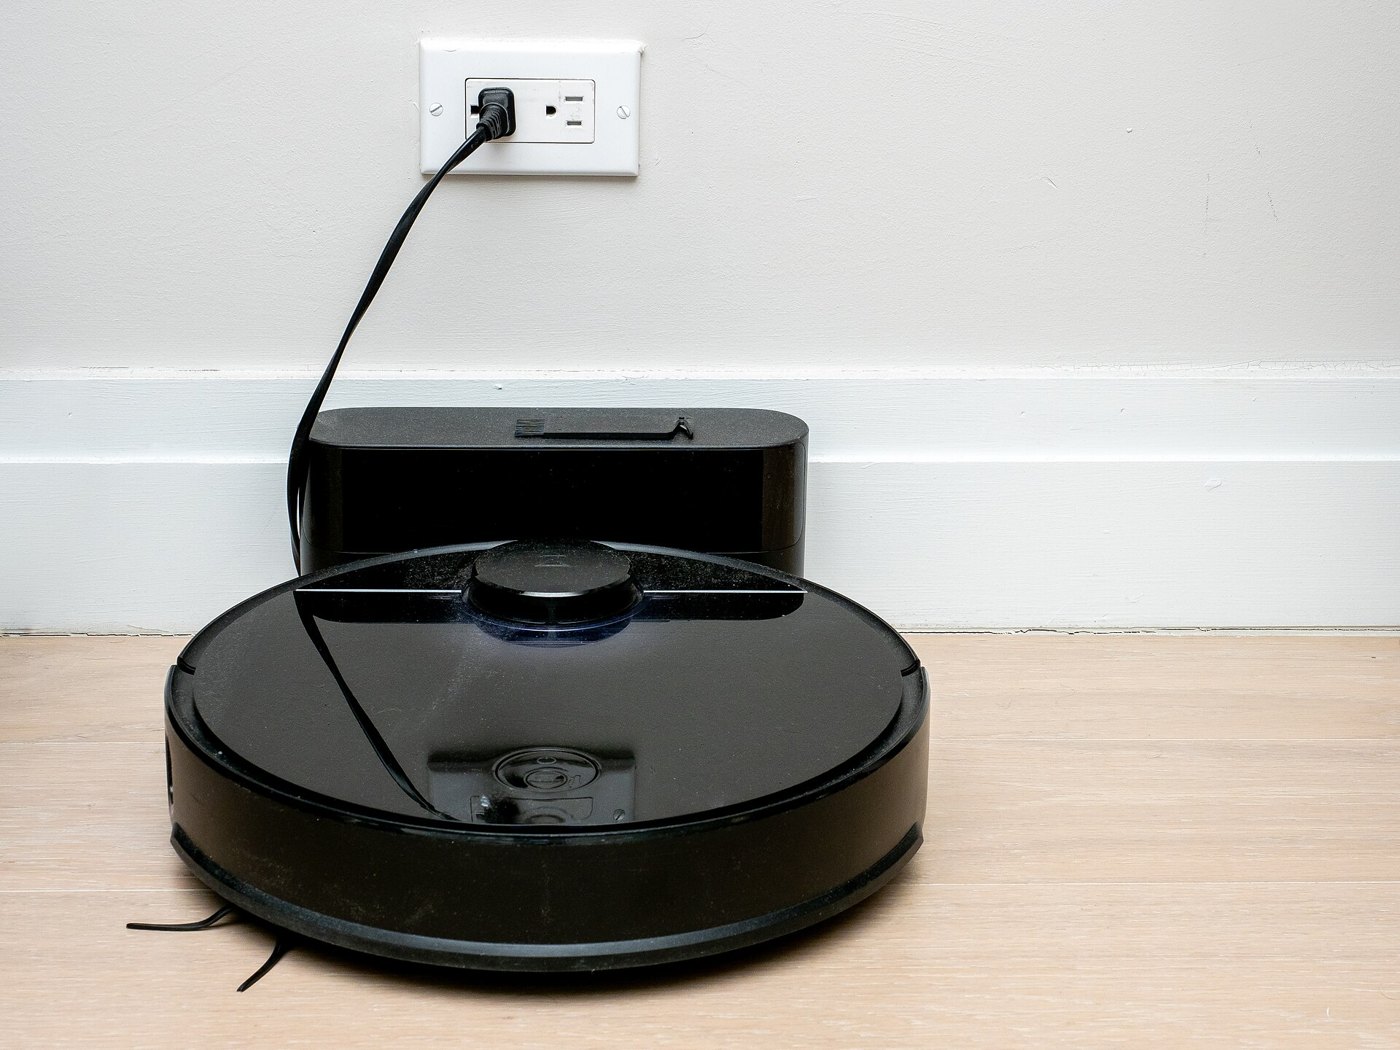
Some homes have a robot cleaner.
It drives over the floor by itself.
It picks up dust and crumbs. Yum!
Your robot picks up balls instead.
Building tips in the build
- Look at one picture at a time.
- Build both motors the same.
- Hang the fingers so they swing freely.
- Lift a finger. Let go. Does it drop back?
- Stuck? That is OK. Ask your teacher.
Catch it break! 5 min
- Stand up. Make a basket with your arms.
- Your teacher throws a pretend ball. Catch it!
- Catch one up high. Catch one down low.
- Hug your ball. Do not drop it!
- Sit down. Well done!
Meet the parts 5 min
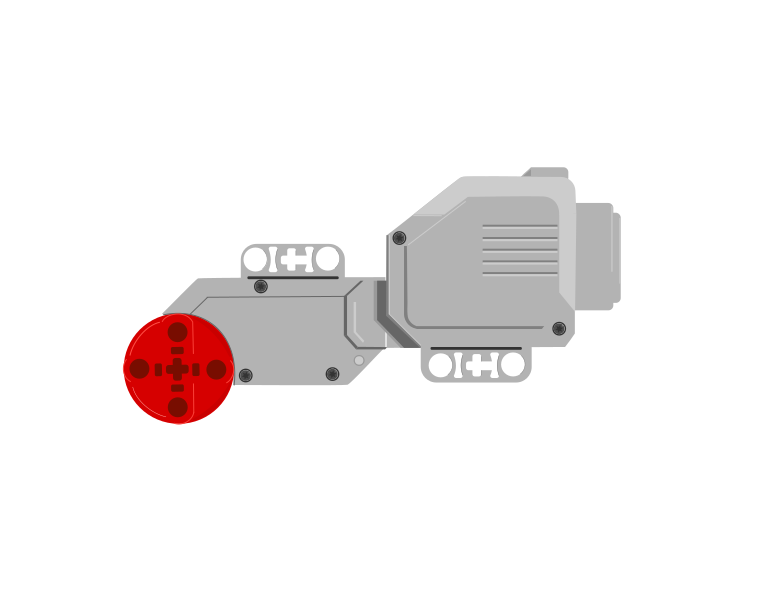
- Two big motorsThey drive the wheels.
- The fingersA door that only opens one way.
- The cageCaught balls stay in here.
Plug it in 5 min
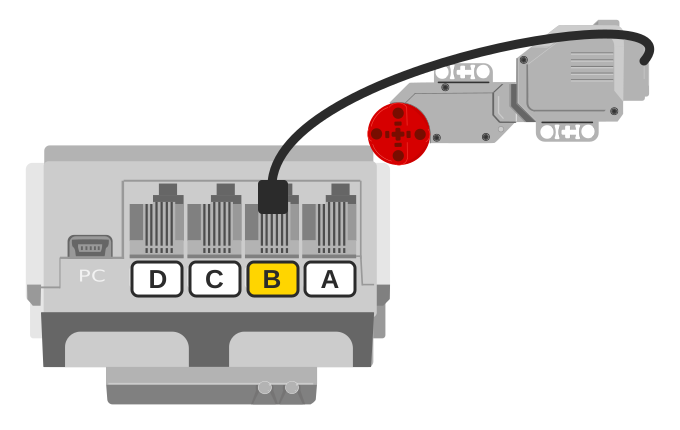
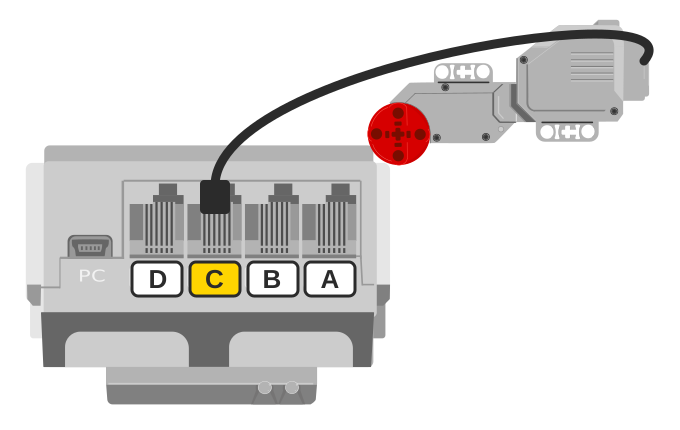
- Find the left motor. Plug it into B.
- Find the right motor. Plug it into C.
- Turn the Brick on. Join it to the computer.
Catch a ball! 20 min
- Put the robot on the floor.
- Put a ball in front of it. Not too far!
- Make this program.
when program starts :: events hat
set movement motors to [B v] and [C v] :: movement
move [forward v] for (2) [rotations v] :: movement
- Guess first! Will it reach the ball?
- Press play. Watch the fingers!
Your challenges 5 min
⭐ Challenge 1: Back up
Add a backward block. Does the ball stay inside?
⭐⭐ Challenge 2: Far away
Put the ball further away. Fix your number to catch it.
⭐⭐⭐ Challenge 3: Two balls
Put two balls in a line. Can you catch both?
Tidy up 5 min
- Take the balls out of the cage.
- Turn the Brick off.
- Keep your robot in one piece. You need it next time!
Well done! Your robot can catch!
Teacher note
Timing (90 min): photo and talk 5, real world 5, build 35, break 5, parts 5, ports and connect 5, first catch 20, challenges 5, tidy 5. The model is the Level 1 Ball Collector (EV3-L01-30): a driving base on two Large Motors, B on the left and C on the right, with hanging fingers at the front. There is no third motor: the robot catches by driving into the ball.
Use light balls that fit under the raised fingers, such as table-tennis balls or small plastic balls. Test one on a built model before class. Place each ball where two rotations reaches it for the first try.
Challenge 1 shows the one-way door: driving backward drags the caught ball along. If a ball escapes, check the fingers swing freely and drop back fully.