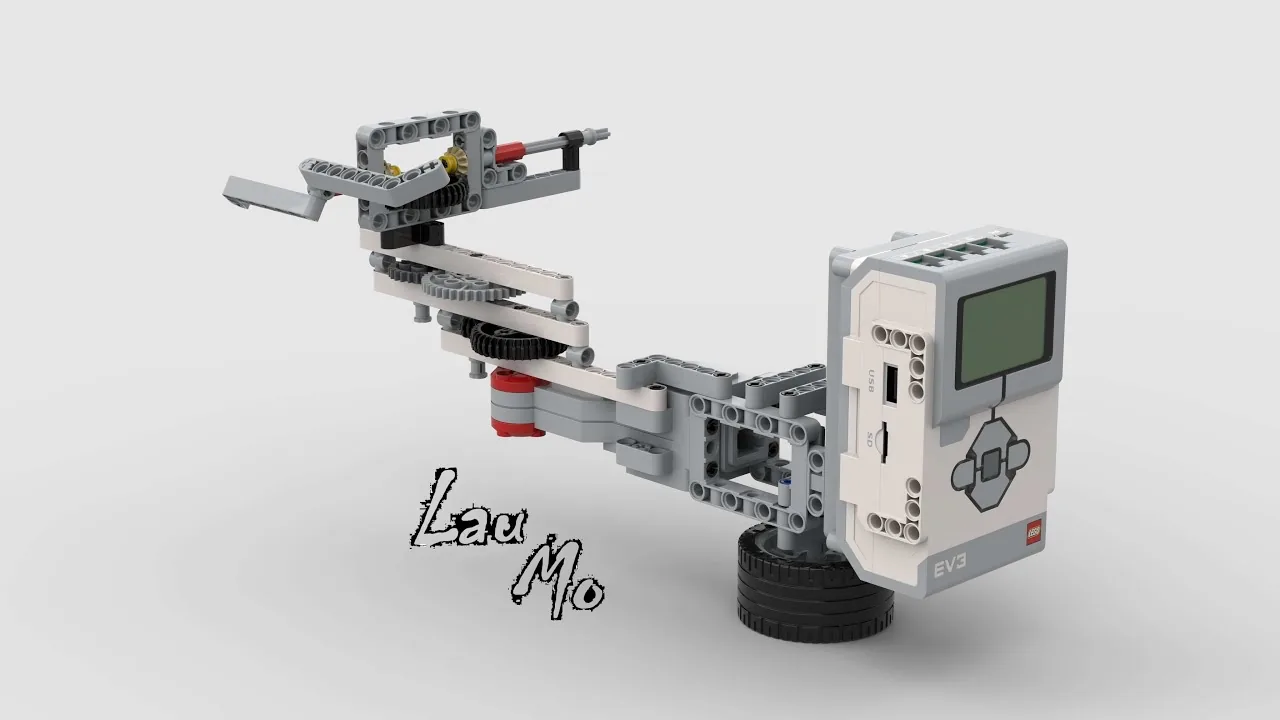
The Wind Plane: a long body that balances on one big wheel. The wheel lies flat on the ground. There is a rotor at one end and the Brick at the other. A rotor is a spinning fan. The whole machine can turn freely on the wheel, like a weathervane.
Spin the rotor, and the machine does something new. Nothing touches it. Nothing pushes it. But it turns!
By the end, you will know where that turn came from. You will also see the very thing a helicopter’s tail rotor stops.
In the real world 5 min
Where you have seen it
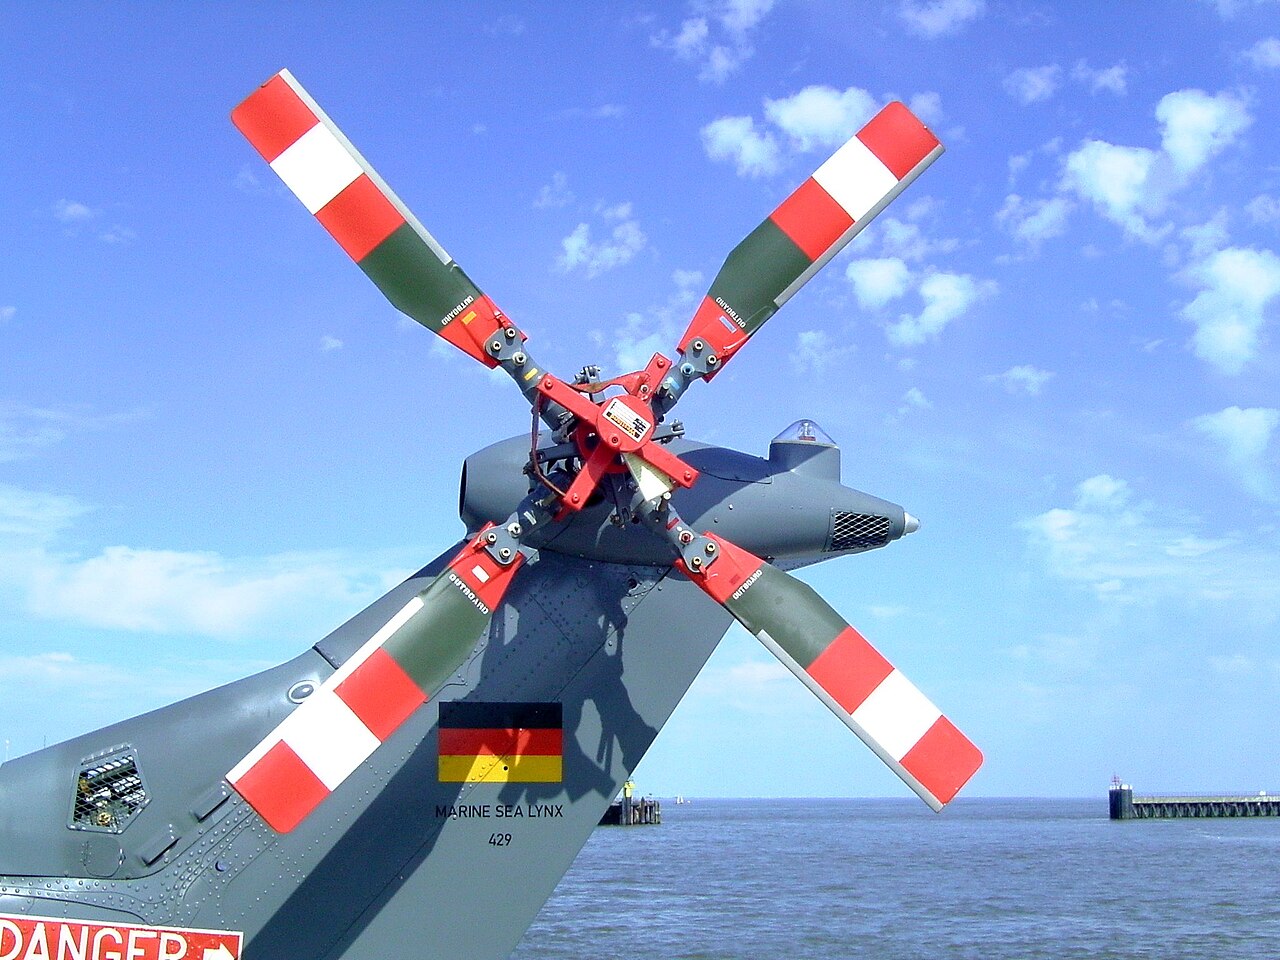
A helicopter has a little rotor on its tail. It stops the helicopter’s body from spinning. You will build one, the Apache, in Level 2, Lesson 12. Today, this model tests that idea.
A helicopter tail rotor. It faces sideways, because its job is to push air sideways. Photo: Wikimedia Commons (public domain).
Why it is built that way
A rotor is a fan. It grabs air and throws it one way. When you push something, it pushes you back just as hard. It pushes the other way. That is Newton’s third law. It is always true.
So a tail rotor throws air to the left. The air pushes it to the right. On a real helicopter, that push is the whole point. The big rotor on top tries to twist the helicopter round. The push holds the tail still. The pilot changes the push with foot pedals, to turn the nose.
This is also how a rocket works. Most people get this wrong! A rocket does not push against the air. It throws hot gas out of the back, very fast. The gas pushes the rocket forwards. That is why rockets work in space. There is nothing to push against there.
What would go wrong without it
Take away the tail rotor, and the helicopter’s body starts to spin. That is not a rare fault. It is what the machine always wants to do. The tail rotor stops it, every second of every flight.
Your Wind Plane has nothing to stop it, on purpose. It sits on one wheel and is free to turn. So you can watch what the tail rotor stops.
Push on the world, and the world pushes back.
Before you build 1 min
This model has no step-by-step instructions. We have a video of the finished machine instead. You will work out the build with your teacher.
Watch it twice. The first time, watch the rotor. The second time, watch the body. Which way does it turn? Which way does the rotor throw air? Seeing that is the whole lesson.
The main concept: every push comes back 6 min
A rotor pushes air one way. The air pushes the rotor the other way, just as hard. If the machine is free to move, it moves.
In Lesson 27 you will build the Hanging Bar. It is a robot with nothing to push against. It hangs in the air. Its motor can only swing its own weight about. This model is the opposite. There is lots to push against: air. As soon as the rotor throws the air, the air pushes back.
Air goes right, so the machine goes left. Nothing touches it. The air it threw is doing the pushing.
Two things decide how much it turns. You already know both blocks.
Change this
And the body turns
[A v] set speed to (80) % — a faster rotor
Harder and sooner. More air thrown each second means a bigger push back.
[counterclockwise v] — the rotor the other way
The other way. The air goes left, not right. So the body goes right, not left.
How freely the wheel turns
The build, not the program. If the wheel sticks, it can stop the whole push. Then the machine just sits there, looking broken.
Throw something away from you, and you move yourself. That is how rotors, propellers and rockets all work.
▶Single motor and motor speedHow one motor and its speed setting work. Open it if either is not clear yet.Show meHide
ComponentMotion4 min
One motor, on and off
Everything an EV3 does begins with a motor turning. Before worrying about how far or how fast, there are only two things to say to a motor: start and stop. The blocks are the same whichever motor you use — only the port letter changes.
Blocks reference
Block
What it does
[A v] start motor [clockwise v] :: motors
Starts the motor and immediately carries on to the next block. The motor keeps turning on its own.
[A v] stop motor :: motors
Stops the motor.
wait (2) seconds
Holds the program here, which is how you control how long a motor runs.
Start, wait, stop
Because start motor does not wait, a motor started on its own would run until the program ended. The pattern that gives a motor a length is three blocks:
when program starts :: events hat
[A v] start motor [clockwise v] :: motors
wait (2) seconds
[A v] stop motor :: motors
Read it aloud: start it, leave it two seconds, stop it. Change the wait and you change how far the motor gets.
Watch it run
The highlight below follows the block the Brick is running, and the shaft turns only while the program is between start motor and stop motor. Notice that the count keeps climbing all the way through the wait — the wait does not pause the motor, it pauses the program.
when program starts
A start motor clockwise
wait 2 seconds
A stop motor
Medium · frontturning: the red hub and its crossLarge · sideturning: the red hub, pin holes and cross
0.00rotations so farnoshaft turning
The program begins. Both motors are still.The motor is told to start — and the program does not wait for it.The program is paused at the wait block. The motors are not: watch the count keep climbing.The motor is told to stop. The shafts stop wherever they had got to.Finished. The motor ran for about two seconds and stopped where it stopped.
motor stopped
The count does not pause when the program does. A wait holds up the blocks, and the motor carries on turning underneath it.
This is the whole idea behind start motor: it hands the motor its instruction and moves on, leaving the motor running behind it. Nothing stops the shaft until a block tells it to.
Which way is clockwise?
The direction dropdown says clockwise or counterclockwise — but clockwise seen from where? Always from the axle end: look straight at the shaft coming towards you, and clockwise is the way a clock’s hands go.
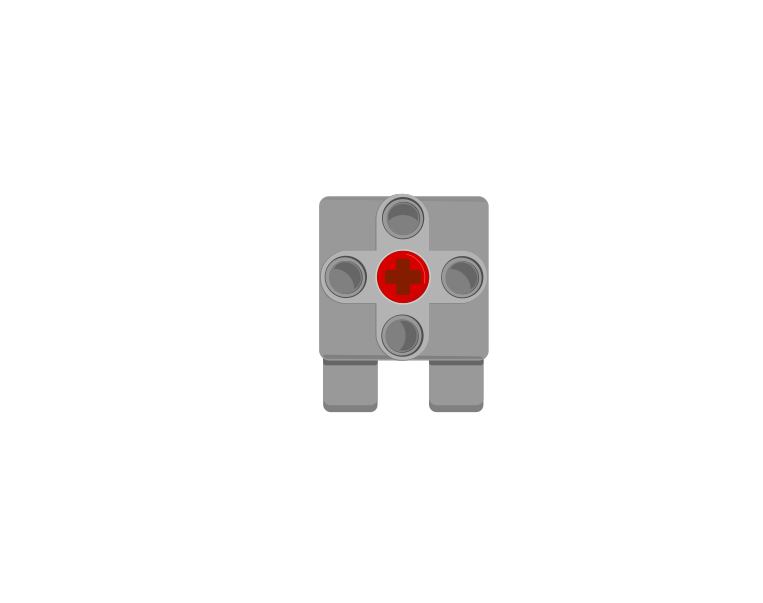
On the Medium Motor
Here the Medium Motor faces you, so its output axle points straight out of the page. This is the view to picture when you are choosing a direction.
The Medium Motor from the front, axle towards you. Choosing clockwise turns the axle the way the blue arrow goes; counterclockwise turns it the way the orange arrow goes. Everything geared to that axle follows it.
when program starts :: events hat
[A v] start motor [clockwise v] :: motors
wait (2) seconds
[A v] stop motor :: motors
A Medium Motor normally lives in port A or D.
On the Large Motor
The Large Motor is shown from the side, which is the face its axle comes out of — so once again you are looking straight down the shaft.
The Large Motor from the side, hub towards you. The same block with the same dropdown turns this hub the same way — the only thing that has changed is the port letter.
when program starts :: events hat
[B v] start motor [clockwise v] :: motors
wait (2) seconds
[B v] stop motor :: motors
A Large Motor normally lives in port B or C. Compare the two programs: they are the same three blocks, and only A has become B.
Same blocks, different motor
Medium · port A
Large · port B
Both motors take exactly the same start and stop blocks. The Large Motor is bigger and pushes harder but turns more slowly; the Medium Motor is quicker and lighter. Choosing between them is a build decision, not a programming one.
Why it matters
A fan, a conveyor belt or a spinning ride does not need to stop at an exact position — it just needs to run while something is happening. For those, timing the motor is simpler and perfectly good enough.
ComponentMotion4 min
Speed and power
Speed is set separately from movement. You tell the motor how fast it should go, and then you tell it to go — two blocks, in that order.
Speed is a percentage of what this motor can do, not a real-world unit — the same 50 % moves a light arm quickly and a heavy one slowly.
Blocks reference
Block
What it does
[A v] set speed to (25) % :: motors
Sets the speed for this motor from now on. Nothing moves — it only changes what the next movement will do.
[A v] run [clockwise v] for (2) [rotations v] :: motors
Now moves, at whatever speed was last set.
Set it first
when program starts :: events hat
[A v] set speed to (25) % :: motors
[A v] run [clockwise v] for (2) [rotations v] :: motors
Swap those two blocks round and the program still contains a speed of 25 % — it just never gets used. Both shafts below are asked for exactly 2 rotations; watch how long each one takes.
speed first — works
A set speed to 25 %
A run clockwise for 2rotations
speed last — does nothing
A run clockwise for 2rotations
A set speed to 25 %
0.00rotations · slow0.00rotations · fast
Speed first: the movement was slowSpeed last: it only affects the NEXT movement
Two programs. Same two blocks in each — only the order is different.Both are running — and the right-hand one is already finished. The left is barely a third of the way.Its speed block runs now, far too late to affect the movement above it. The left motor is still going, slowly, as it was told to.Both turned exactly 2 rotations. Only one of them did it at the speed the program asked for.Finished — it will run again in a moment.
stopped
Both shafts turn exactly 2 rotations. Only the time they take is different — and the right-hand program never gets the slow movement it was written to have.
The right-hand movement is over before the left is a third of the way round, because it ran at the default speed. Its set speed to () block does run — you can see it light up — but by then the movement it was meant to slow down has already happened. A speed block only ever affects the movements after it. This catches people out constantly.
Slow is often better
A high speed is not a better program. Slow movements are gentler on the gears, easier to watch and debug, and look more like the real machine — a barrier that snaps up in a fraction of a second reads as broken rather than fast.
Say this back before moving on: “The rotor pushes the air one way. The air pushes the machine the other way.”
What’s in this build 4 min
Look at your machine. One motor, one Brick, and one big wheel. The wheel has a new job. It does not drive anything. It is just something to turn on.
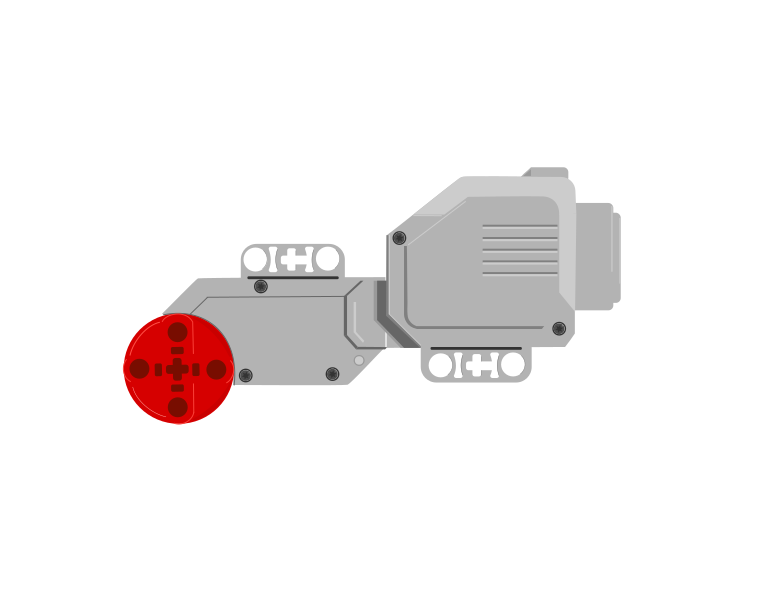
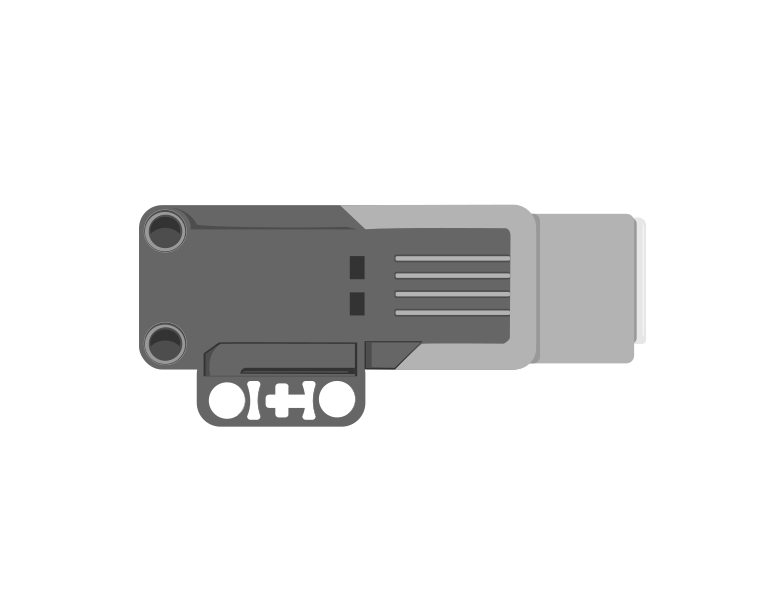
Which motor is it? This model has no instructions to tell you. Hold yours next to these two pictures, and decide.
Large Motor
Medium Motor
The Large Motor has a big round red end. Its body steps down behind it. The Medium Motor is flat, with air slots along the top. Which one is spinning your rotor?
Part
What it is doing here
EV3 Intelligent Brick
Runs the program. It is also the weight that balances the rotor. It sits at the other end. So the machine balances on its wheel.
One motor, port A
Spins the rotor. Whichever motor you have, the program says A and works the same.
The big wheel
Lies flat on the ground. It holds up the whole machine and lets it turn. No cable, because nothing drives it.
Sensors
None. The machine cannot tell that it is turning. But you can!
The wheel must turn really freely. Give the body a gentle push by hand, and let go. It should swing round and keep going for a moment. If it stops at once, something is sticking. Then no rotor speed will show you anything. Fix it before you go on.
Ports — and the rule 4 min
Sensors go in ports 1, 2, 3, 4. Motors go in ports A, B, C, D. You cannot swap them. If you do, nothing warns you. The robot just will not work.
Part
Port
Why this one
The motor (the rotor)
A
A single motor with its own job goes in A. There is no pair, so B and C stay free.
Sensors
none
Ports 1–4 stay empty.
Check your own build now:
One cable, from the motor to port A. A letter, not a number.
This one matters more than usual. The whole machine is going to turn. Coil the cable close to the middle. Keep it off the floor. A cable dragging on the table acts like a brake. This test must not have a brake!
Spin the rotor by hand. Check that it does not rub the body.
Clear a circle of table round it. It is going to turn. It may move about too.
Connect the Brick 4 min
Two routes, and either is fine. USB is the reliable one and the one to fall back on when a room’s Bluetooth is busy; Bluetooth leaves the robot free to move, which some models need.
▶How to connect the BrickUSB and Bluetooth, step by step, with a photograph of every screen. Open it if you have not done this before — or if pairing is not working.Show meHide
USB — the reliable one
Switch the Brick on with the dark grey centre button.
Cable into the Brick’s PC port — the small square socket beside the numbered ports, not one of the numbered ones.
Other end into the computer.
Bluetooth — name it first
Do these in order. Naming the Brick after you go looking for it in the list is how groups end up driving each other’s robots.
Name your Brick. On the Brick: Settings (the spanner) → Brick Name. Type something nobody else will pick, then press the tick. Every Brick is called EV3 until somebody changes it.
Turn Bluetooth on. Settings → Bluetooth. Tick Bluetooth and Visibility. Leave iPhone/iPad/iPod unticked.
Connect from EV3 Classroom. Click the Brick icon at the top of the programming area, find your Brick by name, and click Connect.
Say yes on the Brick. It asks “Connect?” with the computer’s name — choose the tick, then accept the passkey, which is already 1234.
Where to read it. The name sits in the bar across the very top of the screen, on every screen — so you can check which Brick you are holding at any moment without going into a menu. This one is EV3VE. A Brick nobody has renamed says EV3.Step 3, and the reason step 1 exists. Three Bricks in range — read the name before you click Connect. Pairing with the wrong one is not an error: it works perfectly, on somebody else’s robot.
Step 2.Bluetooth switches the radio on; Visibility is what lets the computer find you. With Visibility off your Brick works perfectly and simply never appears in the list.Step 4. Look at the Brick. It asks whether to accept and names the computer. Choose the tick.Then the passkey, already 1234. Press the tick again and you are connected.
The two failures, every class, every time. The Brick has gone to sleep while you were building — press the centre button to wake it. Or you have paired with the group at the next table, which is why the name matters.
The long version, including Port View and how to read the port tiles, is in the Brick & Bluetooth guide.
Use Bluetooth for this model if you can. A USB cable to a laptop will hold the body still. Then it cannot show you the lesson. If you must use USB, download the program, and unplug. Then run it from the Brick’s own screen.
Confirm the connection 2 min
Check the Brick icon. Is it connected? A cable plugged in does not mean the Brick is connected.
Port A shows a motor. Write down if it says Medium or Large. This model has no instructions, so this screen is your parts list.
Nothing on B, C or D, and nothing on 1 to 4.
Spin the rotor by hand, and watch tile A count. If the number moves, the cable is linked to the rotor’s motor.
Last check. Do not skip it! Pick the machine up by the body, and put it down again. Does it still swing freely on its wheel? Picking it up often makes the wheel stiff.
Change it and test 8 min
Make one change at a time. Guess what will happen before each run. Every guess here is about the body, not the rotor.
Change [clockwise v] to [counterclockwise v]. Guess which way the body goes now. Write your guess down before you run it.
Put it back and change set speed to (60) % to 25 %. Guess: does the body still turn at all? At a low speed, the push is too weak. It cannot beat the rubbing in the wheel. Find roughly where that speed is for yours.
Now try 100 %. Guess: does the body turn twice as fast as it did at 50 %? Time one whole turn of the body at 25 %, 50 % and 100 %. Write the numbers down.
Hold the body gently with one finger while it runs. Then let go. This is just what a tail rotor does for a helicopter. You are doing it by hand!
Add write [SPINNING] at line (3) after the start block. Add write [STOPPED] at line (3) after the stop. Now the machine tells you what it is doing. You can read it from across the room.
Think about step 4 afterwards. Your finger was doing the tail rotor’s job. On a real helicopter, nobody can hold the body still. So the machine has to hold itself still. That is why it has a second rotor at the back.
A helicopter needs a tail rotor. This model shows you why.
Build it 15 min
Build the model before you read any further. Everything after this is about making it do something, and none of it will make much sense with nothing on the table in front of you.
Fullscreen it while you build — you can pause and scrub with the player's own controls.
Check the finished build against the picture before you switch anything on. A motor mounted the wrong way round is far easier to spot now than it is to debug later, when it looks like a program fault.
This is what you are building: the Wind Plane.
Make it move 10 min
Seven blocks. Say what will happen, wait, spin, keep spinning, stop. Watch the body, not the rotor.
when program starts :: events hat
clear display :: display
write [HANDS OFF] at line (1) :: display
wait (2) seconds
[A v] set speed to (60) % :: motors
[A v] start motor [clockwise v] :: motors
wait (6) seconds
[A v] stop motor :: motors
Two seconds to let go, six seconds of rotor, then stop. The body's turn is not anywhere in the program.
Go through it in the order the Brick runs it:
clear display: wipe the last program's message off the screen.
write [HANDS OFF] at line (1): a real instruction, not just for show. A hand on the body will hold it still and spoil the test.
wait (2) seconds: your two seconds to let go and step back.
[A] set speed to 60 %: a setting. Nothing turns yet.
[A] start motor clockwise: it has no end. The motor starts and keeps going, and the program moves straight on.
wait (6) seconds: long enough to see the body start to move. It does not turn at once. It is heavy, and the push must beat that first.
[A] stop motor: the rotor stops. Keep watching! The body keeps going for a moment. It is already moving, and nothing is stopping it.
What success looks like: you take your hands off. The rotor spins. Then the whole machine slowly swings round on its wheel. It goes the opposite way from the air. Write down which way the air goes. Then write which way the body goes. Next, you will swap both.
Body not turning at all? Do not change the program. Either the wheel is sticking, or the cable is on the floor. Go back to the Ports checks to fix them.
Challenges 27 min
Work through them in order — each is harder than the last. The extra challenge comes after all three, and it is meant to make you plan before you build.
Challenge 1
Turn the machine half a turn and stop it there. Before you start, mark which way the nose points. Run the rotor until the body has swung round to face the other way. Then stop. You will have to find the right running time by trying. Keep a record of each try.
Challenge 2
Turn it one way, then back again. The machine must swing round, pause, and come back to about where it started. Use only the rotor. Mark the start first so everyone can see how close you got.
Challenge 3
Find how rotor speed and turning are linked. Time how long the body takes to make one full turn. Do it at four different rotor speeds. Write down the four pairs of numbers. Then find the slowest speed at which the body turns at all. Say what stops it below that speed.
Extra challenge
Point the machine at a target, from any start.
Your teacher will put a marker somewhere in the room. Then they will set your machine down facing any way at all. Your job is to make it turn and end up pointing at the marker. Use only the rotor. No one may touch it once it has started.
This is harder than it sounds. Think about why before you begin. Your machine cannot see the marker. It cannot tell how far it has turned. It does not stop the moment the rotor stops. You will work only from things you measured before.
Plan on paper first. What do you need to know to turn an angle into a running time? Go and measure it. When the rotor stops, the body keeps turning a little. That is called coasting. Decide what you will do about it.
You will be asked two questions when you show it. How did you turn an angle into a number of seconds? And what is the biggest cause of error in your method? Be exact.