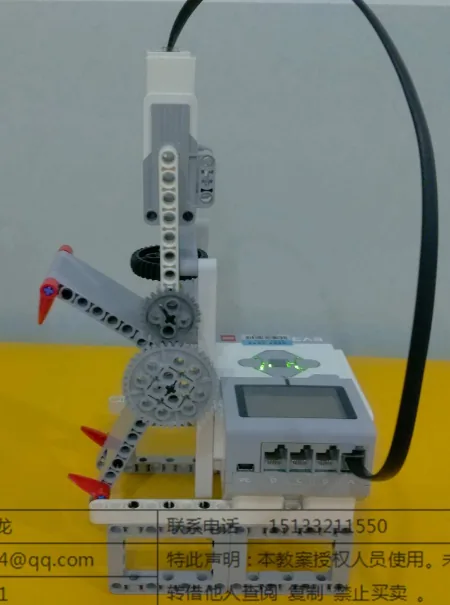
The Big Mouth Monster: a pair of jaws on a frame. They open wide and snap shut. One motor moves them.
It is a silly machine and a serious one at the same time. It is silly because it is a monster made of grey beams with red teeth. It is serious because it really bites. Keep your fingers clear!
The Timber Saw kept you safe with a switch you could reach from far away. This one does it another way. The machine will tell you if it is about to bite. You can see it from across the room. It uses a part of the Brick you tried on the Flying Chair in Lesson 19.
In the real world 5 min
Where you have seen it
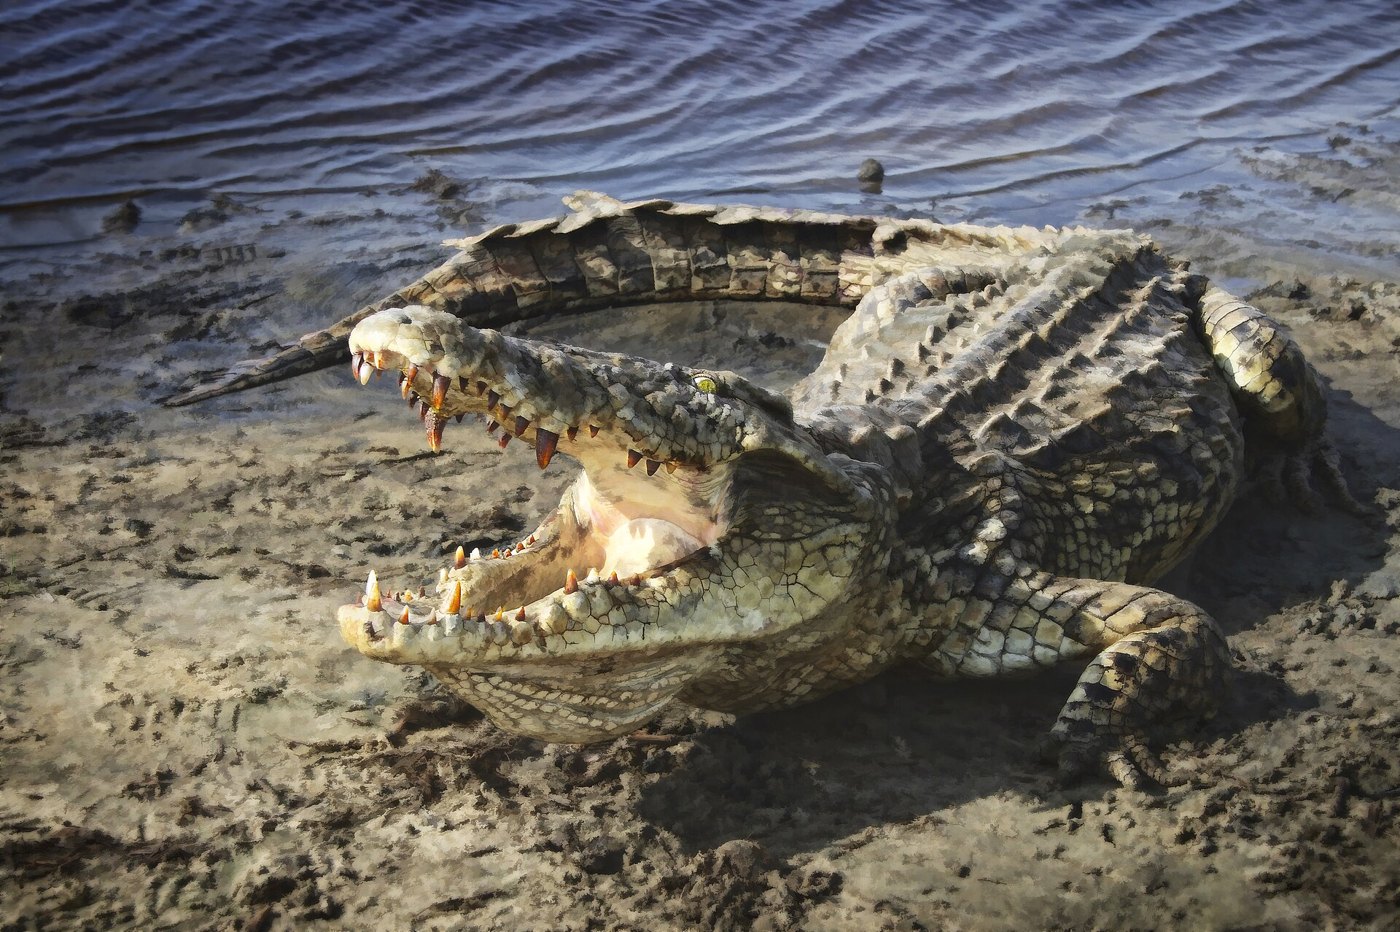
A crocodile’s jaw is the most famous pair of jaws in the world. The biggest crocodile of all is the saltwater crocodile. It lives in rivers and swamps in Asia and Australia. It is not a small animal!
A Nile crocodile with its jaws open on a riverbank. Photo: Steve Slater / Wikimedia Commons (CC BY 2.0).
Why it is built that way
A jaw is a lever, like the Auto Gate’s barrier arm in Lesson 6. But its hinge is the other way round. The muscle pulls close to the hinge. The teeth are far from it. So the muscle moves a little. The tip of the jaw moves a lot.
A crocodile’s bite is very strong, but its opening is very weak. All the muscle is for closing. A person can hold a crocodile’s mouth shut with two hands. That is true, but it is a terrible idea!
What would go wrong without it
Here is the problem with your model. Between snaps, the jaws stay open and very still. A machine waiting to move looks just like one that has finished.
You cannot tell them apart by looking. But you need to know before you put your hand in. Dangerous machines all over the world fix this the same way. They use a light.
Still is not the same as finished. A machine that is ready to move must say so.
The main concept — the status light 6 min
There is a ring of light around the Brick’s buttons. It is an output, like the screen and the speaker. One block controls it.
set status light to [green v] :: display
One block, one menu. It changes the light and moves straight on. It never waits.
The menu has six choices. They are three colours, each one twice:
Choice
What people already read it as
green / green pulse
Fine. Safe. Ready.
orange / orange pulse
Busy, working, or about to do something.
red / red pulse
Stop. Danger. Something is wrong.
The pulse choices flash slowly. They do not stay on. Use a pulse when the machine is busy. Use a steady colour when it has stopped. A flashing light says “happening now”. A steady one does not.
You cannot make up what the colours mean. Traffic lights, kettles and chargers have already taught everyone. Think of a robot that shows green just before it snaps. It is not being clever. It is lying!
when program starts
set status light to green
wait until is center button pressed?
set status light to orange pulse
A run clockwise for 1rotations
set status light to red
the ring around the buttons is the status light
The program sets the light green. Green means the robot is ready.It is now waiting for the centre button. The light still says ready — that is how you know it is waiting rather than stuck.Pressed. The light changes to orange pulse: the robot is about to move.The motor is running, and the ring is pulsing orange the whole way.Finished. Red, and nothing is moving — readable from across the room.Finished, and the light stays red until something sets it otherwise.
waiting
The light is the only output here you can read without looking at the screen — which is why it is worth setting deliberately at every stage of a program.
You have to read the screen. You only have to see the light. That is why the light is best for a warning.
▶The status light, and the Medium MotorHow both work. Open it if you are not sure about the light or the motor.Show meHide
ComponentOutput3 min
The Brick status light
The ring of light around the Brick’s buttons can be set to green, orange or red. It is the fastest possible way for a robot to say what it is doing — no reading required, visible from across the room.
The status light is the ring surrounding the buttons. It is visible across a room, which is what makes it useful for showing state at a glance.
Blocks reference
Block
What it does
set status light to [green v] :: display
Sets the ring to a chosen colour and carries straight on.
set status light to [red v] :: display
The same block with a different colour picked from the dropdown.
set status light to [orange pulse v] :: display
The three colours each have a pulse version, which flashes on and off until something changes it. A pulse reads as “busy”; a steady colour reads as “settled”.
A colour per state
The light is most useful when each colour means one thing, consistently, for the whole program. Watch a short program set it three times as it goes.
when program starts
set status light to green
wait until is center button pressed?
set status light to orange pulse
A run clockwise for 1rotations
set status light to red
the ring around the buttons is the status light
The program sets the light green. Green means the robot is ready.It is now waiting for the centre button. The light still says ready — that is how you know it is waiting rather than stuck.Pressed. The light changes to orange pulse: the robot is about to move.The motor is running, and the ring is pulsing orange the whole way.Finished. Red, and nothing is moving — readable from across the room.Finished, and the light stays red until something sets it otherwise.
waiting
The light is the only output here you can read without looking at the screen — which is why it is worth setting deliberately at every stage of a program.
Nothing in that program is about the light — it starts, waits for a button, turns a motor and stops. The light is simply told the truth at each stage, and the result is a robot whose state you can read without touching it. A common scheme:
Green — ready, or running normally.
Orange — waiting for something, or about to move. Pulsing orange is the natural choice here, because something is going on.
Red — stopped, blocked, or finished.
Why it matters
Machines everywhere signal with colour — traffic lights, a kettle’s power light, the charging light on a laptop. It also makes debugging far easier: set the light at each stage of a program and you can see how far it got without adding a single screen message.
ComponentMotion5 min
The Medium Motor
The Medium Motor is the smaller of the two EV3 motors. It is quick and light rather than strong, which makes it the right choice for anything that has to move a part of the robot rather than the whole robot — a gate arm, a pair of jaws, a winch, a pointer.
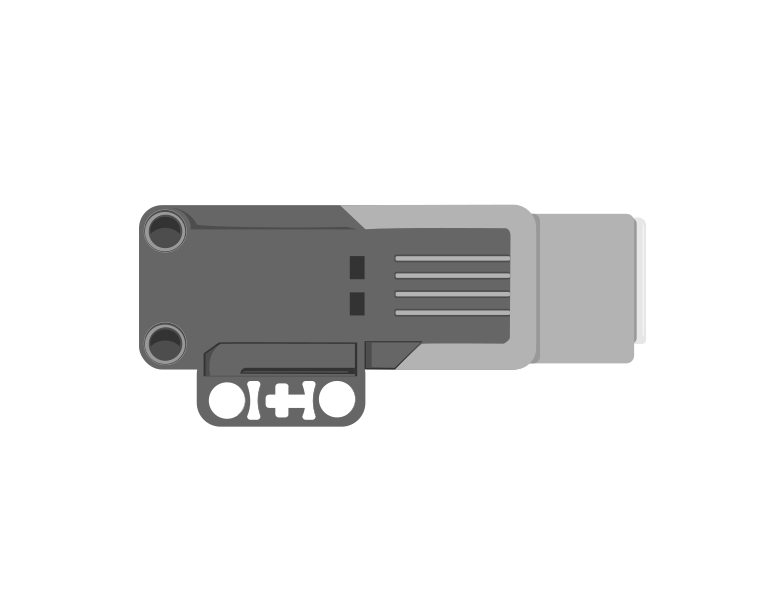
side
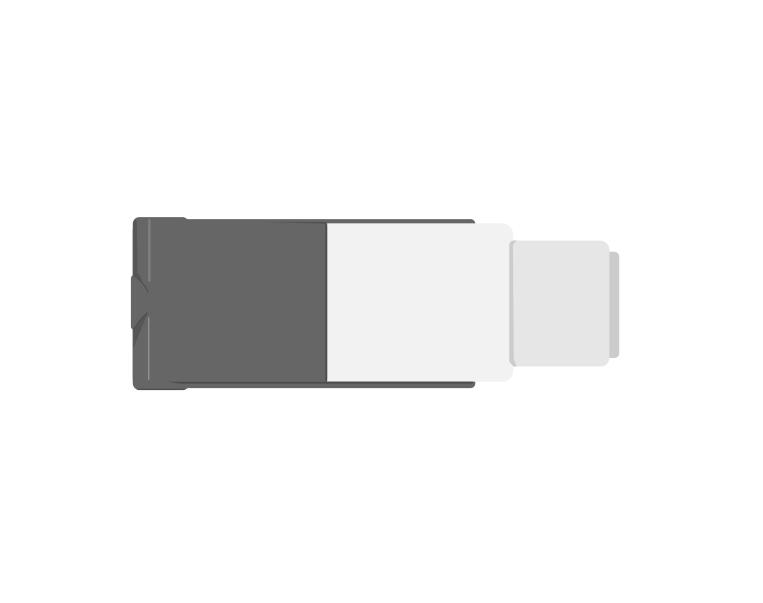
from above
The Medium Motor. The output shaft is the part that turns — everything the motor drives is attached to it, and every rotation you ask for is a rotation of that shaft.
Blocks reference
Block
What it does
[A v] run [clockwise v] for (1) [rotations v] :: motors
Turns the motor a measured amount, then stops. One rotation is one full turn of the motor shaft.
[A v] run [clockwise v] for (90) [degrees v] :: motors
The same idea, but in degrees — useful when a quarter or a half turn is what the mechanism needs. 360 degrees is one rotation.
[A v] run [clockwise v] for (2) [seconds v] :: motors
Turns the motor for a length of time and then stops, whatever the shaft managed to do in it. The one measurement that always finishes.
[A v] set speed to (50) % :: motors
Sets how fast the motor will run from now on. It does not start the motor by itself.
[A v] start motor [clockwise v] :: motors
Starts the motor turning and moves straight on to the next block. It keeps going until something stops it.
[A v] stop motor :: motors
Stops the motor.
Measured, or not measured
These two look similar and behave completely differently, and almost every early EV3 bug comes from picking the wrong one. Watch both run the same job, over and over.
when program starts
A run clockwise for 1rotations
versus
A start motor clockwise
wait 1 seconds
A stop motor
0°measured0°timed1run
Measured: on the mark, againTimed: 48° off the mark
Both programs begin. Both shafts are on the black target mark.Both motors are turning, and they look much the same.Stopped. The measured motor is back on the target; the timed one is wherever a second happened to take it.Finished — it will run again in a moment.
both stopped
Let it loop a few times. The left dial keeps landing on the same mark; the right one leaves a new mark almost every run — that scatter is what “not repeatable” means.
The black mark is where the shaft should finish. The measured motor hits it every single run, because the program waits at that block until the motor has turned exactly that far. The timed motor is only running for a second — and a second covers a different amount depending on the battery, the friction and whatever the mechanism is carrying. Each orange dash is a run that finished somewhere it was not asked to.
run for () rotations is measured. Run it twice and you get the same movement twice.
start motor is not measured. It hands the motor its instruction and moves straight on, so how far the motor gets depends on how long it happens to be left running.
If a mechanism has to end up in a particular place — a gate that must finish upright, a jaw that must close fully — use the measured block.
The third one: run for () seconds
The dropdown at the end of the run block has a third setting, and it is the one that saves lifting mechanisms. for () seconds switches the block off a distance and onto a duration: it drives the motor for that long and then stops, whatever the shaft managed to do in the time.
That sounds strictly worse than a measured turn, and for most jobs it is. It matters because of what the measured block actually waits for. run for (90) degrees does not finish when 90 degrees’ worth of time has passed. It finishes when the shaft has turned 90 degrees — and if the mechanism runs out of travel first, the shaft never will.
Stalling, and the program that never moves on
Every arm, jaw and lift has a physical limit: a point where the mechanism reaches the top of its travel, or something in the build gets in the way. Push a motor into that limit and it stalls — the shaft stops turning and the motor sits there straining. The motor is fine and the program is spelled correctly. But the encoder has stopped counting, so a measured block that was told a bigger number is still waiting, and it will wait until the Brick is switched off.
Nothing after that block ever runs. Not the next motor block, not the sound, not the display, not the rest of the program. That is the whole failure, and it looks like a crash even though nothing has crashed.
when program starts :: events hat
[A v] set speed to (30) % :: motors
[A v] run [clockwise v] for (90) [degrees v] :: motors
[A v] reset degrees counted :: motors
write [HOME SET] at line (1) :: display
0°degrees counted90°what the block asked for0.0swaiting at that block
60° reached, 90° asked — waits for everrest of the program never runs
Same arm, same end stop at 60°. One number is different: this program asks for 90.It lifts, and at 60° the arm meets its stop. The shaft cannot turn any further, however hard the motor pushes.Stalled. The block was told 90 and the shaft says 60, so it is still waiting — and it will wait for as long as the Brick is switched on.The screen is still blank. Every block after the motor block is unreachable — the program has not crashed, it is waiting.Finished. One arm, one end stop, and three programs — only one of which is safe to leave running.
lifting
Watch the Brick screen, not the arm. HOME SET is the block after the motor block, so a blank screen means the program never got past it.
Compare the first two. The only difference between them is 45 and 90, the mechanism is identical, and one of them is a working program while the other locks up on the third block. Nothing in the listing distinguishes them — the end stop is a fact about the build, and the program has never heard of it.
This is the mistake almost every student makes the first time a Medium Motor lifts something. A lifting arm has a lowest position and a highest one; ask it to turn past either and the program hangs. It is worse than an ordinary bug, because the robot looks alive — the motor is still being driven, still buzzing, still hot — and the next block never comes.
Finding a home position by stalling on purpose
The fix turns the problem into the technique. You often do not know how many degrees it is to the top of an arm’s travel — it depends on the build, and it changes the moment somebody rebuilds it. So do not measure it. Drive the arm gently into its own end stop for a couple of seconds, and then declare that position to be zero:
when program starts :: events hat
[A v] set speed to (30) % :: motors
[A v] run [counterclockwise v] for (2) [seconds v] :: motors
[A v] reset degrees counted :: motors
write [HOME SET] at line (1) :: display
Three things make that work, and all three are deliberate:
Slowly. 20–30% is enough to reach the stop and gentle enough not to strain the gears or shake the build apart while it sits there.
Long enough. Pick a time comfortably longer than the arm needs — one to three seconds for most mechanisms. It stalls partway through and spends the remainder pressed against the stop, which is exactly what you want.
Then reset.reset degrees counted makes this position 0, so every measured move afterwards is measured from a place you know. Now run for (120) degrees is safe, because you know where it is starting from.
After that, use measured blocks for everything inside the travel and timed blocks whenever you are driving to a limit. The rule of thumb: if the movement ends against something solid, run for seconds.
Ports
A Medium Motor is normally plugged into port A or D, which leaves B and C free for the Large Motors that drive wheels. The letter in the block must match the port the cable is actually in — this is the single most common reason a program appears to do nothing at all.
Say this back before moving on: “The light does not wait. It changes colour, and the program carries straight on.”
What’s in this build 4 min
Two electronic parts. Today, one of them does three jobs at once!
Part
What it is doing here
EV3 Intelligent Brick
Runs the program. It is also the model’s head. The status light is on the Brick. People can see the warning from wherever the Brick is facing.
Medium Motor
Works the jaw. It is the flat motor. It has a small red round part on its end. It is fast and light. That is just right for a snap.
Find the bite, by hand
Brick off. You need two numbers before you add any blocks.
Open the jaw gently by hand, as far as it goes easily. Stop when it starts to feel stiff. Do not force it any further.
Close it until the teeth just meet. Not past that! A jaw that closes too far pushes against itself. And the motor will keep on pushing.
That movement, from open to shut, is your bite. The motor must always stay inside it.
Now find which way the motor turns to close the jaw. Turn the drum both ways and watch. Write down: does clockwise close it, or counterclockwise?
Step 4 catches lots of people out. Get it the wrong way round, and your monster will not bite. It will try to open too far. It will sound like it is breaking, because it is!
Ports — and the rule 4 min
Sensors go in ports 1, 2, 3, 4. Motors go in ports A, B, C, D. You cannot swap them. If you do, nothing warns you. The robot just will not work.
Part
Port
Why this one
Medium Motor (works the jaw)
A
A motor working on its own goes in A. Every program on this page says A.
The status light
none
Built into the Brick, like the screen and the speaker. Three outputs, and no cables!
Check your own build now:
Motor cable in port A: a letter, not a number.
Set the jaw open before every run. The program thinks it starts open. It cannot check.
Can people see the Brick’s buttons from where they stand? The status light is a ring around them. What if the Brick is hidden inside the model, facing backwards? Then nobody can see the light.
Nothing loose near the jaw. It closes harder than you think!
Connect the Brick 4 min
Two routes, and either is fine. USB is the reliable one and the one to fall back on when a room’s Bluetooth is busy; Bluetooth leaves the robot free to move, which some models need.
▶How to connect the BrickUSB and Bluetooth, step by step, with a photograph of every screen. Open it if you have not done this before — or if pairing is not working.Show meHide
USB — the reliable one
Switch the Brick on with the dark grey centre button.
Cable into the Brick’s PC port — the small square socket beside the numbered ports, not one of the numbered ones.
Other end into the computer.
Bluetooth — name it first
Do these in order. Naming the Brick after you go looking for it in the list is how groups end up driving each other’s robots.
Name your Brick. On the Brick: Settings (the spanner) → Brick Name. Type something nobody else will pick, then press the tick. Every Brick is called EV3 until somebody changes it.
Turn Bluetooth on. Settings → Bluetooth. Tick Bluetooth and Visibility. Leave iPhone/iPad/iPod unticked.
Connect from EV3 Classroom. Click the Brick icon at the top of the programming area, find your Brick by name, and click Connect.
Say yes on the Brick. It asks “Connect?” with the computer’s name — choose the tick, then accept the passkey, which is already 1234.
Where to read it. The name sits in the bar across the very top of the screen, on every screen — so you can check which Brick you are holding at any moment without going into a menu. This one is EV3VE. A Brick nobody has renamed says EV3.Step 3, and the reason step 1 exists. Three Bricks in range — read the name before you click Connect. Pairing with the wrong one is not an error: it works perfectly, on somebody else’s robot.
Step 2.Bluetooth switches the radio on; Visibility is what lets the computer find you. With Visibility off your Brick works perfectly and simply never appears in the list.Step 4. Look at the Brick. It asks whether to accept and names the computer. Choose the tick.Then the passkey, already 1234. Press the tick again and you are connected.
The two failures, every class, every time. The Brick has gone to sleep while you were building — press the centre button to wake it. Or you have paired with the group at the next table, which is why the name matters.
The long version, including Port View and how to read the port tiles, is in the Brick & Bluetooth guide.
One thing to know about the light before you start. When a program is running, the Brick turns the ring green by itself. So a green ring at the start is not your program saying green. It means the program is running. Your first block will take control of the light.
Confirm the connection 2 min
Check the Brick icon: connected, or not.
Check the port tiles. A Medium Motor on A, and nothing on 1, 2, 3 or 4.
Open and close the jaw by hand and watch degrees counted move. Write down the number when it is fully open. Write it down again when it is fully shut. The difference is your bite in degrees. Now you have measured it, not guessed.
Use a number a little smaller than the one you measured. Stopping just before the end does no harm. It keeps the gears safe.
Change it and test 8 min
Make one change at a time. Guess what will happen before each run. Each time, ask the real question. Would a person nearby get the right warning?
Change the red to orange. Guess if it still looks like a warning. To most people, orange says “busy”, not “keep back”. That is useful, but it is not the same message.
Change it to red pulse. Run it and watch from across the room. Which do you notice first, steady or flashing?
Now the important one. Delete the last block — the green at the end. Run it. The jaws stop, but the ring stays red for ever. The machine still warns you, but the danger is over. Now nobody will trust the next warning.
Put it back. Now move the red block to after the two motor blocks. Guess what a person sees. The jaw snaps while the light is still green. That is a lie, and a dangerous one!
Put the whole thing inside a repeat (5), so it bites five times. Do your light colours still make sense every time round?
Steps 3 and 4 are the big lesson. They show two ways a warning light goes wrong. One never goes off. The other comes on too late. Both are worse than no light at all. Both teach people to stop looking at the light.
A signal is a promise. If it is ever wrong, people stop trusting it.
This is what you are building: the Big Mouth Monster.
Build it 15 min
Build the model before you read any further. Everything after this is about making it do something, and none of it will make much sense with nothing on the table in front of you.
One page at a time — use Next and Previous, or the ← → keys. Fullscreen makes it big enough to build from.
Check the finished build against the picture before you switch anything on. A motor mounted the wrong way round is far easier to spot now than it is to debug later, when it looks like a program fault.
Make it move 10 min
Seven blocks: safe, then a warning, then the bite, then safe again. Did you find that counterclockwise closes the jaw? Then swap the two directions.
when program starts :: events hat
set status light to [green v] :: display
wait (2) seconds
set status light to [red v] :: display
[A v] run [clockwise v] for (60) [degrees v] :: motors
[A v] run [counterclockwise v] for (60) [degrees v] :: motors
set status light to [green v] :: display
Green while nothing is happening. Red for the two blocks that move. Then green again at the end.
Walk it in the order the Brick runs it:
set status light to green — safe to come close. The block does not wait. The program is already on the next line.
wait 2 seconds — nothing moves. In this pause, a person decides if they can put a finger in. They look at the light to decide.
set status light to red — the warning. It comes before the movement. The Auto Gate's beep did that too.
run clockwise for 60 degrees — the jaw closes.
run counterclockwise for 60 degrees — and opens again. Same distance, the other way, so it ends where it started.
set status light to green — safe again.
What success looks like: a green ring, then a pause long enough to notice. Then the ring turns red, and the jaw snaps and opens. Then green again. Stand back three metres and watch. Can you still tell what it is doing? That is the test.
Does the jaw grind at the closed end? Then 60 degrees is more than your bite. Take away 10 at a time, until the teeth meet without pushing hard.
Challenges 27 min
Work through them in order — each is harder than the last. The extra challenge comes after all three, and it is meant to make you plan before you build.
Challenge 1
Add a third colour. Your monster must show orange while it gets ready. That comes after the green wait but before the jaw moves. So a person sees green, then orange, then red, before anything happens. Each colour must stay on long enough to notice.
Challenge 2
Make the monster bite five times in a row. The light must be right on every bite. It is green between bites and red during each one. It is green again at the very end. The trap is the last bite. After the fifth bite, the light must not be left red.
Challenge 3
Give it a trick. Sometimes the monster should go red and then not bite. Then a person cannot trust the timing alone. But every real bite must still have red first. Then answer in one sentence. If a warning sometimes means nothing, is it still a warning?
Extra challenge
Build a machine a stranger could stand next to safely.
Your monster must run on its own for at least a minute. It bites when it chooses. At every moment, its status light must say if it is safe to reach in. Someone who has never seen your model must work out the rule. They watch for thirty seconds. No one tells them anything.
Plan on paper before you build. Write down every state your machine can be in. A state is what it is doing right now. Next to each one, write the colour it will show. That list is your design. The blocks just type it in.
You will be asked two questions when you show it. Point to a moment when your light could be wrong. If you think there is none, say what makes you sure. And why is a warning light that is sometimes late worse than no light at all?