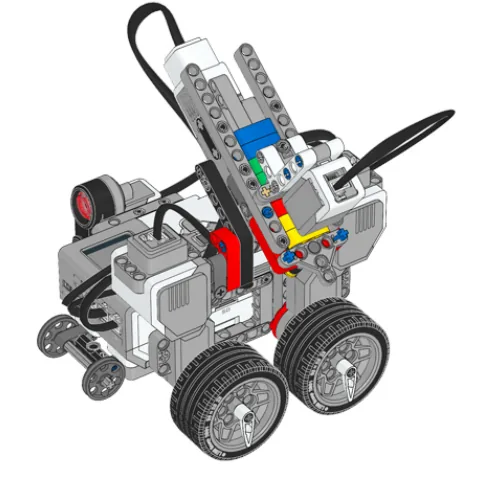
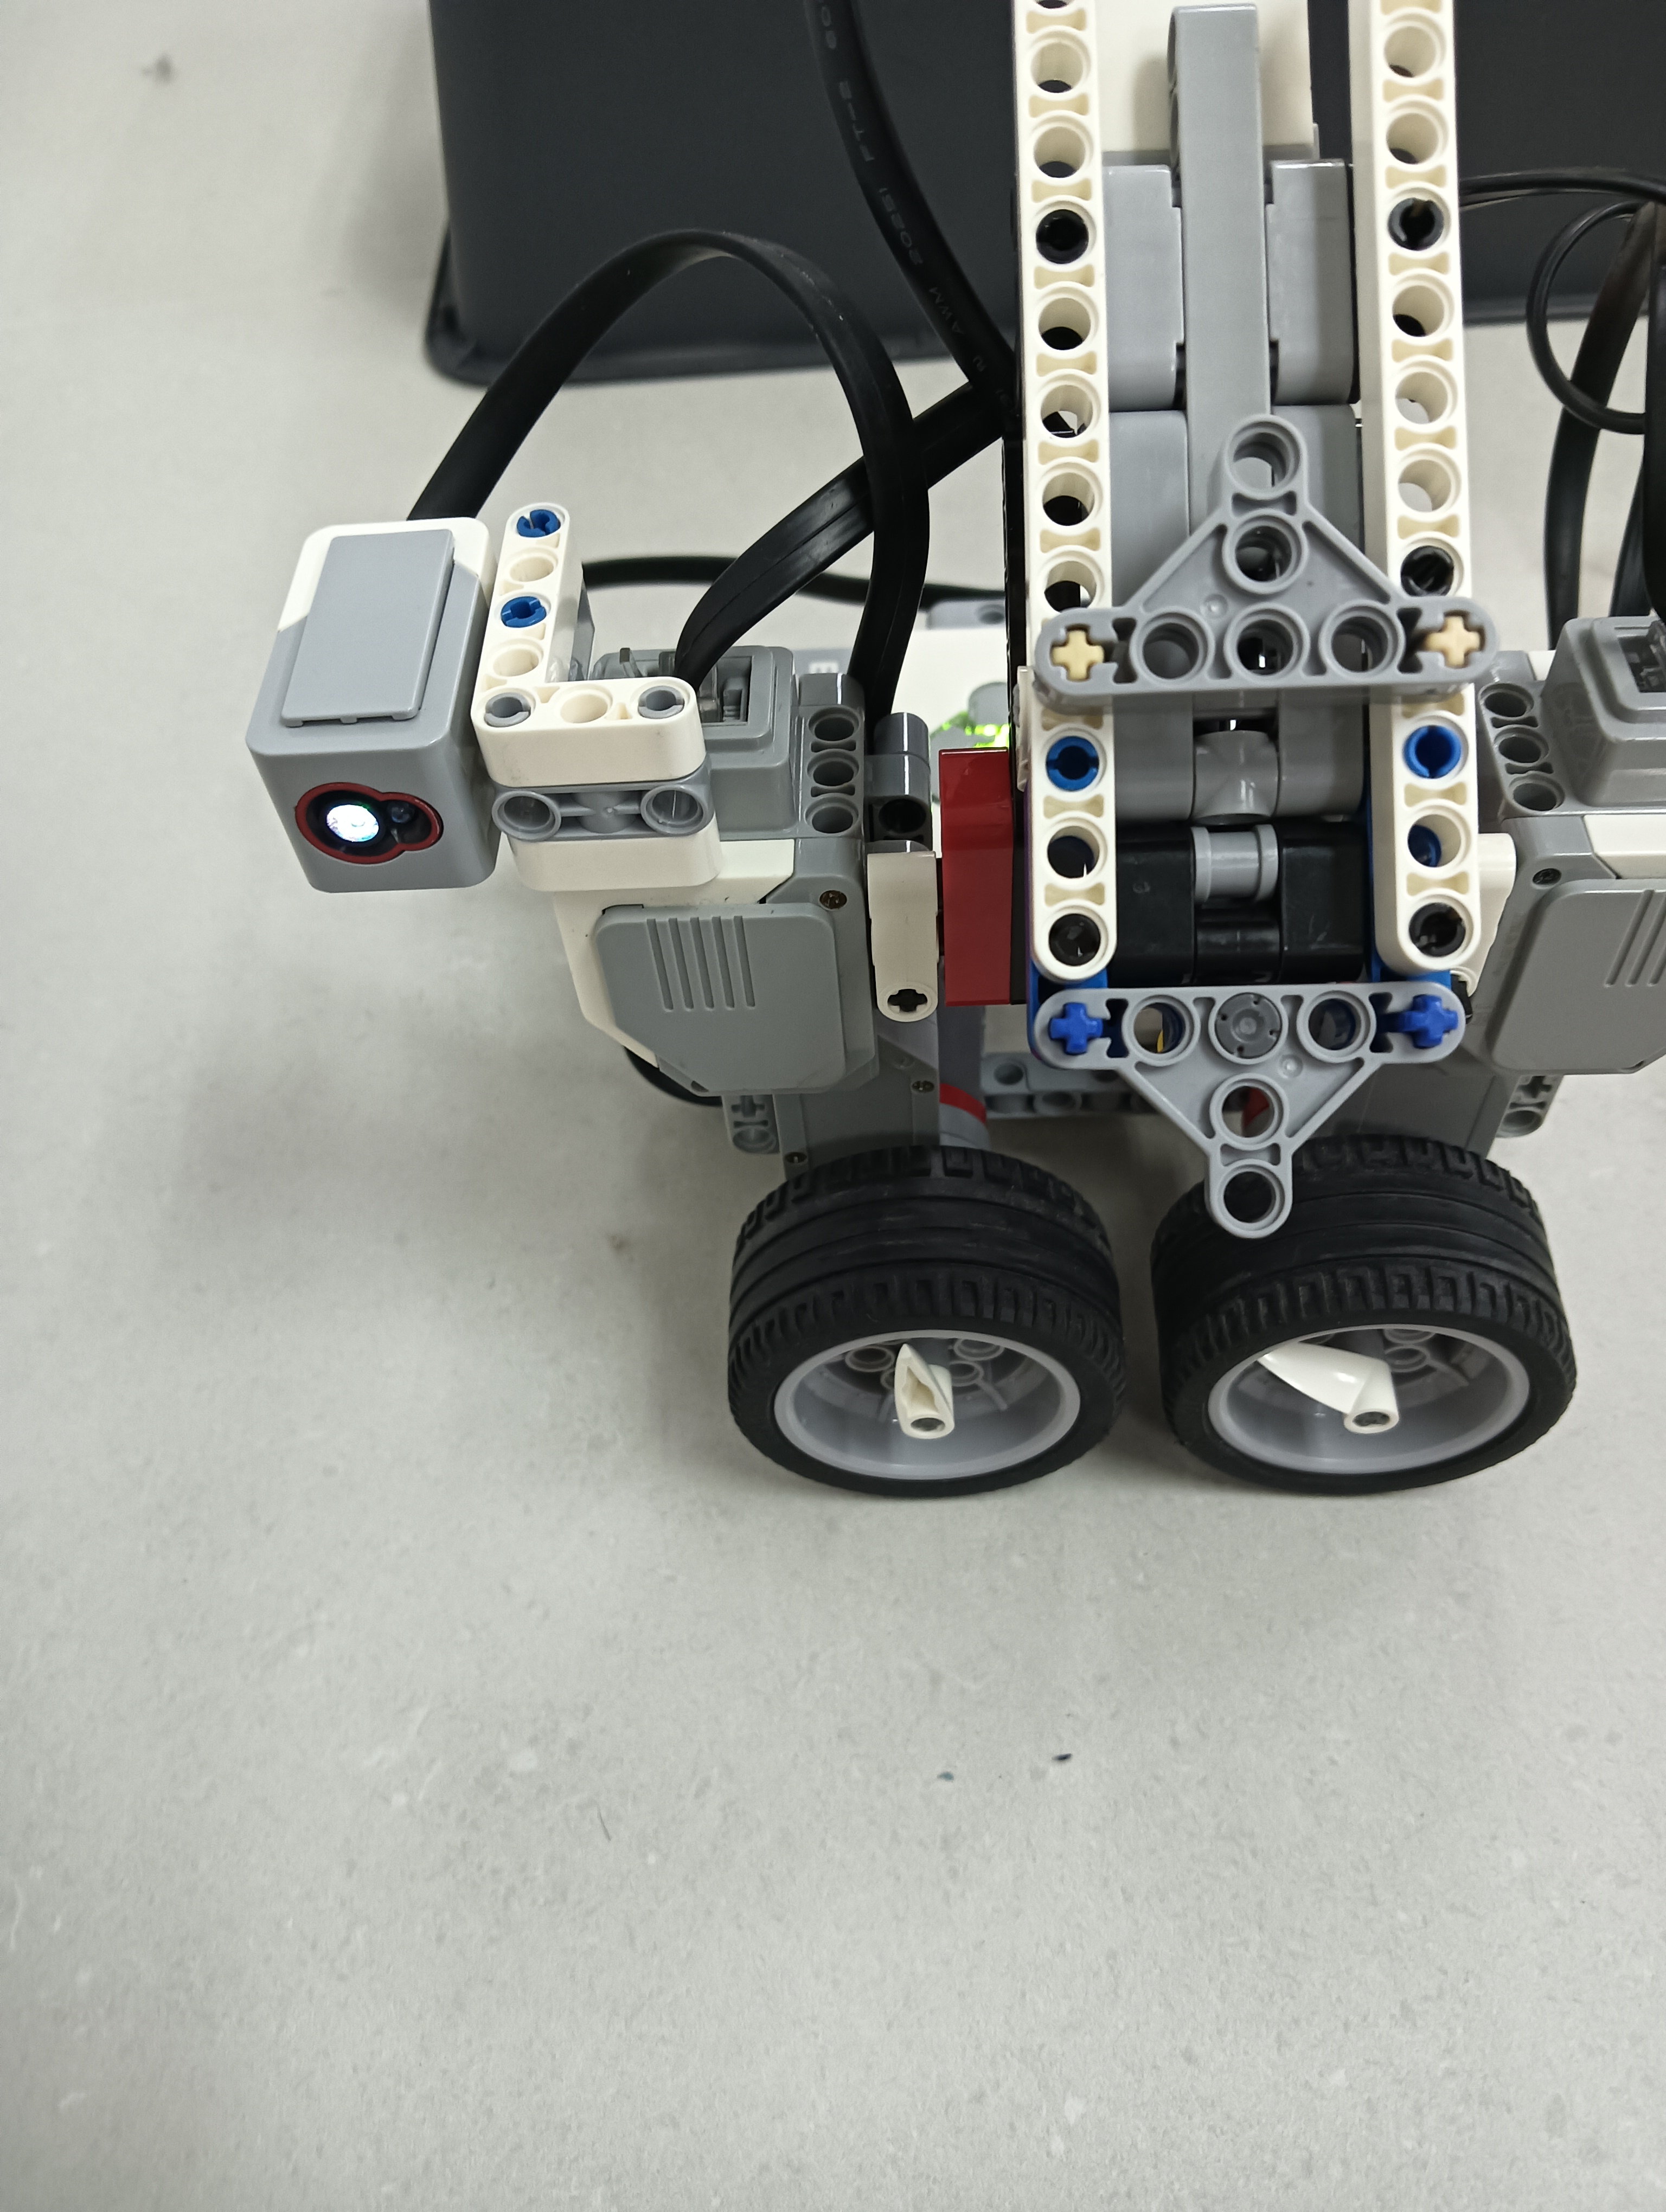
The Sorter Bot: bricks arrive one at a time, a Colour Sensor looks at each, and a chute swings to drop it into the right bin.
Every sensing decision you have made so far compared a number against a threshold — nearer or further, brighter or darker, faster or slower. This one cannot. A red brick is not more than a blue one.
By the end of the lesson your machine will put each brick where it belongs — and will have somewhere to put the ones it cannot identify, which turns out to be the hard part.
In the real world 5 min
Where you have seen it
A recycling plant runs mixed waste past a line of sensors and blows each item into a different stream with a puff of air. Optical sorters identify plastics by the light they reflect; magnets take the steel; eddy currents throw out the aluminium.
Every one of those lines has a stream for things it could not identify. It is not a failure — it is a designed outcome, and it is usually the most carefully handled one, because an unknown item in the wrong stream contaminates a whole batch.
Why it is built that way
A threshold always produces an answer. Ask “is it closer than 20 cm?” and every possible reading is either yes or no.
A classifier can be genuinely stuck. Show it something that matches none of its categories and the honest answer is “I do not know” — and a machine without a way to say that will pick its nearest guess and act on it with complete confidence.
What would go wrong without it
The dangerous version is not the machine that refuses. It is the one that puts an unknown item in the nearest bin and gives no sign anything unusual happened. The mistake is invisible until somebody opens the bin.
Every classifier needs a bin for “I do not know”. A machine that cannot admit that will guess instead.
The main concept — measurement into category 6 min
Classification maps a reading onto one of a fixed set of names. The names have no order — red is not between blue and green — so nothing you learned about thresholds applies.
Threshold (everything so far)
Classification (today)
Question
How much?
Which one?
Answers
Two, and they are ordered.
Several, and they are not.
Can it fail?
No. Every number is above or below.
Yes. Something may match nothing.
Tuned by
Moving one number.
Deciding what counts as each category — and what counts as none.
set [seen v] to ([3 v] color) :: variables
set [bin v] to (0) :: variables

if <(seen) = [red v]> then
  set [bin v] to (1) :: variables
end
if <(seen) = [blue v]> then
  set [bin v] to (2) :: variables
end
if <(seen) = [yellow v]> then
  set [bin v] to (3) :: variables
end
// bin is still 0 — nothing matched
bin starts at 0 meaning “unknown”, and only a real match changes it. The unknown case needs no rule of its own, which is why it is so easy to forget.
Start the answer at “unknown” and let matches overwrite it. The alternative — starting at bin 1 and hoping something corrects it — sends every unrecognised brick to the red bin, silently.
Reading the sensor once
Notice seen is read once and every test uses it. Read the sensor inside each if and the brick may move between tests, so two different rules could both fire — or none could. This is Lesson 6’s habit and Lesson 11’s, and it matters more here than anywhere.
Categories must be calibrated too
The Colour Sensor reports a colour name, but it decides that name from reflected light, and light depends on the room. A brick that reads blue at your table can read black under a shadow.
The robust version measures each category before sorting — show the machine one brick of each kind, let it record what it actually sees, and classify by nearest match to those. That is Lesson 12 turned from one threshold into a set of examples.
How to be honest about uncertainty
Have a reject bin, always, even in the demonstration version.
Say when you use it. A sound and a screen message, so an unknown brick is an event rather than a silent misfiling.
Count them. One reject in fifty is a brick nobody has seen before; twenty in fifty means the calibration is wrong.
ComponentSensing6 min
The Colour Sensor
The Colour Sensor looks down at a surface and can answer three quite different questions: what colour is this?, how bright is this? and how light is the room? Choosing the wrong one is the usual reason a line-following robot refuses to work.
front
side
The sensor has its own lamp beside its detector. That is why it must sit close to the surface and at a steady height — lifting it changes the reading even though the surface has not changed.
Blocks reference
Block
What it does
([3 v] color :: sensors)
Reports which colour it sees, from a short list — red, blue, green, black, white and a few more.
([3 v] reflected light intensity :: sensors)
Reports how bright the surface is, as a number from 0 (black) to 100 (white).
<[3 v] is color [red v]? :: sensors>
Reports true or false for one particular colour.
([3 v] ambient light intensity :: sensors)
Reports how much light is falling on the sensor, 0 to 100, with its own lamp switched off.
Which colour, exactly?
The sensor does not describe a colour — it picks one from a list of eight, and that list is the whole of what it can ever say:
Reports
Means
0
no colour — too far away, or too dark to call
1 · 2 · 3
black, blue, green
4 · 5 · 6
yellow, red, white
7
brown
Anything you put under it is forced into one of those eight. There is no orange and no purple: an orange brick comes back as red or as yellow, and often as red one moment and yellow the next as the robot creeps along. Light blue and grey are the other classic pair to avoid — grey is neither black nor white, so it flips between them.
This is why colour mode is a good fit for a task you control and a bad fit for one you do not. Sorting the LEGO bricks that come in the set works, because they are made in exactly these colours. Reading a printed sheet, a coloured tile from another set, or anything pastel is asking the sensor to answer a question it does not have a word for.
Two practical points follow from how it decides. It shines its own lamp and looks at how much red, green and blue comes back, so it must be close — about half a centimetre, and no more than a centimetre. Lift it and the answer decays to 0. And because it takes those three readings before it can answer, colour mode is the slowest thing this sensor does; a robot driving quickly can pass right over a small patch without ever reporting it.
When a colour must be recognised reliably, test it. Drive the robot slowly over the real surface with color shown on the screen and watch what it actually says — including what it says at the edges between two colours, which is where the wrong answers live.
Colour, or brightness?
Both questions are asked of the same surface at the same moment. Watch the two answers travel across a strip of colours and then over the edge of a black line.
when program starts
forever
write 3 color at line 1
write 3 reflected light intensity at line 3
colour: 2 possible answers herereflected light: every value from 88 down to 8
The sensor sits a few millimetres above the surface, with its own lamp shining down.It travels across the coloured patches. One read-out names what it sees; the other says how much light came back.Now the edge of a black line. The name only ever says white or black — but the number slides all the way down, and every value in between means something.Names for sorting. Numbers for following.Finished. Same sensor, same surface, two very different kinds of answer.
reflected light 88
Watch the two read-outs over the last third of the strip. One of them changes once. The other changes the whole way across.
Over the patches, both read-outs are useful. Over the edge of the line they part company: the colour name has only two answers to give and jumps between them, while the number slides smoothly from 88 down to 8. Every value in that slide tells you how far onto the line the sensor is — which is information the name simply does not carry.
Use colour when the answer really is a name — sorting red bricks from blue ones, stopping on a green square.
Use reflected light when the answer is a matter of degree — following the edge of a black line, where the useful readings are all the greys between black and white.
A line follower built on colour names only knows “black” or “not black”, so it can only lurch. Built on reflected light it can tell how far onto the line it has drifted, which is what makes smooth following possible.
The third mode: ambient light
The first two modes both switch the sensor’s own lamp on and measure what bounces back off the surface. Ambient light intensity does the opposite: the lamp goes off, and the sensor simply reports how much light is arriving from wherever — 0 in the dark, up to 100 in bright light.
Mode
Own lamp
Measures
Points
colour
on
which of eight colours the surface is
at the surface, very close
reflected light
on
how much of its own light comes back
at the surface, very close
ambient light
off
how bright the surroundings are
wherever you want to measure
That makes it the only one of the three that is not really about the floor. A number between 0 and 100 means very little on its own, so watch the same sensor sit through five different rooms — nothing underneath it changes at any point.
the sensor’s own lamp is off — it is measuring the room
Start in the dark — a hand over the lens, or the lights off. Almost no light reaches the sensor, and it reports 0.Curtains drawn with one small lamp on. Enough to see by, and the sensor climbs to about 12.An ordinary classroom with the lights on sits somewhere around 38 — the middle of the scale, not the top of it.Move it beside a bright window and the same sensor, in the same room, reads about 72.A torch pointed straight into it pushes the reading to nearly 100 — which is how a light can be used as a signal to a robot.Finished. Same sensor, same floor underneath it — the only thing that changed was the room.
ambient 0
Nothing under the sensor changed at any point in this run. Ambient light is the one mode that is not asking about the surface at all.
Those are the shape of the scale rather than exact figures, but the shape is the useful part: a lit room is nowhere near 100, and the top of the range is reserved for a light pointed straight at the sensor. Cover it with your hand and the number drops to near zero — which is the easiest way to check the sensor is doing what you think.
Point it at the ceiling and it tells you whether the room lights are on; point it forwards and a torch will spike the reading, which is a way of signalling to a robot without touching it.
Do not reach for it as a substitute for reflected light. Room light falling on a black line and on white paper is almost the same, so ambient mode can barely tell them apart — the reason reflected light works is precisely that the sensor brings its own light and measures how much of it survives.
It is also the mode most at the mercy of the room. A reading taken by a window in the morning will not match the same spot in the afternoon, so anything built on ambient light needs measuring on the day, in the place, with the lights as they will be.
Light and height matter
Even the two lamp-on modes are affected by room lighting — a reading taken by a sunny window differs from one taken in a corner. The sensor must also sit close to the surface and at a constant height, because lifting it changes the reading even though the surface has not changed.
ComponentControl6 min
Making a decision
Up to now a robot has been able to wait for a sensor. Deciding is different: the robot checks the sensor and does one thing or another depending on the answer — and then carries on either way.
Blocks reference
Block
What it does
if <> then
end
Runs the blocks inside only when the condition is true. Otherwise skips them.
if <> then
else
end
Runs one set of blocks when true and a different set when false.
Deciding again and again
A decision made once, at the start, is almost never what you want. Here are two robots with the identical if-else, testing the identical sensor against the identical number — one inside a loop and one not.
decision inside a loop
forever
if distance < 15 then
stop moving
else · start moving
the same decision, once
if distance < 15 then
stop moving
else · start moving
247checks · in a loop1check · once only
Nothing is close, so both robots ask «is the wall within 15 cm?», both hear no, and both take the else branch and drive.The left robot is asking again, and again, and again. The right one asked once and has finished asking.Under 15 cm. The left robot's next check says stop, so it stops. The right robot has no next check.Same condition. Same sensor. Same number. Only the loop is different.Finished. One robot is parked; the other is against the wall.
wall far
A decision is only worth as much as the last time it was made. Inside a loop, that is a few milliseconds ago.
Nothing is wrong with the right-hand program’s decision. It asked the question, got a truthful answer, and acted on it correctly. It simply never asked again, and the world moved on. Decisions belong inside a loop, so the robot keeps re-deciding as things change.
when program starts :: events hat
forever
  if <([4 v] distance in [cm v] :: sensors) < (15)> then
    stop moving :: movement
  else
    start moving [straight: 0] :: movement
  end
end
Four shapes, and how to choose
Once there is more than one question, decisions can be arranged in four ways. They look nearly identical stacked up in the editor, which is exactly why they get muddled — the thing that differs is not what the blocks say, it is which routes through them exist.
One question sorts them almost completely:
Are the questions…
Use
How many bodies can run
independent — any combination can be true
separate ifs
none, some, or all
one question, two answers
if / else
exactly one
the second only matters when the first is true
nested if
one, and only via the outer
mutually exclusive cases — exactly one should win
chained if / else
exactly one, the first that matches
Separate ifs — independent questions
Each if is asked no matter what the others answered, so any number of them can fire on the same pass. That is the right shape when the conditions genuinely have nothing to do with each other.
Both questions are always asked, so one pass can turn on the lamp, the fan, both, or neither. Dark and hot are unrelated — there is no reason answering one should stop the other being asked.
forever
  if <[3 v] is ambient light intensity [< v] (20) %? :: sensors> then
    [A v] start motor [clockwise v] :: motors
  end
  if <[4 v] is distance [< v] (15) [cm v]? :: sensors> then
    [D v] start motor [clockwise v] :: motors
  end
end
if / else — one question, two answers
Exactly one branch runs, every time. Reach for this whenever the robot must do something either way — and in preference to two ifs testing opposite conditions, which is the same idea written twice and can drift apart.
There is no route through this that runs both boxes, and none that runs neither. That guarantee is the reason to prefer it over two opposite ifs.
Nested if — a follow-up question
Putting one if inside another means the inner question is only ever asked when the outer one is true. Use it when the second question is meaningless otherwise: there is no point asking which side an obstacle is on when there is no obstacle.
The inner question sits on the outer one's yes route, so it is only reached when something is close. If nothing is close, the robot never asks which side it is on — because there is nothing to have a side.
if <[4 v] is distance [< v] (15) [cm v]? :: sensors> then
  if <([2 v] angle :: sensors) < (0)> then
    start moving [right: 50] :: movement
  end
end
When not to nest. If you only want “both true” and nothing happens at the outer level, an and says it in one block and reads better:
if <<[4 v] is distance [< v] (15) [cm v]? :: sensors> and <([2 v] angle :: sensors) < (0)>> then
  start moving [right: 50] :: movement
end
Nesting earns its place when something happens at the outer level too, or when there is an else at each level and the two mean different things.
Chained if / else — one winner out of several
This is the shape for a list of cases where exactly one should win: colour bands, distance bands, speed ranges. EV3 Classroom has no else-if block, so you build a chain by putting the next if inside the else of the last one.
Each question is only reached down the previous one's no route. The first that matches acts, and everything below it is never even asked — which is what makes overlapping bands safe.
And here is why it matters, because this is the single commonest bug in this whole module. Three bands written as three separate ifs are each perfectly correct, and together they are wrong: a reading of 20 is under 30 and under 60 and under 90, so all three run and the last one to run is the one that sticks.
three separate ifs
if light < 30 then
stop
if light < 60 then
go slowly
if light < 90 then
go fast
chained — if / else / if
if light < 30 then
stop
else
if light < 60 then
go slowly
else
go fast
↑ the rest is inside the else — never asked
3bands matchedgo fastseparate ifs dostopchained does
Separate ifs: 3 matched, last one winsChained: first match wins, rest never asked
The sensor reads 20 — a dark surface. Both programs should stop.The three separate ifs each ask their own question. 20 is under 30, so it stops… then 20 is also under 60, so it goes slowly… then 20 is under 90 too, so it goes fast. All three ran, and the last one wins.The chained version asked the same first question, got `yes`, and stopped. The other two live inside its else, so they were never even asked.Slide the reading up to 75 and both agree again — because only one band matches. The bug only shows itself where the bands overlap, which is most of the range.Finished. Same three bands, same reading — two different answers, because one shape stops asking and the other does not.
reading 20
Separate ifs are not wrong here so much as unguarded: nothing stops a second one matching. Chaining is what makes “the first one wins” true.
The rule to carry away: if the cases are meant to be exclusive, they must be made exclusive. Chaining does it by construction. Separate ifs only work if you are careful to write non-overlapping bands yourself — light < 30, 30 to 60, 60 and over — which is more to get right and easy to break later.
Why it matters
This is the point at which a machine stops following a script and starts responding. A thermostat, an automatic door, a robot vacuum — all of them are a decision inside a loop.
ComponentData6 min
Variables
Why anybody needs one
Long before there were computers, people had exactly this problem. A shepherd counting sheep through a gate, a trader counting sacks of grain, a builder counting days — none of them can hold the number in their head while they get on with the work. So they scratched a mark on a wall, cut a notch in a stick, or wrote a number on a piece of paper. The number lived outside the person, in a place they had agreed on, and they could go back to it, read it, and change it.
Better still, once the number is written down somebody else can use it. Watch these two: one of them counts and writes, the other never sees a single animal and simply reads the wall.
Abby never remembers the numberBen never sees a henThe wall holds it for both
Abby has a gate and a wall. Before a single hen comes through she chalks 0 on the wall — that is where the number is going to live.A hen goes through. Abby rubs out the 0 and chalks 1. Another goes through, and she does it again.Three hens have been through, and the wall says 3. Abby is not remembering the number — she is reading her own wall each time and writing the next one.Ben has been at the market all morning. He has not seen one hen. He walks up, reads the wall, and knows the answer — without asking Abby anything.That is a variable. Not a number in somebody's head, but a place both of them agreed on: one writes to it, the other reads from it, and it keeps the number in between.Finished. Abby wrote, Ben read, and the wall is what joined them up.
the wall holds it
Notice what never happens: Ben never asks Abby. He does not need to — the number is not in her head, it is on the wall, and the wall is there for anyone who needs it.
Neither Abby nor Ben is holding the number — the wall is. And notice what never happens: Ben does not ask Abby. He does not need to, because the count is not in her head. It is in a place they both agreed on, which is what makes it useful to more than one of them.
That is all a variable is. The robot cannot hold a number in its head either, so you give it a wall of its own, write a name at the top so everyone knows which wall is which — score, count, degree_turn — and the program can read what is on it and write something new. One part of the program writes; another part reads. Exactly Abby and Ben.
The paper, and the two things you can do to it
Say we are counting rotations of a motor. Before we start we write 0 on the paper. Every time the motor completes a turn we cross out what is there and write one more: 0 becomes 1, then 2, then 3. That is change — it has to read the old number to work out the new one.
set is the other thing you can do, and it is completely different: rub the whole paper out and write the number you want. It does not care what was there. Press the buttons and watch what happens to the crossings-out.
score
0
The paper starts blank, so we write 0 on it. That is what a variable is: a place to keep a number while the robot works.
change leaves a trail — every value follows from the one before it. This is what counting is.
set wipes the sheet. Use it to start a count, never to continue one.
Press set score to 0 after counting up a few times and watch the whole history vanish. That is what happens to a count when a set block ends up in the wrong place — and it is the commonest variable bug there is.
Blocks reference
Block
What it does
set [count v] to (0)
Puts a value in, replacing whatever was there.
change [count v] by (1)
Adds to what is already there.
(count)
Reports the current value, for use in a comparison or on the display.
Set, or change?
set replaces; change adds. Counting things needs change. Starting a count needs set. Both programs below have both blocks — the only difference is whether the set block is inside the loop or above it.
set before the loop
when program starts
set count to 0
repeat 4
A run clockwise for 1rotations
change count by 1
set inside it
repeat 4
set count to 0
A run clockwise for 1rotations
change count by 1
Before the loop: counted 0Inside the loop: stuck at 0
Both programs count the turns of a motor. The left sets the count to zero before the loop; the right sets it inside.Turn 1. Both counters read 1, and so far the two programs agree.Turn 2. The left count is 2. The right was set back to zero at the top of the loop, so it is 1 again.Turn 3. The left reads 3. The right still reads 1.Turn 4. The motor turned four times on both robots — only one of them counted them.Finished. Four turns, and one of the two counts is fiction.
stopped
Both programs contain both blocks. Only the position of set [count] to 0 is different.
The count on the right is not broken; it is being told to start again on every pass. Each time round the loop it is wiped back to zero and then changed by one, so the honest answer is always 1 — while the motor cheerfully turns four times. A counter stuck at 1 almost always means a set block that has slipped inside the loop.
Anything oval is a number you can pick up
EV3 Classroom tells you what a block does by its shape, and once you have noticed that, a whole set of questions answers itself:
Oval — reports a number. The blue degrees counted, the timer, a distance, your own variable.
Pointed — reports true or false. These go in an if or a wait until, not in a variable.
Block-shaped — does something. These stack up; they do not fit inside anything.
So when a slot is oval, any oval fits it — and it does not matter in the least where that number came from. You can take the motor’s own A degrees counted and keep it in a variable you named degree_turn, then compare that with a number later. Pick an oval below and watch the same one drop into all three kinds of slot.
pick an oval
the same oval fits all three
set degree_turn to A degrees countedkeep it in a variable of your own
A degrees counted+10do arithmetic with it
A degrees counted>50compare it with a number
Every one of those slots is oval-shaped, and A degrees counted is an oval — so it drops in. Nothing about where the number came from matters.
This is what makes a variable more than a counter. A sensor reading is true only at the instant you read it; copying it into a variable freezes it, so the robot can compare where it is now against where it was when something happened:
when program starts :: events hat
[A v] reset degrees counted :: motors
set [degree_turn v] to ([A v] degrees counted :: sensors)
start moving [right: 30] :: movement
wait until <(([A v] degrees counted :: sensors) - (degree_turn)) > (400)>
stop moving :: movement
Read the condition aloud: how far the motor has gone now, minus where it was when we started, is more than 400. Both are ovals, so both can go into a subtraction, and the subtraction is an oval too — which is why it can go into a comparison. Ovals nest inside ovals as deep as you need.
Reset at the start, every time
A variable keeps its value after the program ends. Run the program again without setting it back and the second run begins where the first left off — the count starts at 14, the robot thinks it has already done the job. Every variable a program changes must be set to its starting value at the top.
Why it matters
A variable is the difference between a machine that repeats a fixed routine and one that responds to how things have gone — counting parts, tracking a score, remembering where it started.
Start at unknown. Let a real match change it. Never let the machine guess quietly.
▶The Colour SensorColour mode versus reflected light, and why the room matters.Show meHide
ComponentSensing6 min
The Colour Sensor
The Colour Sensor looks down at a surface and can answer three quite different questions: what colour is this?, how bright is this? and how light is the room? Choosing the wrong one is the usual reason a line-following robot refuses to work.
front
side
The sensor has its own lamp beside its detector. That is why it must sit close to the surface and at a steady height — lifting it changes the reading even though the surface has not changed.
Blocks reference
Block
What it does
([3 v] color :: sensors)
Reports which colour it sees, from a short list — red, blue, green, black, white and a few more.
([3 v] reflected light intensity :: sensors)
Reports how bright the surface is, as a number from 0 (black) to 100 (white).
<[3 v] is color [red v]? :: sensors>
Reports true or false for one particular colour.
([3 v] ambient light intensity :: sensors)
Reports how much light is falling on the sensor, 0 to 100, with its own lamp switched off.
Which colour, exactly?
The sensor does not describe a colour — it picks one from a list of eight, and that list is the whole of what it can ever say:
Reports
Means
0
no colour — too far away, or too dark to call
1 · 2 · 3
black, blue, green
4 · 5 · 6
yellow, red, white
7
brown
Anything you put under it is forced into one of those eight. There is no orange and no purple: an orange brick comes back as red or as yellow, and often as red one moment and yellow the next as the robot creeps along. Light blue and grey are the other classic pair to avoid — grey is neither black nor white, so it flips between them.
This is why colour mode is a good fit for a task you control and a bad fit for one you do not. Sorting the LEGO bricks that come in the set works, because they are made in exactly these colours. Reading a printed sheet, a coloured tile from another set, or anything pastel is asking the sensor to answer a question it does not have a word for.
Two practical points follow from how it decides. It shines its own lamp and looks at how much red, green and blue comes back, so it must be close — about half a centimetre, and no more than a centimetre. Lift it and the answer decays to 0. And because it takes those three readings before it can answer, colour mode is the slowest thing this sensor does; a robot driving quickly can pass right over a small patch without ever reporting it.
When a colour must be recognised reliably, test it. Drive the robot slowly over the real surface with color shown on the screen and watch what it actually says — including what it says at the edges between two colours, which is where the wrong answers live.
Colour, or brightness?
Both questions are asked of the same surface at the same moment. Watch the two answers travel across a strip of colours and then over the edge of a black line.
when program starts
forever
write 3 color at line 1
write 3 reflected light intensity at line 3
colour: 2 possible answers herereflected light: every value from 88 down to 8
The sensor sits a few millimetres above the surface, with its own lamp shining down.It travels across the coloured patches. One read-out names what it sees; the other says how much light came back.Now the edge of a black line. The name only ever says white or black — but the number slides all the way down, and every value in between means something.Names for sorting. Numbers for following.Finished. Same sensor, same surface, two very different kinds of answer.
reflected light 88
Watch the two read-outs over the last third of the strip. One of them changes once. The other changes the whole way across.
Over the patches, both read-outs are useful. Over the edge of the line they part company: the colour name has only two answers to give and jumps between them, while the number slides smoothly from 88 down to 8. Every value in that slide tells you how far onto the line the sensor is — which is information the name simply does not carry.
Use colour when the answer really is a name — sorting red bricks from blue ones, stopping on a green square.
Use reflected light when the answer is a matter of degree — following the edge of a black line, where the useful readings are all the greys between black and white.
A line follower built on colour names only knows “black” or “not black”, so it can only lurch. Built on reflected light it can tell how far onto the line it has drifted, which is what makes smooth following possible.
The third mode: ambient light
The first two modes both switch the sensor’s own lamp on and measure what bounces back off the surface. Ambient light intensity does the opposite: the lamp goes off, and the sensor simply reports how much light is arriving from wherever — 0 in the dark, up to 100 in bright light.
Mode
Own lamp
Measures
Points
colour
on
which of eight colours the surface is
at the surface, very close
reflected light
on
how much of its own light comes back
at the surface, very close
ambient light
off
how bright the surroundings are
wherever you want to measure
That makes it the only one of the three that is not really about the floor. A number between 0 and 100 means very little on its own, so watch the same sensor sit through five different rooms — nothing underneath it changes at any point.
the sensor’s own lamp is off — it is measuring the room
Start in the dark — a hand over the lens, or the lights off. Almost no light reaches the sensor, and it reports 0.Curtains drawn with one small lamp on. Enough to see by, and the sensor climbs to about 12.An ordinary classroom with the lights on sits somewhere around 38 — the middle of the scale, not the top of it.Move it beside a bright window and the same sensor, in the same room, reads about 72.A torch pointed straight into it pushes the reading to nearly 100 — which is how a light can be used as a signal to a robot.Finished. Same sensor, same floor underneath it — the only thing that changed was the room.
ambient 0
Nothing under the sensor changed at any point in this run. Ambient light is the one mode that is not asking about the surface at all.
Those are the shape of the scale rather than exact figures, but the shape is the useful part: a lit room is nowhere near 100, and the top of the range is reserved for a light pointed straight at the sensor. Cover it with your hand and the number drops to near zero — which is the easiest way to check the sensor is doing what you think.
Point it at the ceiling and it tells you whether the room lights are on; point it forwards and a torch will spike the reading, which is a way of signalling to a robot without touching it.
Do not reach for it as a substitute for reflected light. Room light falling on a black line and on white paper is almost the same, so ambient mode can barely tell them apart — the reason reflected light works is precisely that the sensor brings its own light and measures how much of it survives.
It is also the mode most at the mercy of the room. A reading taken by a window in the morning will not match the same spot in the afternoon, so anything built on ambient light needs measuring on the day, in the place, with the lights as they will be.
Light and height matter
Even the two lamp-on modes are affected by room lighting — a reading taken by a sunny window differs from one taken in a corner. The sensor must also sit close to the surface and at a constant height, because lifting it changes the reading even though the surface has not changed.
Say this back before moving on: “Which one is it — and what if it is none of them?”
What’s in this build 4 min
Hold each of your bricks at the Colour Sensor and read the Brick screen. Do all of them report a colour, reliably? Any that do not are your reject bin’s first customers.
Part
What it is doing here
EV3 Intelligent Brick
The sorting station. Its screen reports what was seen and where it went — which is how a misfiled brick becomes traceable.
Large Motor — the feed
Brings bricks past the sensor one at a time. Its job is to present exactly one item, held still, in the same place every time.
Medium Motor — the chute
Swings to the chosen bin. Medium because it is a quick, precise positioning move.
Colour Sensor — the classifier
The judgement. Distance and ambient light both change what it reports, so it must be mounted at a fixed, close distance.
Ultrasonic Sensor — is anything there
Confirms a brick has actually arrived before the colour is trusted. Without it the machine classifies empty air, which usually reads as black and quietly fills a bin.
Fix the sensor distance and never change it. A Colour Sensor a centimetre further away reports different colours, so a machine calibrated at one height and run at another will misclassify everything — and look, from the outside, like a program fault.
Ports — and the rule 4 min
Sensors go in ports 1, 2, 3, 4. Motors go in ports A, B, C, D. They are not interchangeable, and nothing will tell you politely if you swap them.
Part
Port
Why this one
Chute (Medium)
A
The positioning motor.
Feed (Large)
B
The one moving bricks against friction.
Classifier (Colour)
3
Colour stays on 3 across the course.
Presence (Ultrasonic)
4
Ultrasonic stays on 4 across the course.
Check your own build now:
Chute in A, feed in B, colour in 3, ultrasonic in 4.
Centre the chute and note it as bin 0 — the reject position. Every run homes there.
Swing the chute to each bin by hand and write down the motor degrees. One number per bin, plus reject.
Check the Colour Sensor sits about a centimetre from where a brick stops, and that nothing shades it.
Connect the Brick 4 min
Two routes, and either is fine. USB is the reliable one and the one to fall back on when a room’s Bluetooth is busy; Bluetooth leaves the robot free to move, which some models need.
▶How to connect the BrickUSB and Bluetooth, step by step, with a photograph of every screen. Open it if you have not done this before — or if pairing is not working.Show meHide
USB — the reliable one
Switch the Brick on with the dark grey centre button.
Cable into the Brick’s PC port — the small square socket beside the numbered ports, not one of the numbered ones.
Other end into the computer.
Bluetooth — name it first
Do these in order. Naming the Brick after you go looking for it in the list is how groups end up driving each other’s robots.
Name your Brick. On the Brick: Settings (the spanner) → Brick Name. Type something nobody else will pick, then press the tick. Every Brick is called EV3 until somebody changes it.
Turn Bluetooth on. Settings → Bluetooth. Tick Bluetooth and Visibility. Leave iPhone/iPad/iPod unticked.
Connect from EV3 Classroom. Click the Brick icon at the top of the programming area, find your Brick by name, and click Connect.
Say yes on the Brick. It asks “Connect?” with the computer’s name — choose the tick, then accept the passkey, which is already 1234.
Where to read it. The name sits in the bar across the very top of the screen, on every screen — so you can check which Brick you are holding at any moment without going into a menu. This one is EV3VE. A Brick nobody has renamed says EV3.Step 3, and the reason step 1 exists. Three Bricks in range — read the name before you click Connect. Pairing with the wrong one is not an error: it works perfectly, on somebody else’s robot.
Step 2.Bluetooth switches the radio on; Visibility is what lets the computer find you. With Visibility off your Brick works perfectly and simply never appears in the list.Step 4. Look at the Brick. It asks whether to accept and names the computer. Choose the tick.Then the passkey, already 1234. Press the tick again and you are connected.
The two failures, every class, every time. The Brick has gone to sleep while you were building — press the centre button to wake it. Or you have paired with the group at the next table, which is why the name matters.
The long version, including Port View and how to read the port tiles, is in the Brick & Bluetooth guide.
USB is fine, but mind your shadow. The sorter stays put, so a cable costs nothing — just do not lean over the Colour Sensor while it works, or you become part of the calibration.
Confirm the connection 2 min
Check the Brick icon: connected, or not.
Two motor tiles — A and B.
Two sensor tiles — 3 and 4.
Hold each brick you intend to sort at the sensor and note what it reports. Do each one three times. A brick that reports two different colours across three tries cannot be sorted reliably — decide now whether to exclude it or to improve the lighting.
Stuck? The long version, with a photograph of every screen, is in the Brick & Bluetooth guide.
Change it and test 8 min
One change at a time. Predict, then run, then look. Run twenty bricks each time and record sorted against rejected.
Sort twenty bricks including three unknown colours. The counts should read 17 and 3. If the unknowns went into real bins, the reject path is not working.
Start bin at 1 instead of 0. Now unknown bricks go silently into bin 1. Run the same twenty and watch the reject count stay at zero while the machine is quietly wrong.
Change the room lighting — shade the sensor with a book, or move to a window. Re-run the same twenty bricks and compare. This is Lesson 12 arriving uninvited.
Add a fourth colour. One angle in the list, one rule in classify. Nothing else should need touching.
Remove the presence check and let the machine run with no bricks. It will classify empty air, and the bin it chooses will surprise you.
A classifier that never rejects anything is not confident — it is uncalibrated, and hiding it.
Where this goes 3 min
Your sorter swings its chute to one of four positions. Four numbers, one per bin — a machine that knows a handful of places.
The next model has to reach anywhere. A writing robot cannot have a list of positions for every point of every letter; it needs a way to describe a place in general, and to move to any of them.
A position is a pair of numbers, and a shape is a list of positions. That idea — a coordinate system — is what lets a machine draw a letter it was never specifically programmed for, and it is the next lesson.
Today the machine chose between places it knew. Next it learns to describe one.
Make it move 10 min
Grab a box, make the robot ultrasonic sensor detecting the box
Press up button, the robot will move towards to box until detect less than 10cm, then move away from the box until detect more than 20 cm.
Press center button, the robot will trigger the medium motor action, to push the brick out of the slider. (rotate the motor 1 rotation)
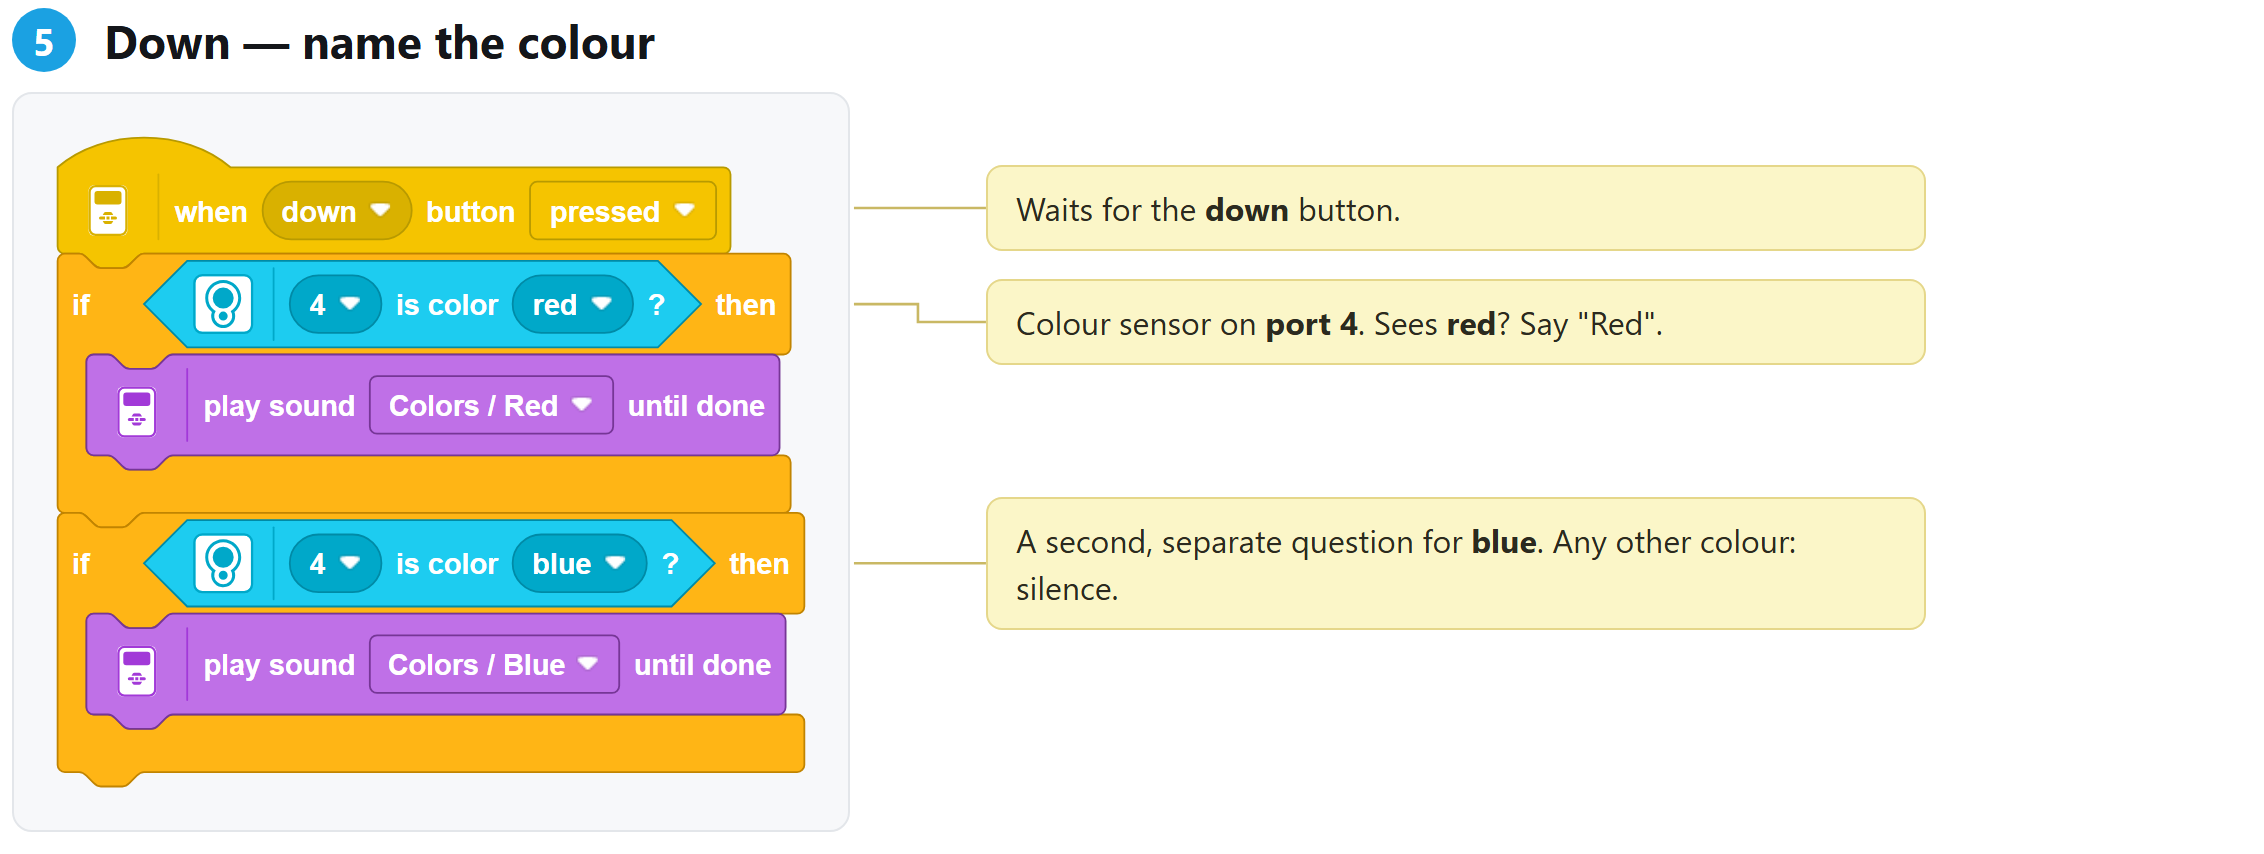
Press down button, if the robot detect red color, will sound "Red". If the robot detect blue color, will sound "Blue".
Fullscreen it while you build — you can pause and scrub with the player's own controls.
This is what you are building: the EV3 Sorter Bot.
Build it 15 min
Build the model before you read any further. Everything after this is about making it do something, and none of it will make much sense with nothing on the table in front of you.
Use the viewer's own controls to zoom and turn pages. Fullscreen makes it big enough to build from.
Check the finished build against the picture before you switch anything on. A motor mounted the wrong way round is far easier to spot now than it is to debug later, when it looks like a program fault.
The program, block by block
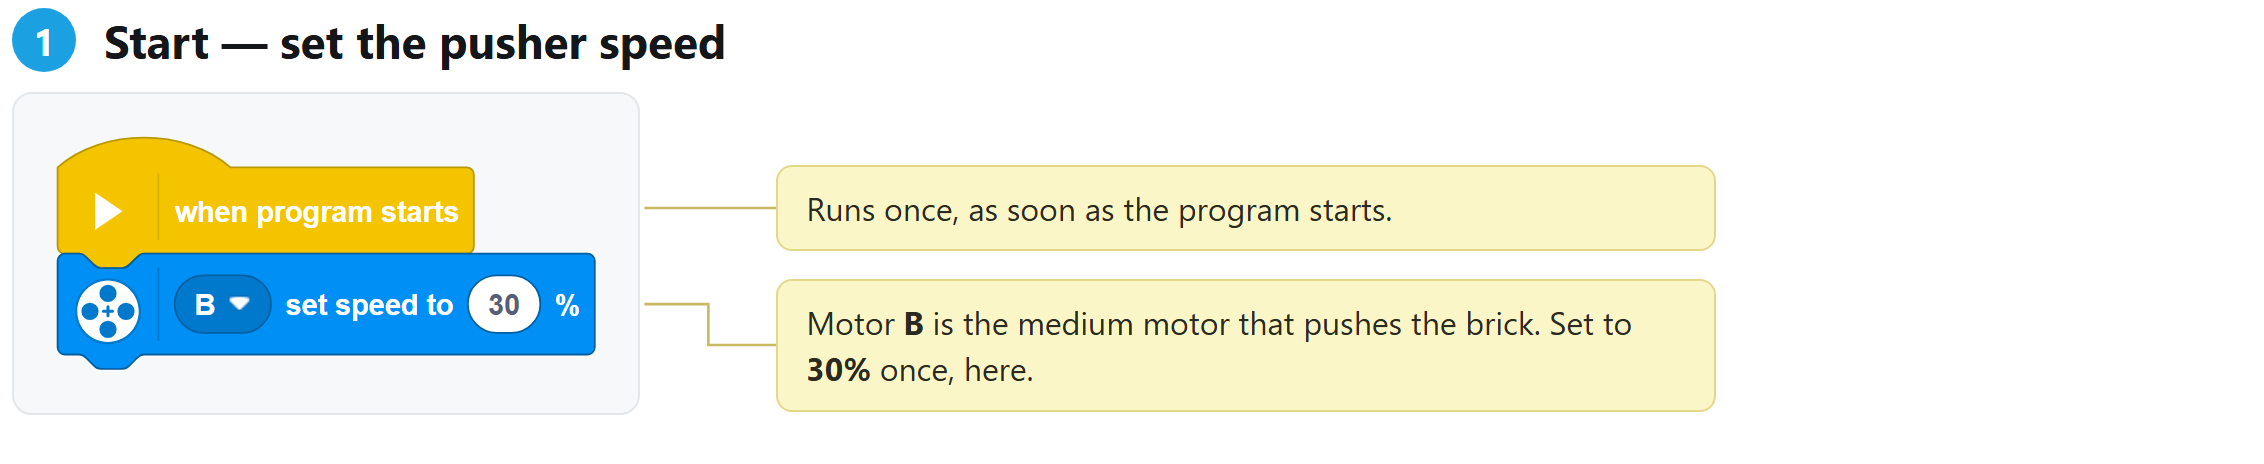
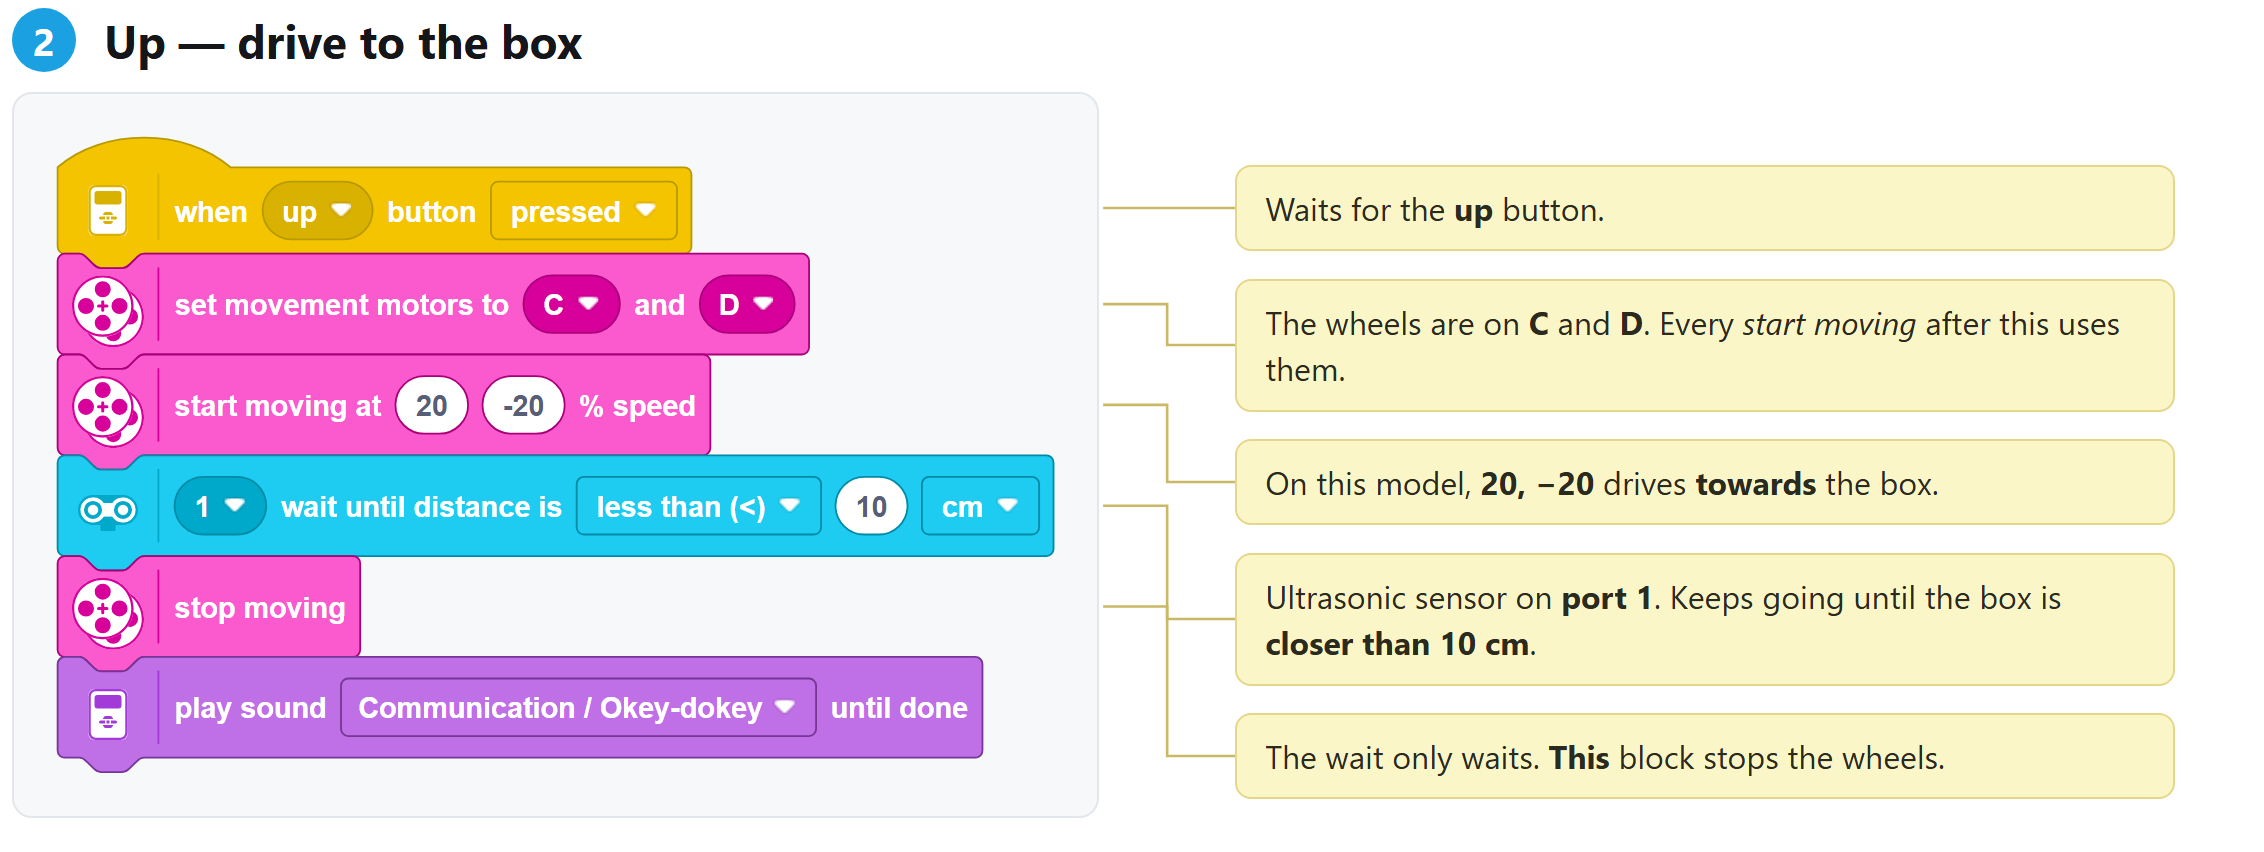
Motors C and D (wheels), B (pusher) · Speed wheels 20%, pusher 30% · Sensors ultrasonic on port 1, colour on port 4
What it does
Three buttons, three separate jobs. Up drives to the box until it is closer than 10 cm,
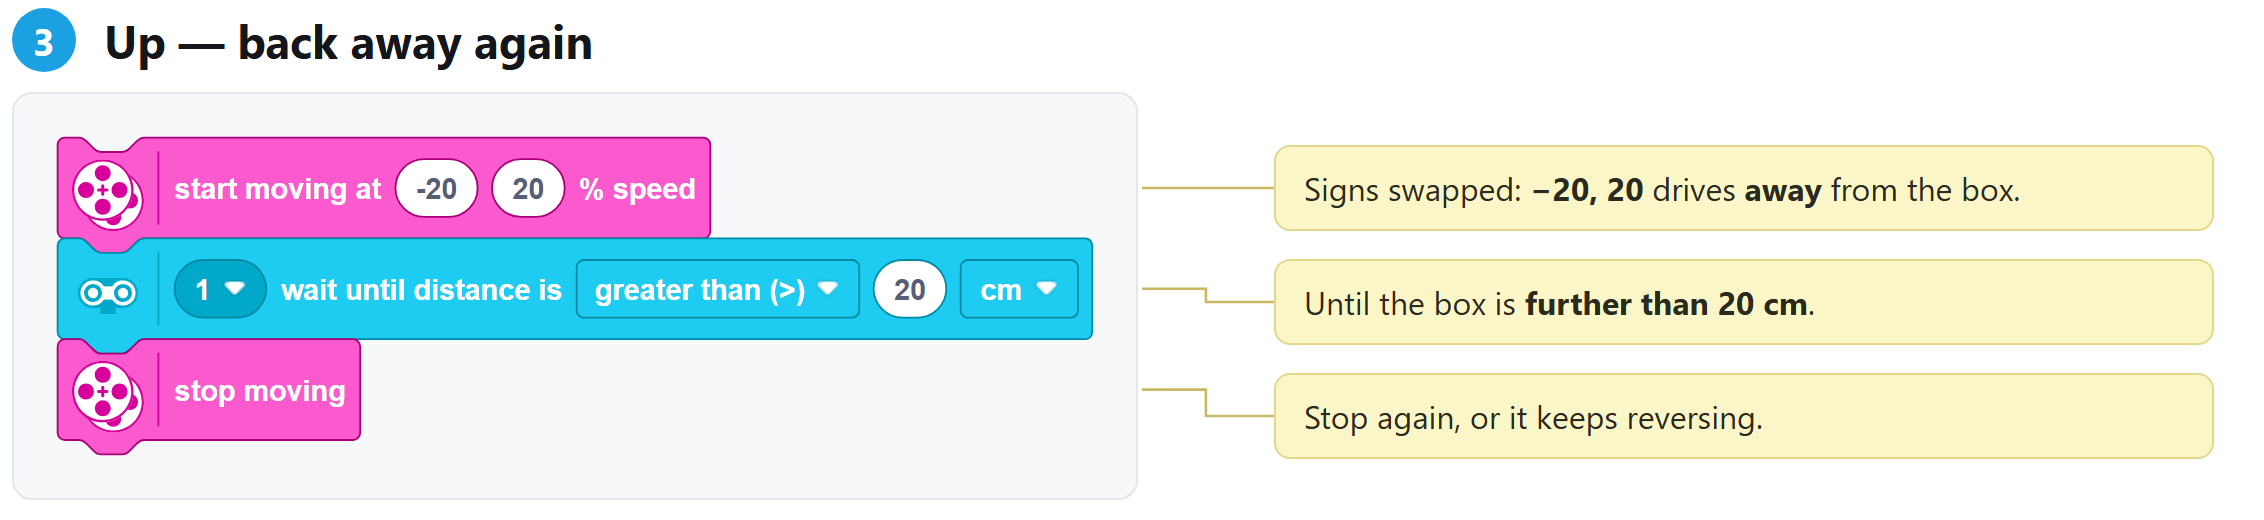
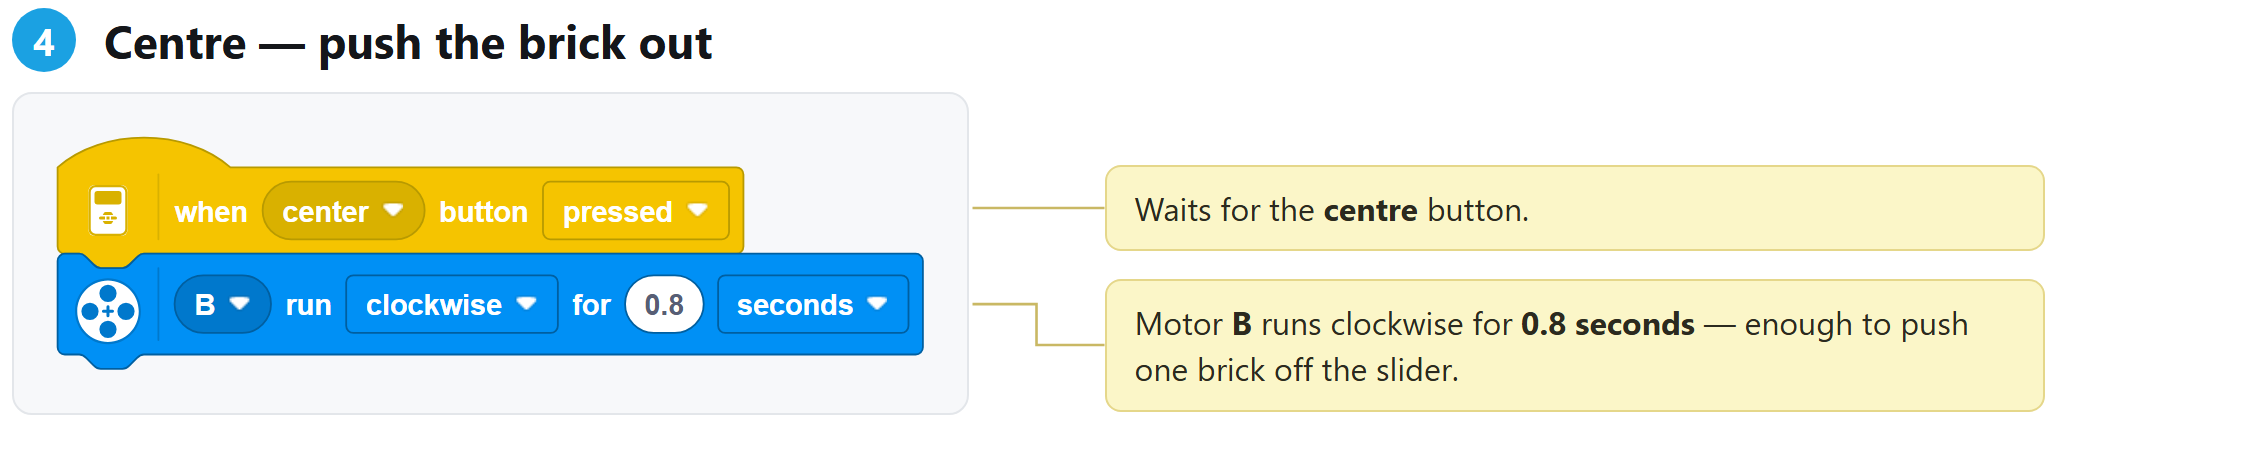
says "Okey-dokey", then backs off until it is further than 20 cm. Centre runs the pusher
for 0.8 seconds to push a brick off the slider. Down reads the colour sensor once and says
"Red" or "Blue".
Each button has its own hat block, so each job is its own little program. Nothing joins them
up yet — that is what the challenges do.
Worth noticing
Waiting is not stopping.Wait until distance is… only pauses the program. The wheels
keep turning until the stop moving block runs.
Less than going in, greater than coming out. Driving towards the box the distance falls,
so the test is less than 10. Backing away it rises, so the test is greater than 20.
Two separate if blocks, not if/else. A brick that is neither red nor blue gets no
sound at all.
The colour is read once, at the press. Show the brick first, then press down.
Challenges 27 min
Work through them in order — each is harder than the last. The extra challenge comes after all three, and it is meant to make you plan before you build.
Challenge 1
Press up button, the robot will stop at red color box using ultrasonic sensor (red box at 10 cm from the box)
Press center button, the robot will stop at blue color box using ultrasonic sensor (blue box at 15 cm from the box)
Press down button, the robot will stop at white color box using ultrasonic sensor (white color at 20 cm from the box)
Hint: for stop at blue color box accurately, you can stop at red color box first using ultrasonic sensor less than 10cm, then stop at blue box using ultrasonic more than 15cm. (Don't use equal 15cm... do you know why?)
Fullscreen it while you build — you can pause and scrub with the player's own controls.
Watch it done
Log in to ask for hints.
Challenge 2
Press center button, if the robot detect red color brick, will sound "Red".
Then after 1 seconds, will sound "3" > "2" > "1" . Before it reach sound "1", you have put the red color brick into the slider.
Once sound "1", then the robot will move and stop red color box, and release the red color brick. Once released, sound "Okay-dokey"