Challenge 1
Rebuild Turn By Degrees. It should wait until the gyro angle has changed by MORE THAN the amount you asked for. It should not wait for it to be equal.
Quick Learn — the model, the instructions, the program and the challenges. The theory is in Full Lesson.
EV3 Robotics›Level 4 · WRO Prep›Lesson 20
Level 4 · Lesson 20 · EV3-L04-2060 minutes · Block 3 of 6 · Mat: WRO 2023 — Connecting the World, Marine Life Preservation
Turn to the angle you actually asked for — and find out why the robot keeps going after you tell it to stop.
Open lesson 14 in your journal and find the three turn measurements: 90, 45 and 180, asked for against achieved. Those are the numbers today beats. Write them at the top of a fresh page before you start.
Two different problems, do not mix them up. Yesterday’s drift happens while the robot stands still. Today’s overshoot happens because the robot is still moving when the decision to stop is made. Calibrating harder will not fix momentum.
Work in the reef square. A to B across the north edge, then the turn down towards D, then west along the south edge to C. Three legs, three corners.
These are the turns that decide the block. A few degrees lost at the first corner puts the robot off-centre at the second. By the third, the attachment arrives where the item is not. That is how errors add up, as you saw in lesson 15. Now it happens on real corners.
The obvious program is: start turning, wait until the gyro reads 90, stop. It fails, and it fails in two different ways that are worth separating.
First, the loop can miss the number entirely. Your program checks the angle, does a little work, checks again. Between two checks the robot has turned by more than one degree. If it was at 89 and the next reading is 91, the angle was never equal to 90. A program waiting for exactly 90 waits forever while the robot spins.
The fix is to stop asking whether the angle equals the target. Ask instead whether it has changed by more than the target. Once it has passed the value, it stays passed. The test cannot be missed, however slow the loop.
Second, the robot does not stop when you say stop. Even with a test that always fires, the wheels are still turning when the decision is made. The motors take a moment to brake, and the robot carries on a few degrees past. That is lag. Better testing cannot remove it, because it is momentum.
Faster turning means more overshoot. That is why your 180 was worse than your 45 in lesson 14: the robot had longer to build up speed. Once students see that connection, the numbers from lesson 14 stop being random and start being a pattern.
Today’s answer to lag is deliberately crude: aim off. If the robot consistently overshoots by five degrees, ask for five fewer. It feels like cheating and it is entirely standard — you are correcting for a known, repeatable physical effect. The elegant answer, slowing down as the target approaches, is proportional control from lesson 11. Next lesson puts it on the gyro, but to hold a straight heading, not to turn.
No building, one decision, written in the journal because everything after it depends on the answer.
Point turn or pivot turn? A point turn spins both wheels in opposite directions and rotates the robot about its own centre. A pivot turn stops one wheel and swings around it.
Point turns keep the robot where it is, which matters when it is already lined up on a station. Pivot turns move the robot as they turn it. Sometimes that is just what you want between reefs. But the turn and the travel are mixed together.
Pick one for this block, use it consistently, and note which. A team that mixes both will find that a turn which worked at one reef behaves differently at the next.
You already have a Turn By Degrees My Block from lesson 14, driven by wheel rotations. Today its insides are replaced while its name and its input stay exactly the same.
That is the reward for lesson 13 arriving before this one. Every program that calls it inherits the improvement without being touched.
Inside the block:
Keep the input meaning what it meant before, including which way a positive number turns. You wrote that down in lesson 14, and every route you have depends on it.
Ask for 90 from a marked heading, three times, and measure what you actually get each time. Then 45. Then 180.
You are looking for two things. How big is the overshoot, and is it consistent? A consistent overshoot is a gift: subtract it from the request and the turns come good. An inconsistent one means something is loose, the battery is low, or the gyro is not rigidly mounted.
Once you have aimed off, run all three again and put the new numbers beside lesson 14’s. That table is the point of the lesson.
Drive the reef square: A to B, turn; B to D, turn; D to C. Use your rebuilt Turn By Degrees for every corner.
Finish by checking the robot’s heading against where it should be. Three turns is enough to show whether your correction holds up when errors stack. If it does not, you have found what lesson 23 will have to solve.
Today’s entry:
This model drives, so its challenges are run on a mat. Mats differ between branches — check you are looking at the one in your room.
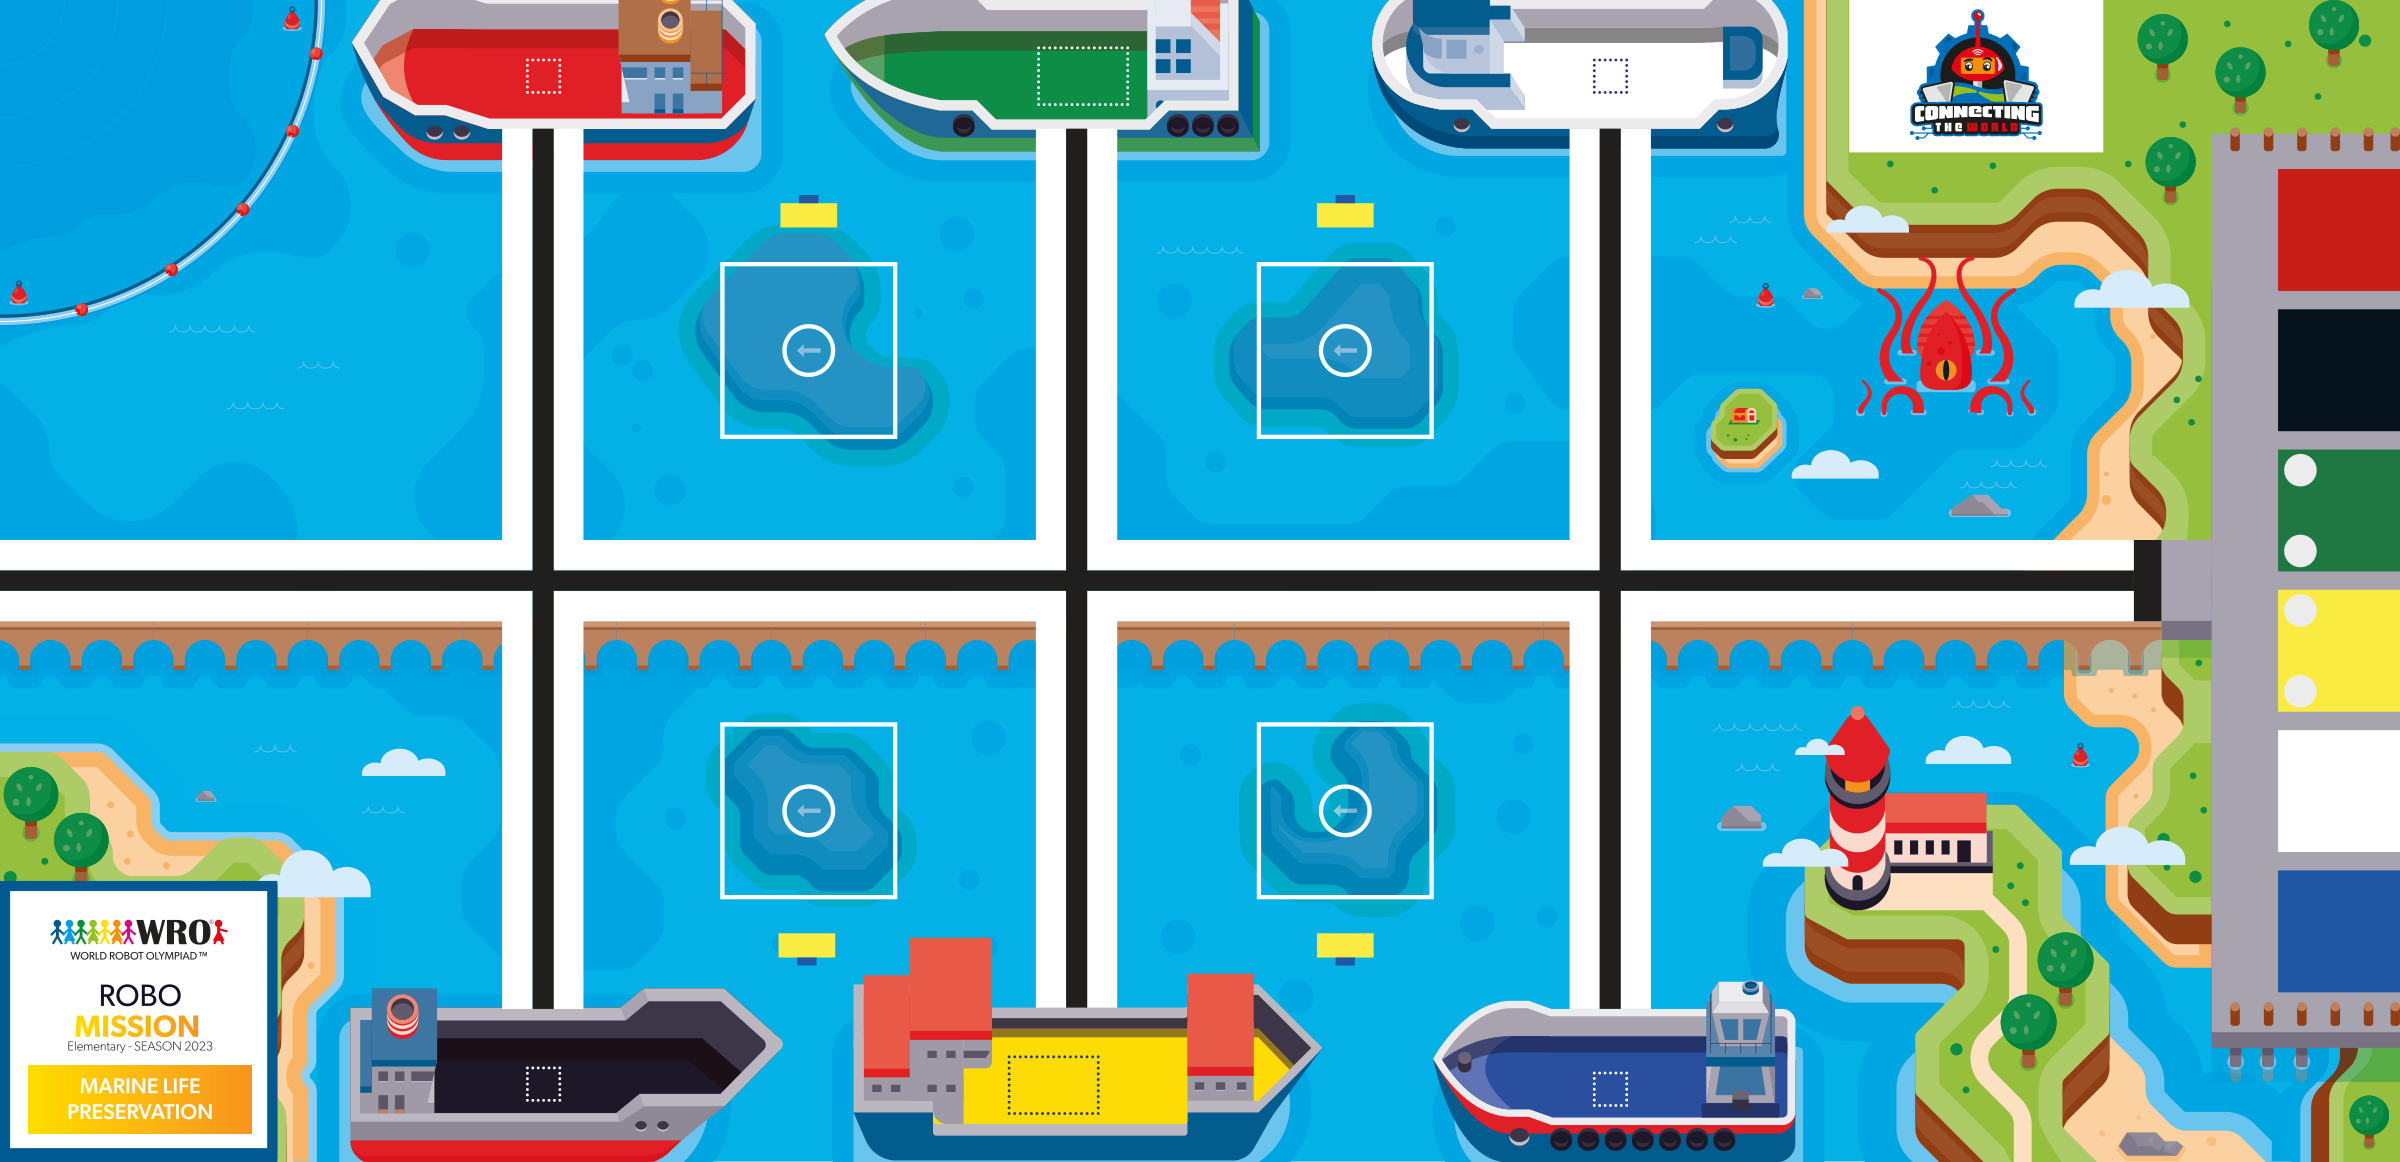
WRO 2023 RoboMission Elementary — Connecting the World — Marine Life Preservation · official WRO game mat, 2362 × 1143 mm
The challenges name these places rather than distances, so the same challenge works on any mat:
Switch mats above and every route below is redrawn on the mat you chose.
Work through them in order — each is harder than the last. The extra challenge comes after all three, and it is meant to make you plan before you build.
Rebuild Turn By Degrees. It should wait until the gyro angle has changed by MORE THAN the amount you asked for. It should not wait for it to be equal.
Start from a marked heading and ask for 90, three times. Measure what you really get. Then do 45. Then 180.
Aim off by the overshoot you measured. Run all three angles again. Put the new numbers beside the ones you wrote down in Lesson 14.
Drive the reef square: A to B, turn, B to D, turn, D to C. Use your rebuilt block for every corner. After three turns, check the robot's heading against where it should be.