Challenge 1
Rebuild all three followers side by side: Follow Line Basic, Follow Line Prop and Follow Line PID. Give each one a speed input. Calibrate once. Run all three over the long leg at the same speed. Write down the time and swings.
Quick Learn — the model, the instructions, the program and the challenges. The theory is in Full Lesson.
EV3 Robotics›Level 4 · WRO Prep›Lesson 30
Level 4 · Lesson 30 · EV3-L04-3060 minutes · Block 4 of 6 · Mat: WRO 2024 — Earth Allies, Sustainable Farming
Three followers, one leg, real numbers. Then an honest answer about which to use where.
You have built three line followers in this course. The two-state one came in lesson 5, the proportional one in lesson 12, and the PID one yesterday. Today they race. Then you decide which follower each leg of the farm route gets.
The answer is not automatically PID. It takes time to tune, and it has more ways to go wrong. On a short hop between two close stations, it may not settle before the leg is over. Today you find out where it is really worth it. That is not the same as which one is cleverest.
The marked fast leg is not enough today. You need a contrast, and lesson 25 gave you one:
Both legs get all three followers. The difference between the two results is the whole lesson. A team that only tests the long leg will get the wrong answer.
There are two fair ways to compare followers, and they answer different questions. Run both, because either one on its own can fool you.
Comparison A — same speed for all three. Pick one speed all three can manage and run them at it. This measures control quality: how close to the line, how much weaving, and how quickly it settles. It puts them on level terms.
Comparison B — each at its own highest reliable speed. Speed each follower up until it stops finishing the leg every time. Then step back one. Run it there. This measures what it buys you in a round.
B is where PID actually earns its place. Its real advantage is usually not better following at the same speed. It is that PID still works at a speed where the two-state follower fails completely. That extra speed saves seconds, and in a round you are racing the clock.
One thing must be identical across every run today: the mid value from your colour calibration. All three followers use it. Re-calibrate once, at the start, and do not touch it again. If the mid value changes halfway through, everything you measured before it is useless.
Battery matters more today than usual too, because you are comparing across a whole lesson rather than within ten minutes. If it drops noticeably, re-run the first follower at the end to see whether the numbers have moved.
You need all three followers available at once. If you edited over the earlier ones, rebuild them. The two-state follower takes five minutes, and you have written it before.
Name them so nobody has to guess: Follow Line Basic, Follow Line Prop, Follow Line PID.
Give each a speed input, so comparison B is a number change and not a rebuild.
Keep all three afterwards. Do not delete the old ones once PID exists. Use simple control on easy legs and PID where it pays. That makes a better program than one that runs PID everywhere. After today you will have the proof for which is which.
Twelve runs at minimum: three followers, two legs, two comparisons. Do each one twice if there is time. One run on a mat proves nothing.
Draw the table before you start. Rows are follower and leg; columns are:
Have one person run and one person record. If you try to remember a number until the end of the lesson, it slowly turns into the number somebody hoped for.
Now answer four questions from what you actually measured:
Expect a mixed answer, and trust it. PID on the long fast leg, proportional on medium legs, and quite possibly the basic follower on short hops. If your table says that, your program should say it too. Using the most advanced tool everywhere is not engineering.
Take the route card from lesson 25. Beside every leg, write which follower it will use and at what speed. Every leg gets an answer.
Then update the program to match, and run the whole route once. Time it, and compare against the walked estimate you wrote in lesson 25.
Lesson 31 will push that total down, by working on the follower choices you just made. Get it written before the milestone, not during it.
This is the entry that justifies the whole block:
This table is worth showing a judge. Judges ask teams to explain their choices. “We tested three controllers over two legs, and here is what each was worth in seconds” is a far stronger answer than “we used PID”.
This model drives, so its challenges are run on a mat. Mats differ between branches — check you are looking at the one in your room.
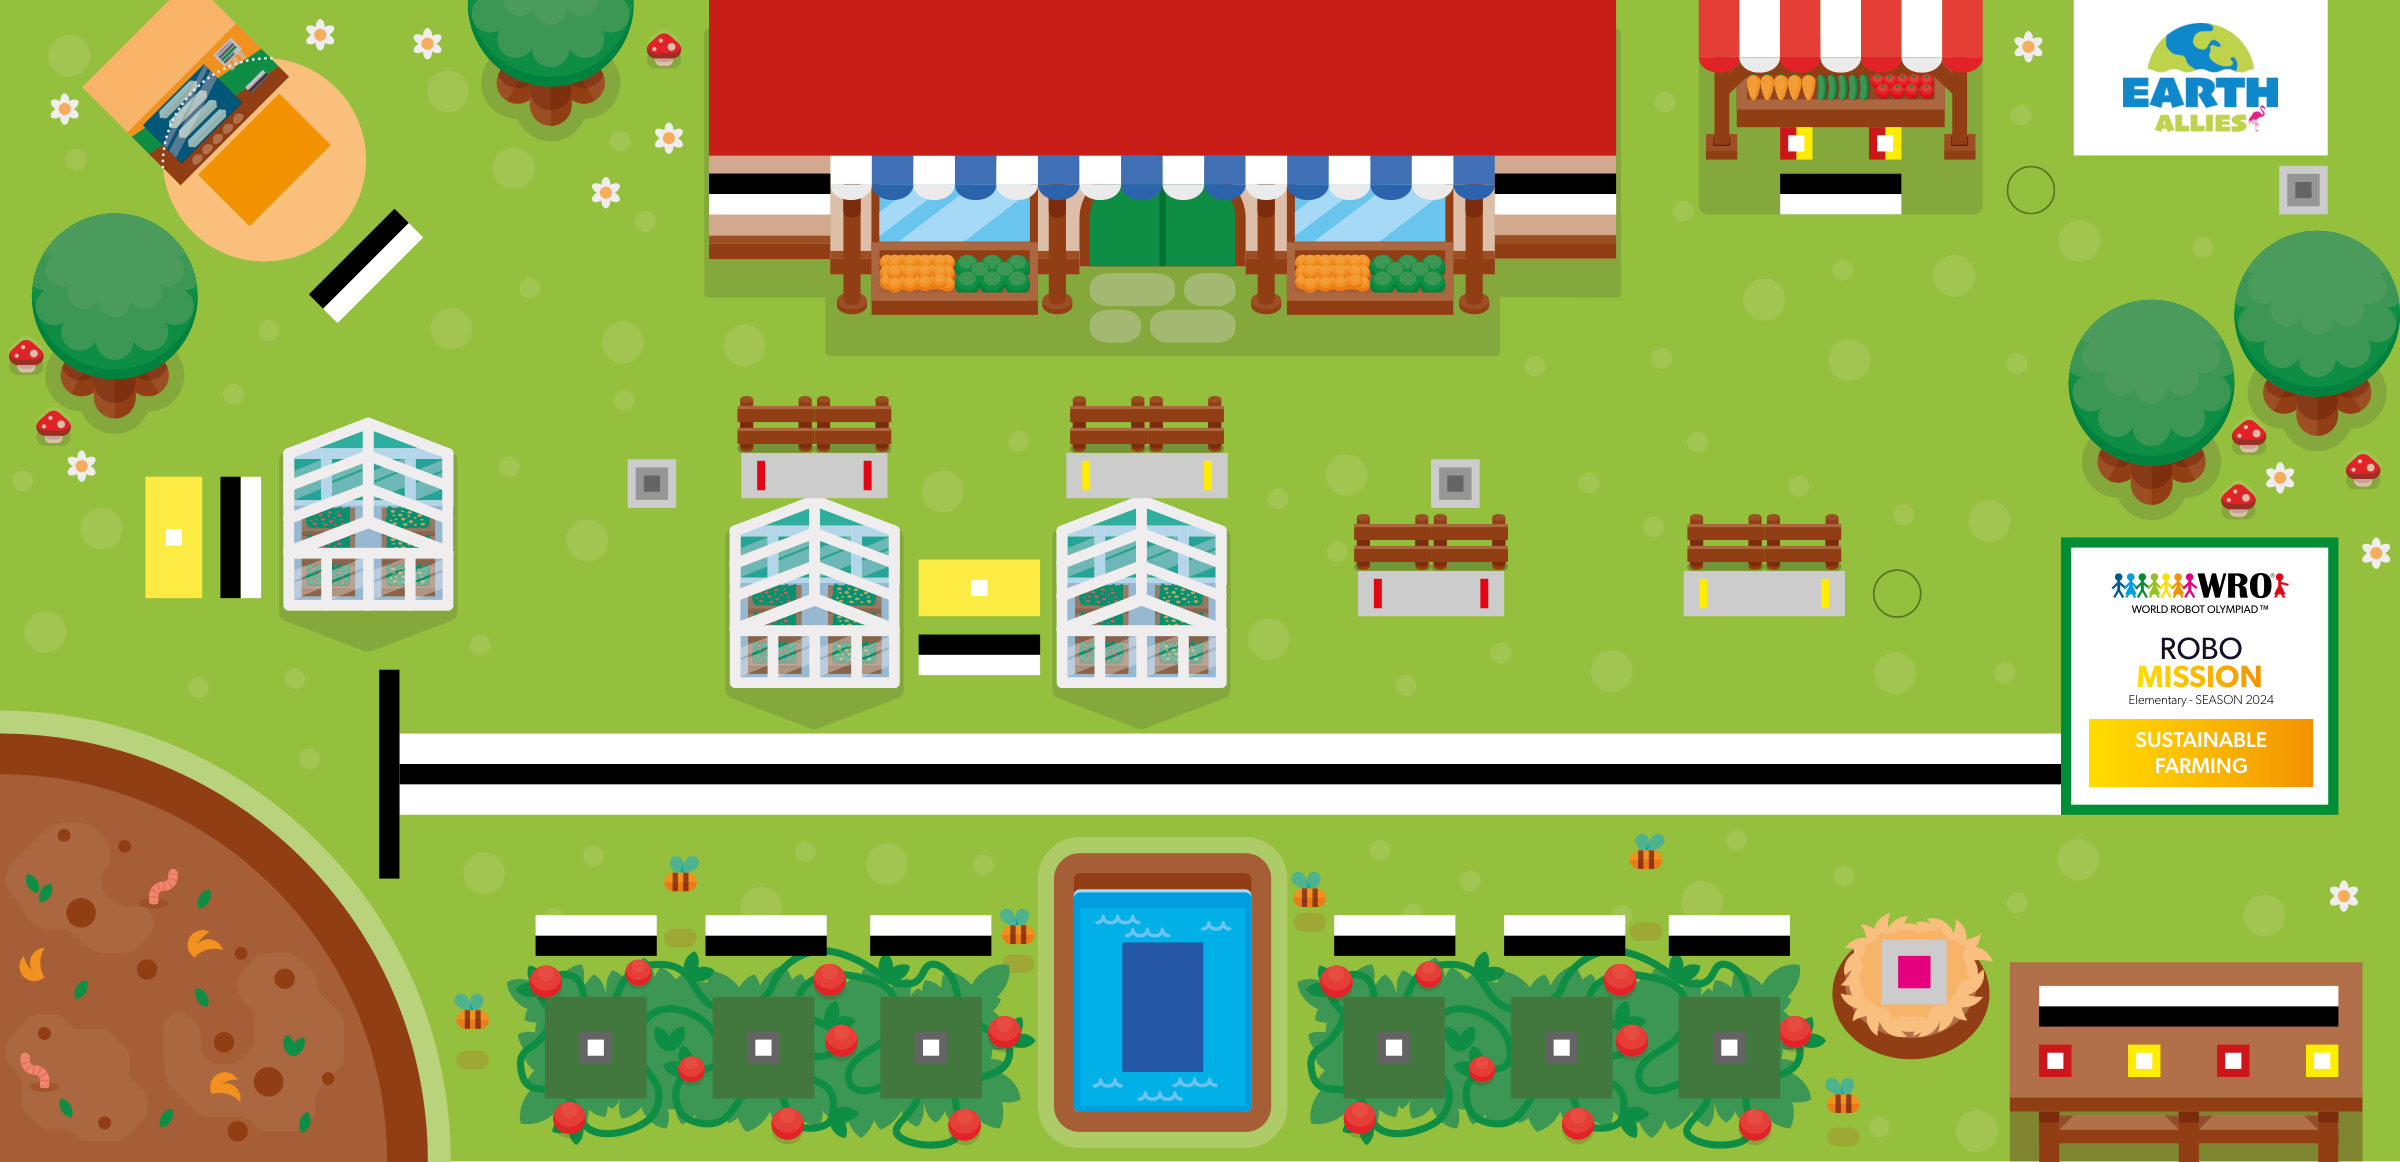
WRO 2024 RoboMission Elementary — Earth Allies — Sustainable Farming · official WRO game mat, 2362 × 1143 mm
The challenges name these places rather than distances, so the same challenge works on any mat:
Switch mats above and every route below is redrawn on the mat you chose.
Work through them in order — each is harder than the last. The extra challenge comes after all three, and it is meant to make you plan before you build.
Rebuild all three followers side by side: Follow Line Basic, Follow Line Prop and Follow Line PID. Give each one a speed input. Calibrate once. Run all three over the long leg at the same speed. Write down the time and swings.
Run the same three over a short hop, from the market barn at A to the vegetable stall at B. Find out how much PID saves there. Do not skip this one. A team that only tests the long leg gets the wrong answer.
Take each follower faster and faster until it stops finishing the long leg every time. Step back one speed and write down its time there. This is where PID really earns its place. It does not follow better at the same speed. It stays usable at a speed the others cannot handle.
Write a follower and a speed beside EVERY leg of the route card. Update the program to match. Run the whole lap and compare it with your walked estimate from Lesson 25. Expect a mixed answer: PID on the long fast leg, something simpler on short hops. Keep all three blocks. Using the most advanced tool everywhere is not good engineering. The table you just built is what you would show a judge.