The Gear Shooter: a motor, a row of gears, and a heavy wheel. The wheel spins faster and faster. Then it throws a gear across the table.
In Lesson 2, your Wipers moved slowly and strongly. That was because a small gear turned a big one. This model does the opposite with the same parts. So it gets the opposite result: fast, not strong.
By the end, you can look at any two gears that touch. You will know if they make things faster or stronger, before you switch anything on.
In the real world 5 min
Where you have seen it
Machines use gears to change speed and force. A bicycle is a good example you can feel. Going up a hill, you use a low gear. Your legs turn fast, but the wheel turns slowly. On flat ground, a high gear does the opposite.
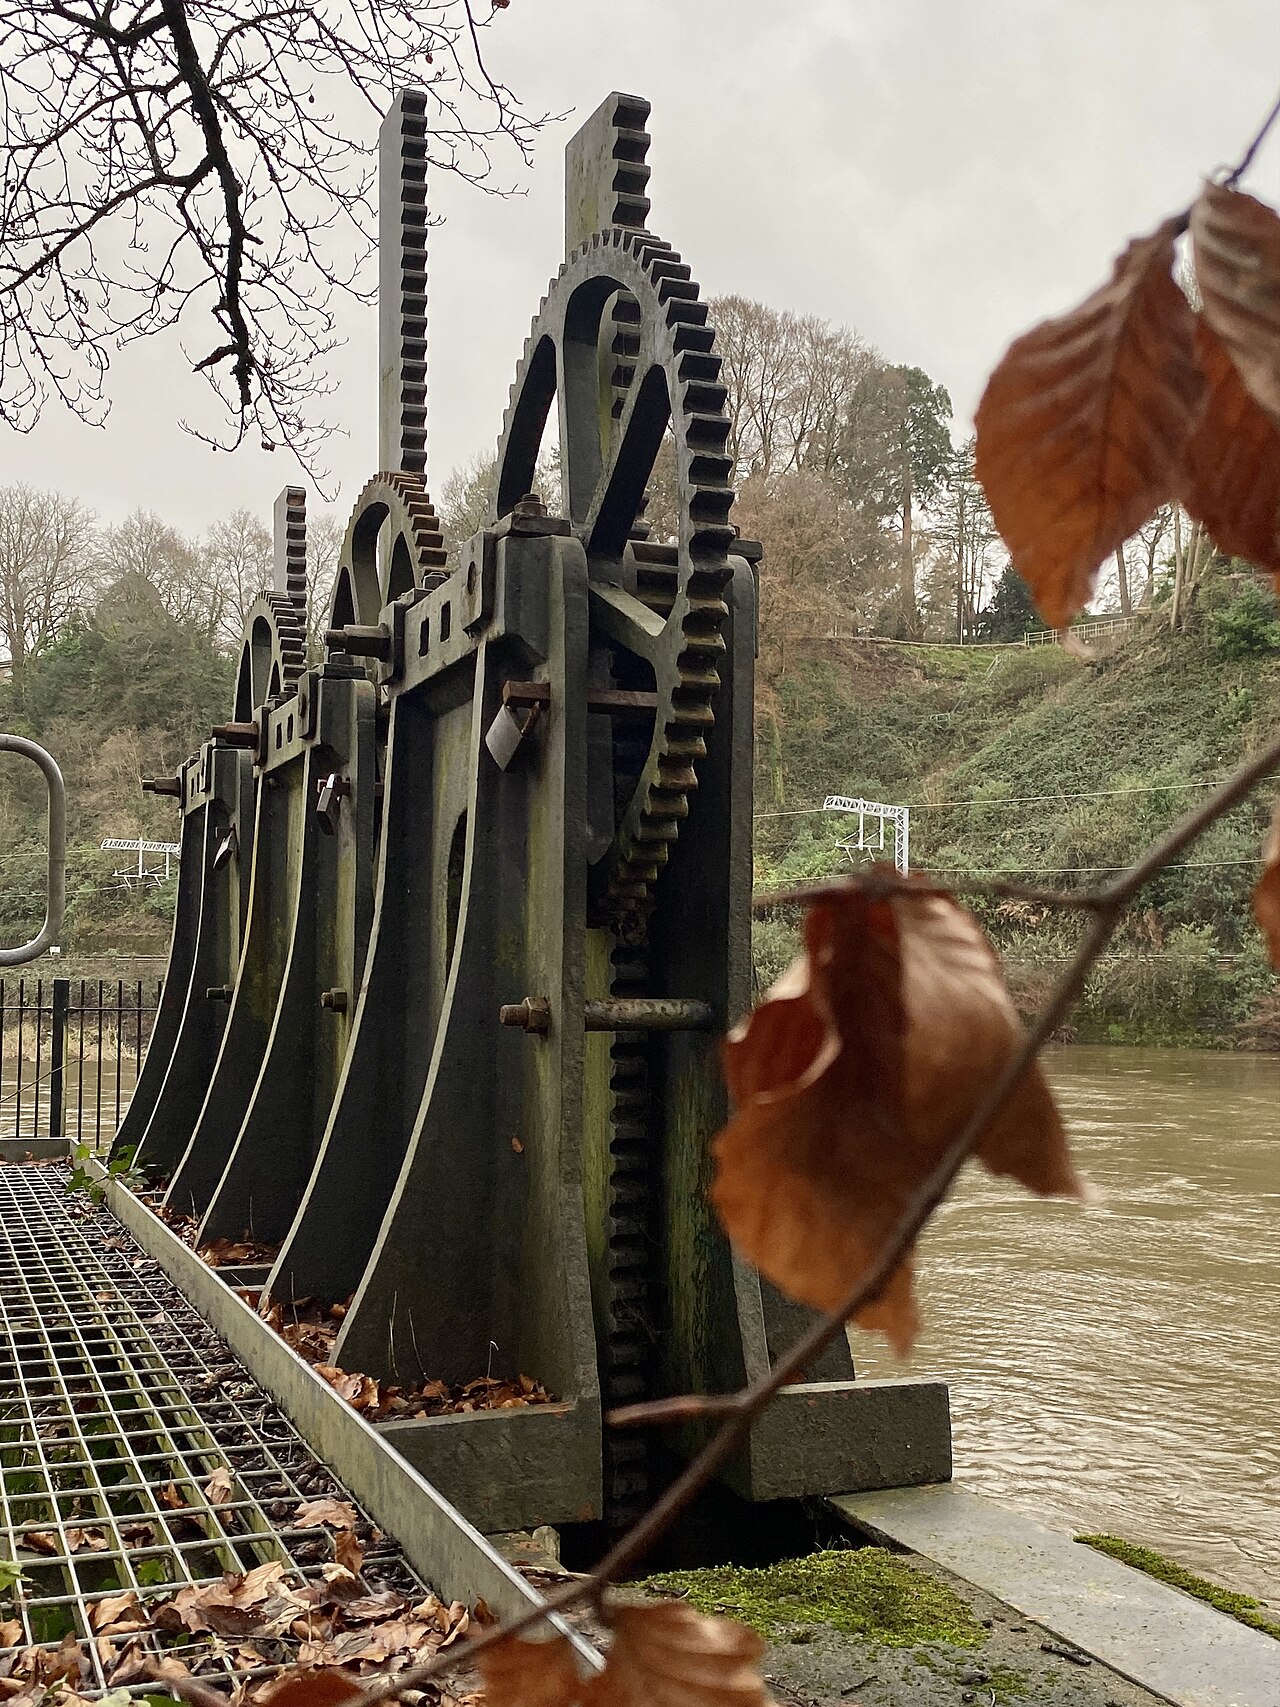
Metal gears that fit together: the teeth of one push the next. Photo: Alan Hughes / Wikimedia Commons (CC BY-SA 2.0).
Why it is built that way
When two gears fit together, their teeth touch. So the teeth must move past at the same rate. A gear with few teeth must turn many times. Only then does a gear with many teeth go round once.
You never get something for nothing. Get more speed, and you lose turning force. Get more turning force, and you lose speed. The teeth decide which.
What would go wrong without it
A motor has one speed it is good at. Fix it straight onto a big fairground wheel, and it is too fast and too weak. It cannot lift the cars. Fix it straight onto a launcher, and it is too slow to throw anything. Gears let one normal motor do both jobs. That is why your kit has a bag full of gears.
The main idea: you cannot get both 6 min
There is one rule. It is true for every machine, everywhere.
A small gear turns a big one: slower and stronger. That is gearing down. A big gear turns a small one: faster and weaker. That is gearing up.
In the demo below, you can count it for yourself. Pick which gear turns which. Then watch the turns and the load.
0.00turns in0.00turns out×3turning force
strongerslowerslow and strong — a lifting winch
Two gears, meshed. The one on the left is being turned; the one on the right is along for the ride.Watch the two counters. They are not climbing at the same rate.Whatever the follower loses in turns, it gains in force — and whatever it gains in turns, it loses in force. There is no setting that gives you both.Finished. Count the turns again with a different pair and the trade goes the other way.
stopped
The number of teeth is the whole story. 8 teeth driving 24 means 8 ÷ 24 of a turn out for every turn in — and the force changes by exactly the opposite amount.
Two of your models use the same rule, but opposite ways round:
Model
Driver → driven
What the machine gets
Wipers (Lesson 2)
small gear → big gear
Geared down. A slow arm, strong enough to push a blade across wet glass.
Gear Shooter (today)
big gear → small gear
Geared up. A shooting wheel that spins much faster than the motor. But it is easy to slow down.
▶Gearing up and down, and which way things turnHow both work. Open it if you are not sure about faster or stronger, or which way two gears turn.Show meHide
ComponentMechanics5 min
Gearing up and gearing down
Two meshed gears are a bargain. Whatever one of them gains in turns it loses in force, and whatever it loses in turns it gains in force. There is no arrangement of gears that gives you more of both, and no amount of building will find one.
The ratio is the teeth
Count the teeth on the gear you are turning (the driver) and the teeth on the one being turned (the follower). That is the whole calculation:
turns out = turns in × driver teeth ÷ follower teeth
An 8-tooth gear driving a 24 gives ⅓ of a turn out for every turn in — and three times the turning force. Turn the pair round and you get three turns out and a third of the force. Count the turns yourself below.
0.00turns in0.00turns out×3turning force
strongerslowerslow and strong — a lifting winch
Two gears, meshed. The one on the left is being turned; the one on the right is along for the ride.Watch the two counters. They are not climbing at the same rate.Whatever the follower loses in turns, it gains in force — and whatever it gains in turns, it loses in force. There is no setting that gives you both.Finished. Count the turns again with a different pair and the trade goes the other way.
stopped
The number of teeth is the whole story. 8 teeth driving 24 means 8 ÷ 24 of a turn out for every turn in — and the force changes by exactly the opposite amount.
Gearing down, gearing up
Arrangement
Turns
Force
What it is for
Gearing down — small driving large
fewer
more
winches, lifts, robot arms, anything that has to move a weight
Gearing up — large driving small
more
less
fans, spinners, launchers, wheels on a light fast robot
1 : 1 — same size
same
same
moving the drive to a different axle, or fixing a direction
The names are worth getting right because they are backwards from what people expect: gearing down makes the output slower, not smaller, and it is the setting that makes a weak motor able to lift things.
Gear trains
Put several pairs in a row and the ratios multiply. Two 1:3 reductions in series give 1:9 — which is how a Medium Motor ends up able to raise something it could never shift directly. This is also how a gearbox with a sensible number of parts reaches a ratio that a single pair never could: a 40-tooth gear driven by an 8 is 1:5, and doing it twice is 1:25.
Only the first and last gear affect the ratio. Anything in the middle passes the motion along and changes nothing but the direction — which is a whole idea of its own, in Changing the direction of a turn.
What it costs
Every mesh loses a little to friction, so a long train is less efficient than a short one. Gearing down far enough to lift a heavy load also makes the mechanism slow, and slow is not always acceptable. And a gear train that is geared down hard is very hard to turn backwards by hand, which is either a useful brake or a nuisance depending on what you are building.
Why it matters
A bicycle is the same idea with a chain instead of teeth in mesh: the low gear that gets you up a hill is turning the back wheel slowly and pushing hard, and the high gear you use going downhill does the opposite. Cars, drills, cranes and clocks are all making the same trade.
ComponentMechanics4 min
Changing the direction of a turn
Gears do two jobs and they are worth keeping apart. One is the trade between turns and force — that is Gearing up and gearing down. The other is geometry: which way the far end turns, and about which axis.
Meshed gears turn opposite ways
This follows from what a tooth actually does. Where two gears touch, one tooth is pushing the other sideways — so they cannot possibly be going the same way round. Every mesh in a train flips the direction again.
Two gears — one mesh — the output turns backwards.
Three gears — two meshes — the output turns the same way as the input.
An odd number of gears comes out the same way; an even number comes out reversed.
The idler gear
A gear dropped between two others changes the direction and nothing else. Its own size cancels out — it takes exactly as much as it gives — so the ratio is still first gear ÷ last gear however big or small the middle one is.
That makes an idler the normal, sensible way to fix a direction. It costs one gear and one hole in a beam, and it is a far better answer than rewiring a motor or writing counterclockwise in half your program and forgetting it in the other half.
1meshesoppositedirection out1 : 1ratio
even number of meshes → backwardsteeth set the ratio, meshes set the direction
Two meshed gears. Where they touch, one tooth is pushing the other — so they cannot possibly turn the same way.Driver clockwise, follower anticlockwise. An even number of gears in a train always comes out backwards.If a wheel goes the wrong way, do not rewire the motor — add a gear, or take one out.Finished. Count the meshes: an odd number comes out the same way, an even number comes out backwards.
stopped
Watch the red marks, not the gears. Two gears meshed together can never turn the same way — everything else follows from that one fact.
Turning the corner: 90° drives
Ordinary spur gears keep the two axles parallel. Some jobs need the output at right angles to the input — a motor lying flat in the chassis driving an upright turntable, or a horizontal axle driving a vertical drill.
Crown gear (the one with its teeth standing up on the rim) meshed with an ordinary spur gear. Simple, common in the EV3 set, and fine at modest loads.
Bevel gears, cut at an angle and used in pairs. Stronger and quieter than a crown pair, and the right choice if the corner is carrying real force.
Worm gear driving a spur gear. Also turns the corner, gears down enormously in one step, and cannot be back-driven — the output cannot turn the input. That last property makes it the standard choice for a lifting arm that must hold its position when the motor stops.
The teeth still set the ratio in all of these. Changing the axis and changing the speed are separate decisions that happen to be made by the same pair of parts.
Direct connection — no gears at all
Two parts on the same axle turn together, at the same speed, in the same direction, with no losses. It is the simplest answer and worth reaching for first: if the motor can already do the job at its own speed and force, gears add friction, backlash and parts for nothing.
Gears earn their place when you need a different speed, a different force, a different direction, or the drive to come out somewhere the motor cannot reach.
Why it matters
A car’s differential is a set of bevel gears turning the drive shaft’s rotation through 90° to the wheels. A hand drill turns your horizontal cranking into vertical drilling with the same trick. Once you can see the corner, you start seeing it everywhere.
Say this out loud before you go on: “Gears do not make anything new. They swap speed for force. I choose which way by choosing which gear turns which.”
What’s in this build 4 min
Two electronic parts again, and lots and lots of gears.
EV3 Brick × 1
Large Motor × 1
The Gear Shooter's electronics: one Brick and one Large Motor. Everything between the motor and the shot is gears and parts.
Follow the gears with a finger
Start at the motor. Follow the gears one by one to the big wheel with the tyre. Where two gears touch, ask: is the turning gear bigger or smaller than the one it turns?
Count the teeth on the gear on the motor’s axle.
Count the teeth on the gear it touches.
Keep going to the last gear. Write each pair down.
Now turn the motor’s axle once, by hand. Count how many times the shooting wheel goes round.
That last number is your gear ratio. You measured it, not worked it out. Keep it. You need it for Challenge 3 and the mission.
The heavy wheel has a job too. It is not just a wheel. It is a flywheel. Once it spins, it keeps its speed. That gives the shot its punch. A light wheel at the same speed would not throw as far.
Ports — and the rule 4 min
Sensors go in ports 1, 2, 3, 4. Motors go in ports A, B, C, D. You cannot swap them. If you do, nothing warns you. The robot just will not work.
Part
Port
Why this one
Large Motor (drives the gear train)
A
When there is only one motor, it usually goes in A. Every program on this page says A.
Safety. This really matters. This model throws a gear hard enough to sting. Point it down the table. Never point it at a person or a face. Keep fingers away from the spinning wheel. It will not stop for a finger.
Check your own build now:
Motor cable in port A — a letter, not a number.
Turn the motor axle by hand. Does every gear turn?
Can the shooting wheel spin without rubbing the frame?
Is the model pointing somewhere safe?
Connect the Brick 4 min
Two routes, and either is fine. USB is the reliable one and the one to fall back on when a room’s Bluetooth is busy; Bluetooth leaves the robot free to move, which some models need.
▶How to connect the BrickUSB and Bluetooth, step by step, with a photograph of every screen. Open it if you have not done this before — or if pairing is not working.Show meHide
USB — the reliable one
Switch the Brick on with the dark grey centre button.
Cable into the Brick’s PC port — the small square socket beside the numbered ports, not one of the numbered ones.
Other end into the computer.
Bluetooth — name it first
Do these in order. Naming the Brick after you go looking for it in the list is how groups end up driving each other’s robots.
Name your Brick. On the Brick: Settings (the spanner) → Brick Name. Type something nobody else will pick, then press the tick. Every Brick is called EV3 until somebody changes it.
Turn Bluetooth on. Settings → Bluetooth. Tick Bluetooth and Visibility. Leave iPhone/iPad/iPod unticked.
Connect from EV3 Classroom. Click the Brick icon at the top of the programming area, find your Brick by name, and click Connect.
Say yes on the Brick. It asks “Connect?” with the computer’s name — choose the tick, then accept the passkey, which is already 1234.
Where to read it. The name sits in the bar across the very top of the screen, on every screen — so you can check which Brick you are holding at any moment without going into a menu. This one is EV3VE. A Brick nobody has renamed says EV3.Step 3, and the reason step 1 exists. Three Bricks in range — read the name before you click Connect. Pairing with the wrong one is not an error: it works perfectly, on somebody else’s robot.
Step 2.Bluetooth switches the radio on; Visibility is what lets the computer find you. With Visibility off your Brick works perfectly and simply never appears in the list.Step 4. Look at the Brick. It asks whether to accept and names the computer. Choose the tick.Then the passkey, already 1234. Press the tick again and you are connected.
The two failures, every class, every time. The Brick has gone to sleep while you were building — press the centre button to wake it. Or you have paired with the group at the next table, which is why the name matters.
The long version, including Port View and how to read the port tiles, is in the Brick & Bluetooth guide.
Use Bluetooth today if you can. This model throws things. It is easier to aim safely without a short cable tying it to a laptop.
Confirm the connection 2 min
Check the Brick icon: connected, or not.
Check the port tiles. A motor on A, and nothing anywhere else.
Turn the shooting wheel by hand and watch the degrees counted number race up.
That third step shows the gear ratio again. Turn the shooting wheel a little, and the number jumps a lot. Why? The counter is in the motor, and here the motor end turns more.
If the number does not move at all, stop here. The cable is in the wrong port, or not pushed all the way in.
Change it and test 8 min
Make one change at a time. Guess what will happen before each run. Measure how far the gear lands each time. Put the gear in the same spot every run. If not, you are testing your hands, not the robot.
Change the wait to 0.5 seconds. Guess: will a shorter spin-up throw less far? By how much?
Now try 4 seconds. Does it keep getting better? Or does it stop helping once the wheel is at full speed?
Go back to 2 seconds. Drop the speed to 50 %. Guess first.
Hold the shooting wheel gently with a finger while it spins up at 50 %. Then try at 100 %. It is easy to slow down. That is the cost of gearing up. The Wipers made the same swap, the other way round.
If the gears grind or get stuck, a gear has slid along its axle. Now only half its teeth touch. Push each gear firmly against its bush. Turn the gears by hand to check they move freely. Then run the motor again.
Build it 15 min
Build the model before you read any further. Everything after this is about making it do something, and none of it will make much sense with nothing on the table in front of you.
Fullscreen it while you build — you can pause and scrub with the player's own controls.
Check the finished build against the picture before you switch anything on. A motor mounted the wrong way round is far easier to spot now than it is to debug later, when it looks like a program fault.
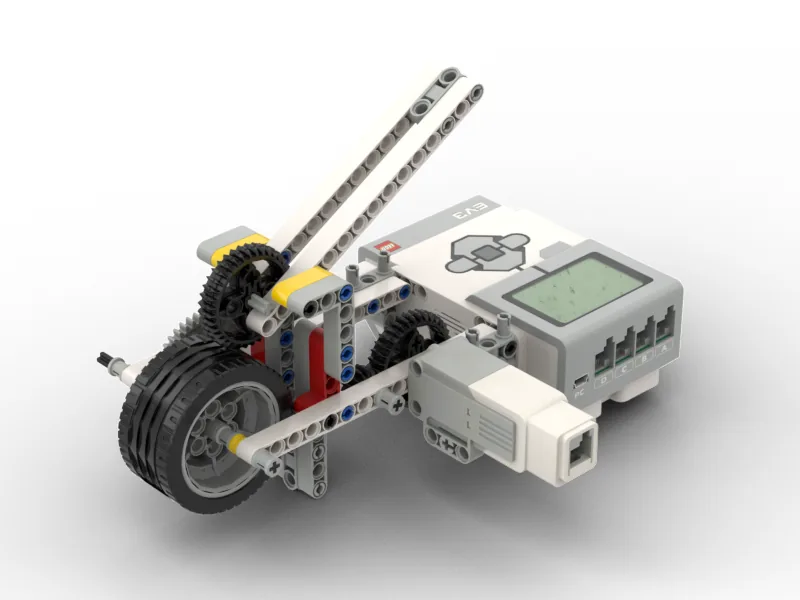
This is what you are building: the Gear Shooter.
Make it move 10 min
A flywheel needs time to get up to speed. So the program has the EV3 Fan's shape: start, wait, stop. But the numbers are turned right up.
when program starts :: events hat
[A v] set speed to (100) % :: motors
[A v] start motor [clockwise v] :: motors
wait (2) seconds
[A v] stop motor :: motors
Full speed, two seconds to spin up, then stop. Put the gear in before you press play.
Go through it in the order the Brick runs it:
set speed to 100 % — a launcher needs all the power the motor has. The Walking Bot needed 40 %. Same block, different job.
start motor — the gears start turning. The program goes straight on to the next block.
wait 2 seconds — the spin-up. The flywheel keeps getting faster all this time.
stop motor — the end of the run.
What success looks like: a whirr that gets higher as the wheel speeds up. Then the gear flies down the table. If it just drops out, the wheel was not fast enough yet. Give it longer before you blame the build.
Challenges 27 min
Work through them in order — each is harder than the last. The extra challenge comes after all three, and it is meant to make you plan before you build.
Challenge 1
Make the shooter throw weakly on purpose. The shot must go less than half as far as your best one. Do it three times in a row. All three must land within a hand-span of the same spot. Weak is easy. Weak and the same each time is the challenge.
Challenge 2
Find the shortest spin-up time that still throws the gear its full distance. The spin-up is the wait while the flywheel gets up to speed. Test at least four different wait times. Measure where the gear lands each time. At about what point does more spin-up stop helping? Say why a flywheel works that way.
Challenge 3
Work out the gears on your own model. Turn the motor axle one full turn by hand. Count how many times the shooting wheel turns. Then write down each gear pair in the train. For each one, say if it gears up or down. You must measure your ratio on the model. Do not copy it from the lesson.
Extra challenge
Two shooters, same kit, opposite jobs.
Your team must make a shooter that throws as far as it can. Then make a second one that throws as gently and as well aimed as it can. It must hit a target as wide as a book. You may rebuild the gears between them, and you should. The answer is not only in the program.
Plan on paper before you take anything apart. Decide which gears you will change. Predict what each change will do. Then test if the model agrees with you.
You will be asked three questions when you show it. Which change made the biggest difference, the gears or the program? What did you give up to get distance? And if you got one extra gear of any size, where would you put it? Why?