Challenge 1
Add 2 touch sensors to your robot. One touch sensor makes the bionic leg move forward (clockwise). The other one makes it run backward (anticlockwise). If no touch sensor is pressed, the motor stops.
Quick Learn — the model, the instructions, the program and the challenges. The theory is in Full Lesson.
EV3 Robotics›Level 2 · Intermediate›Lesson 10
Level 2 · Lesson 10 · EV3-L02-1060 minutes · Ages 8+ · Model: Bionic movement
The Bionic movement model. It is a robot arm or leg. One Large Motor moves it, through a set of joined parts called a linkage. It is built to move like a real joint in your body.
In most lessons so far, the model stayed as you built it. You changed the program. Only the Strong Lifter, in Lesson 4, was different.
Today it is the other way round, all lesson. You write the program once. Then you never touch it again. You change the machine instead. The program stays the same. So if anything changes, the build did it. Nothing else could.
Some people use a prosthetic hand or leg. That is a body part made by people, for someone who needs one. Today, they can look like cool robot gear. A new bionic hand can be made on a 3D printer. Small motors pull on strings, like the cords in your own hand. Those cords are called tendons. And it costs much less than one did ten years ago.
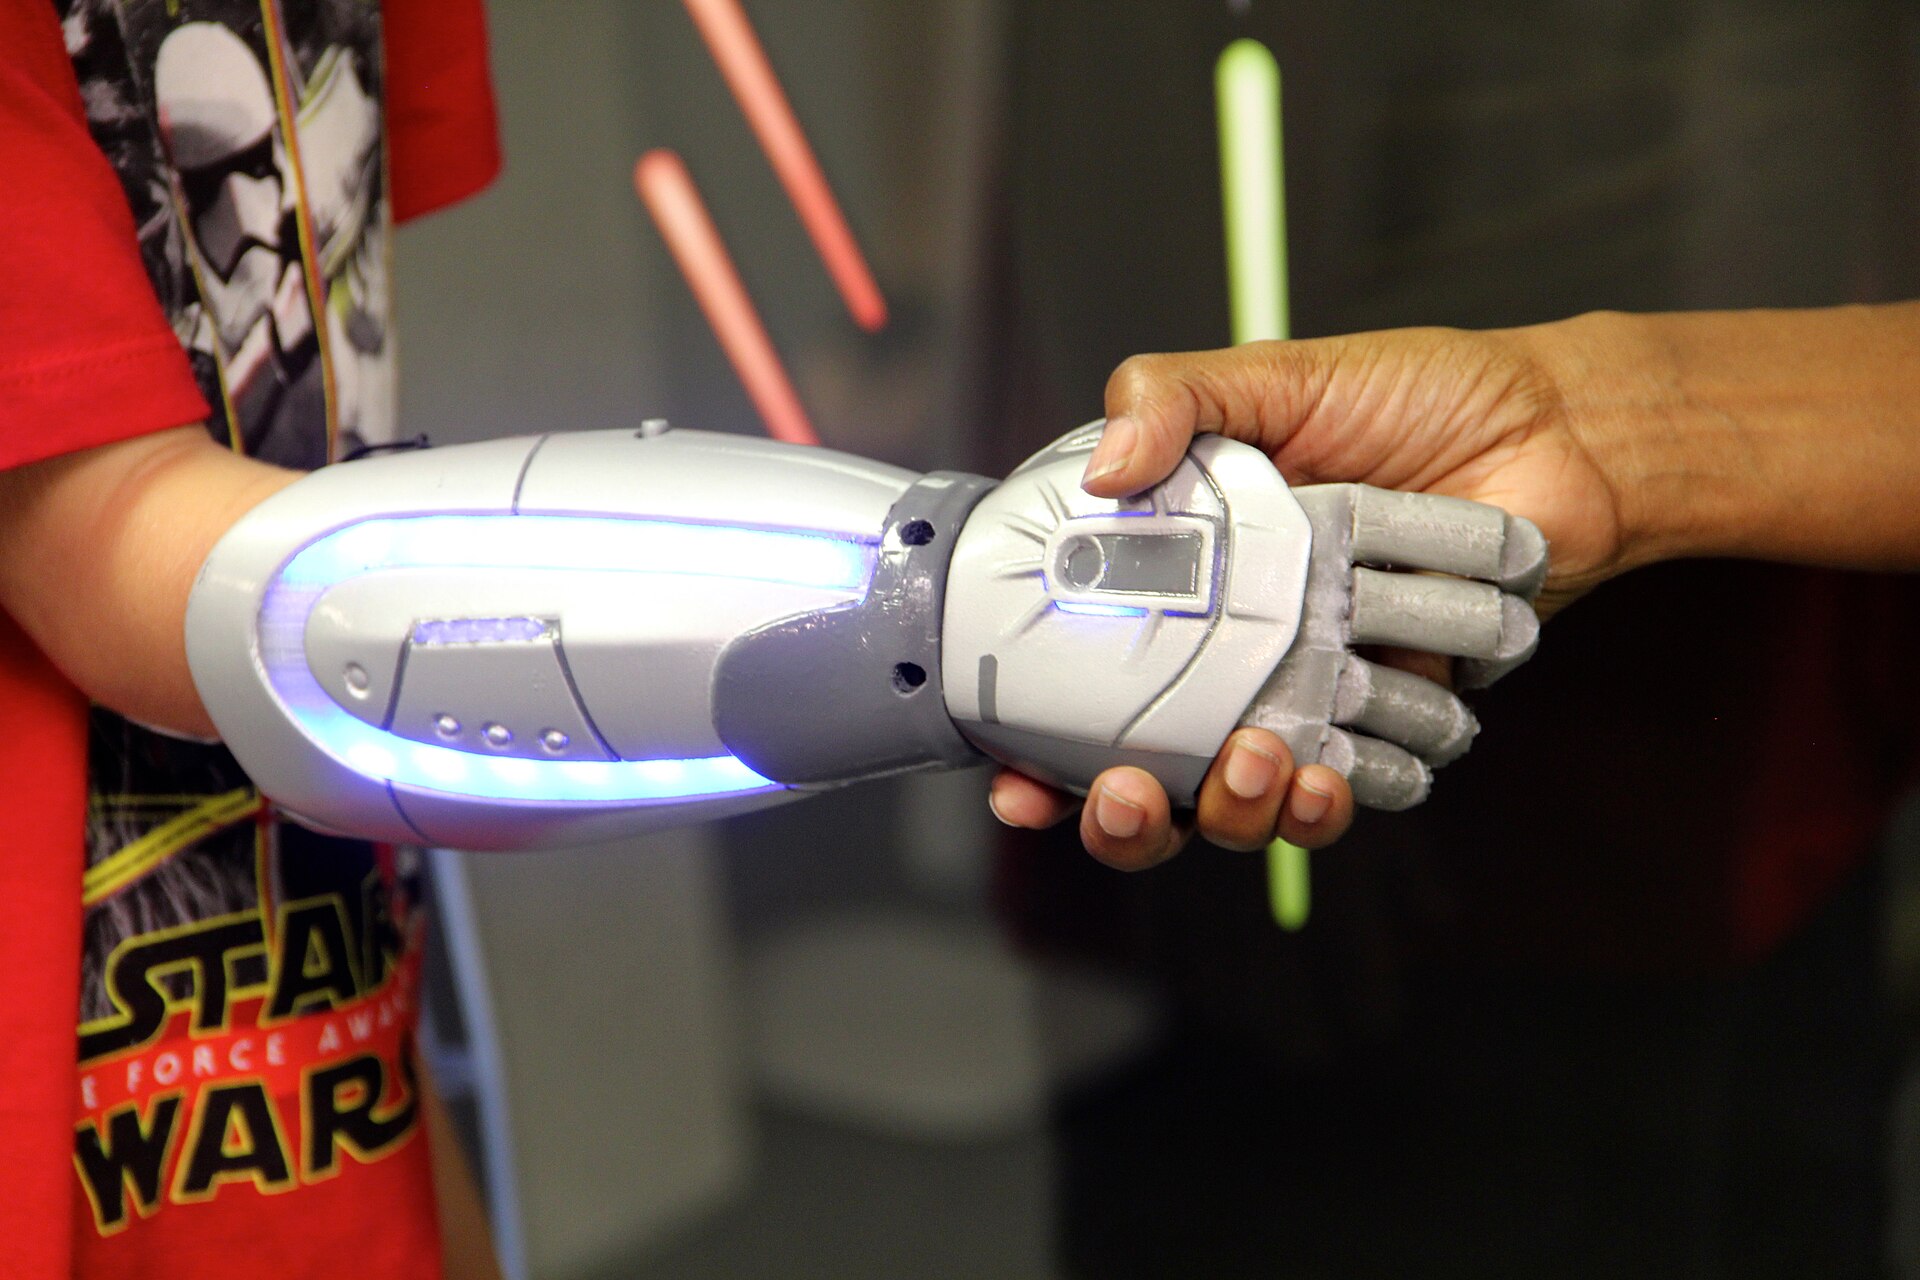
A hand like that took hundreds of tries to get right. Each time, the makers changed one thing. Maybe the length of one tendon. Maybe where one joint goes. Maybe the gears on one motor. Then they tested it, measured it and compared. They kept the better one.
The tests only work because everything else stays the same. Same grip test. Same object. Same signal to the motors. Say you change the tendon and the program in the same week. Then you will never know which one made the difference. You just have a hand that is different.
Say an engineer changes two things at once, and it gets better. They have learned nothing. They cannot do it again on purpose. Maybe one change made it worse. They cannot tell which one to undo. And their next change will just be a guess on top of a guess.
If you change two things and it gets better, you do not know why. And not knowing why is the same as not knowing.
A fair test has one thing you change. It has one thing you measure. And it has a long list of things you leave alone, on purpose.
| Job | Today that is… |
|---|---|
| What you change | One thing about the moving parts. A gear, the length of a part, or where a joint goes. One. |
| What you measure | How long one set movement takes. The Brick’s own timer measures it. |
| What you keep the same | The program, the speed, the number of rotations, the surface, the battery and the load. And the person doing the timing. |
This is a short program. It is not the main point of the lesson. Its job is to stay the same for every test. A ruler is the same for every measurement in the same way:
when program starts :: events hat
clear display :: display
[A v] reset degrees counted :: motors
reset timer :: sensors
[A v] run for (5) [rotations v] at (50) % speed :: motors
write [Time:] at line (1) :: display
write (timer) at line (2) :: display
Do not change the program. You are used to changing it, so you will want to. If a change to the build is a let-down, you will want to change the speed. Don’t. If you do, all your earlier measurements are wasted. You took them with a different tool.
Batteries run down. New parts loosen up a little as they move. A motor that has just been running is warmer than one that has not. So run every version three times and take the middle number. Are the three numbers very different? Then that is what you found. Something about your build is not steady. One number alone would never have told you.
Some models have no motors and no sensors at all. They are not lesser lessons — they are where the physics lives. A build that stores energy, changes a force, or turns one kind of motion into another explains why the powered models later need the gearing and the speeds they do.
Gears, pulleys and levers look like three different topics and are three shapes of the same deal: whatever you gain in force, you pay for in distance. Halve the effort and you move twice as far; move half as far and you need twice the effort. No arrangement of anything gives you both, and recognising that saves a great deal of time hunting for one.
What a mechanism actually does is let you spend the same effort in a form you can manage — a little at a time instead of all at once, or all at once instead of a little at a time.
| Tutorial | The question it answers |
|---|---|
| Gearing up and gearing down | How do I trade turns for force? |
| Changing the direction of a turn | Why is it going backwards, and how do I drive an axle at 90°? |
| Pulley systems | How does a rope let a small motor lift a big load? |
| Levers — effort, load and pivot | Where should the pivot go? |
| Elastic and stored energy | How much further does pulling back twice as far actually get me? |
| Scissor mechanisms | How do I make something extend a long way — and why won’t it start? |
| Oscillatory motion | How do I turn going round into going back and forth? |
| Centre of gravity | Why does it keep falling over? |
| Biomimetic mechanisms | How does a machine walk without ever being told to? |
Friction is what makes wheels grip and also what wastes effort. Every mesh, pin and rope turn loses a little to it, so a mechanism with more parts delivers less than the arithmetic promises. A build that binds — that is stiff to move by hand — is losing far more than that, and no amount of extra motor power fixes a mechanism that is rubbing.
Before measuring anything, turn the mechanism by hand. It should move smoothly and coast a little. If it does not, fix the build first; numbers taken off a binding mechanism describe the binding, not the idea you were trying to test.
Since there is nothing to program, the work is measuring. Change one thing, keep everything else the same, and record what happened — pull the car back 5 cm, then 10, then 15, and measure how far each one travels. Three readings at each setting, not one, because a single run is not evidence.
That is genuinely how engineers test, and it is the same discipline that makes debugging a program work: change one thing at a time.
Change one thing. Measure the same way. Write it down before you touch anything else.
Two meshed gears are a bargain. Whatever one of them gains in turns it loses in force, and whatever it loses in turns it gains in force. There is no arrangement of gears that gives you more of both, and no amount of building will find one.
Count the teeth on the gear you are turning (the driver) and the teeth on the one being turned (the follower). That is the whole calculation:
turns out = turns in × driver teeth ÷ follower teeth
An 8-tooth gear driving a 24 gives ⅓ of a turn out for every turn in — and three times the turning force. Turn the pair round and you get three turns out and a third of the force. Count the turns yourself below.
The number of teeth is the whole story. 8 teeth driving 24 means 8 ÷ 24 of a turn out for every turn in — and the force changes by exactly the opposite amount.
| Arrangement | Turns | Force | What it is for |
|---|---|---|---|
| Gearing down — small driving large | fewer | more | winches, lifts, robot arms, anything that has to move a weight |
| Gearing up — large driving small | more | less | fans, spinners, launchers, wheels on a light fast robot |
| 1 : 1 — same size | same | same | moving the drive to a different axle, or fixing a direction |
The names are worth getting right because they are backwards from what people expect: gearing down makes the output slower, not smaller, and it is the setting that makes a weak motor able to lift things.
Put several pairs in a row and the ratios multiply. Two 1:3 reductions in series give 1:9 — which is how a Medium Motor ends up able to raise something it could never shift directly. This is also how a gearbox with a sensible number of parts reaches a ratio that a single pair never could: a 40-tooth gear driven by an 8 is 1:5, and doing it twice is 1:25.
Only the first and last gear affect the ratio. Anything in the middle passes the motion along and changes nothing but the direction — which is a whole idea of its own, in Changing the direction of a turn.
Every mesh loses a little to friction, so a long train is less efficient than a short one. Gearing down far enough to lift a heavy load also makes the mechanism slow, and slow is not always acceptable. And a gear train that is geared down hard is very hard to turn backwards by hand, which is either a useful brake or a nuisance depending on what you are building.
A bicycle is the same idea with a chain instead of teeth in mesh: the low gear that gets you up a hill is turning the back wheel slowly and pushing hard, and the high gear you use going downhill does the opposite. Cars, drills, cranes and clocks are all making the same trade.
Say this back before you move on: “One change, then measure.”
| Part | What it is doing here |
|---|---|
| EV3 Intelligent Brick | The stopwatch. It is the one part of the test that must not change all lesson. |
| Large Motor — the muscle | Moves the arm or leg. The program sets its speed and rotations. So it pushes the same way for every version you build. |
| The linkage (not electronic) | This is where all the fun is. The joints, how long the arms are, the gears. This is the one thing you will change. |
| The load (not electronic) | The thing the limb has to move. It must be the same weight, in the same place, for every run. |
Draw this on paper now. It is the real thing you make today. It matters more than the model.
Sensors go in ports 1, 2, 3, 4. Motors go in ports A, B, C, D. You cannot swap them. If you do, nothing warns you. The robot just will not work.
| Part | Port | Why this one |
|---|---|---|
| Limb motor (Large) | A | One job motor. It must stay in A for every version. If not, the program is not really the same. |
| Sensors | none | The Brick’s timer does the measuring. Nothing is plugged in for it. |
Check your own build now:
Two routes, and either is fine. USB is the reliable one and the one to fall back on when a room’s Bluetooth is busy; Bluetooth leaves the robot free to move, which some models need.
Do these in order. Naming the Brick after you go looking for it in the list is how groups end up driving each other’s robots.
EV3 until somebody changes it.EV3.The two failures, every class, every time. The Brick has gone to sleep while you were building — press the centre button to wake it. Or you have paired with the group at the next table, which is why the name matters.
The long version, including Port View and how to read the port tiles, is in the Brick & Bluetooth guide.
Pick cable or Bluetooth, and keep it all lesson. It sounds fussy. But small things like this can change your results without you noticing. A cable can pull on the moving parts. Say you switch to Bluetooth halfway. Then your afternoon results will not match your morning ones.
Now the model changes, and the program does not. One change, three runs, one row of the table. Then decide: keep it, or put it back?
Step 4 is the honest one. It is also the one people skip. Go back to the start, and get the same numbers again. That is the only proof that your test was fair. Has the baseline changed? Then something you promised to keep the same has changed.
The last run of the day should be the first one again. If it does not match, your results are just a story. They are not a measurement.
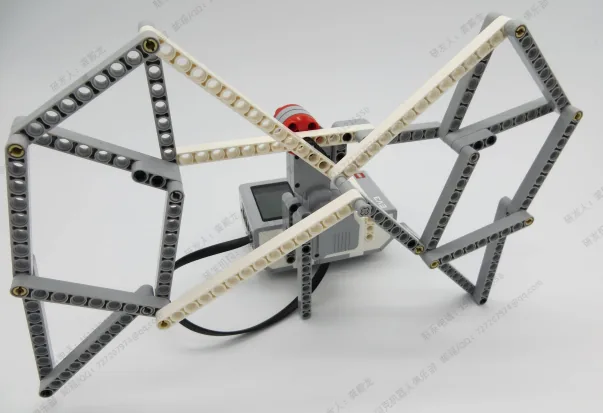
Build the model before you read any further. Everything after this is about making it do something, and none of it will make much sense with nothing on the table in front of you.
One page at a time — use Next and Previous, or the ← → keys. Fullscreen makes it big enough to build from.
Check the finished build against the picture before you switch anything on. A motor mounted the wrong way round is far easier to spot now than it is to debug later, when it looks like a program fault.
Get a good baseline. Do three runs of the model as you built it. Write them down before you touch anything.
when program starts :: events hat
clear display :: display
[A v] reset degrees counted :: motors
reset timer :: sensors
[A v] run for (5) [rotations v] at (50) % speed :: motors
write [Time:] at line (1) :: display
write (timer) at line (2) :: display
write [Degrees:] at line (4) :: display
write ([A v] degrees counted) at line (5) :: display
play beep (65) for (0.2) seconds :: sound
What success looks like: three runs with times that are close together. The degrees say about 1800 every time. Are your three baseline runs already very different? Then fix that before you change anything. A shaky measuring tool cannot spot a small change.
Does it get stuck? Then the moving parts are jamming, or the load is too heavy for the motor. That is worth knowing by itself. It may be just the thing your change should fix.
Work through them in order — each is harder than the last. The extra challenge comes after all three, and it is meant to make you plan before you build.
Add 2 touch sensors to your robot. One touch sensor makes the bionic leg move forward (clockwise). The other one makes it run backward (anticlockwise). If no touch sensor is pressed, the motor stops.
Use only one touch sensor to control the leg. The first time you press it, the bionic leg runs forward (clockwise). When you let go, the leg stops. The second time you press it, the leg runs backward (anticlockwise). Put this program in a loop. Then the third press makes it move forward. The 4th press makes it move backward, and so on. Show the motor's degree count on the screen.
Build a matching bionic leg on the other side. Change it so that when both legs run, they move the whole robot. Fix your 2 touch sensors onto the robot. Press one touch sensor, and the robot moves forward for 3 runs. Press the other one, and it moves backward. Show on the screen how many runs the robot has done. It does not matter which way it went.
Make the leg better, and prove it was you who made it better. Pick one thing you want the leg to do better. It could be faster, stronger, smoother or go further. Say which one before you begin. You cannot make everything better. If a design says it is better at everything, nobody measured it. Work in versions. Make one change per version. Do three runs per version. Write all of it in the table. Never touch the program. Keep the versions that helped. Undo the ones that did not, one at a time. Then you always know which change did what. At the end, show someone your best version. Then show them your first version. When you show it, answer two questions. What did you give up to get the better result? A machine nearly always swaps one thing for another. If you cannot name what you lost, you may not have looked. And your best version came after about four tries. What would you test next, and why that one?