Challenge 1
Work out your gear ratio two ways. First, work it out from the number of teeth. Then measure it. Turn the motor one full turn and see how far the drum moves. The two answers must agree.
Quick Learn — the model, the instructions, the program and the challenges. The theory is in Full Lesson.
EV3 Robotics›Level 2 · Intermediate›Lesson 4
Level 2 · Lesson 4 · EV3-L02-0460 minutes · Ages 8+ · Model: Strong Lifter
The Strong Lifter: a hoist, which is a machine that lifts things on a rope. It has lots of gears. With them, one EV3 motor can lift a load it could never lift on its own.
This model has the same Large Motor as the Cyclist in Lesson 3. Nothing about it has changed. It has no extra power, and it is not asked for more.
The gears did it. But they made you pay for it. Today you find out what you paid, and you measure it.
Look at how an old sailing ship steers. A person turns a wheel by hand. A row of gears joins the wheel to the rudder at the back. The whole sea pushes against that rudder.
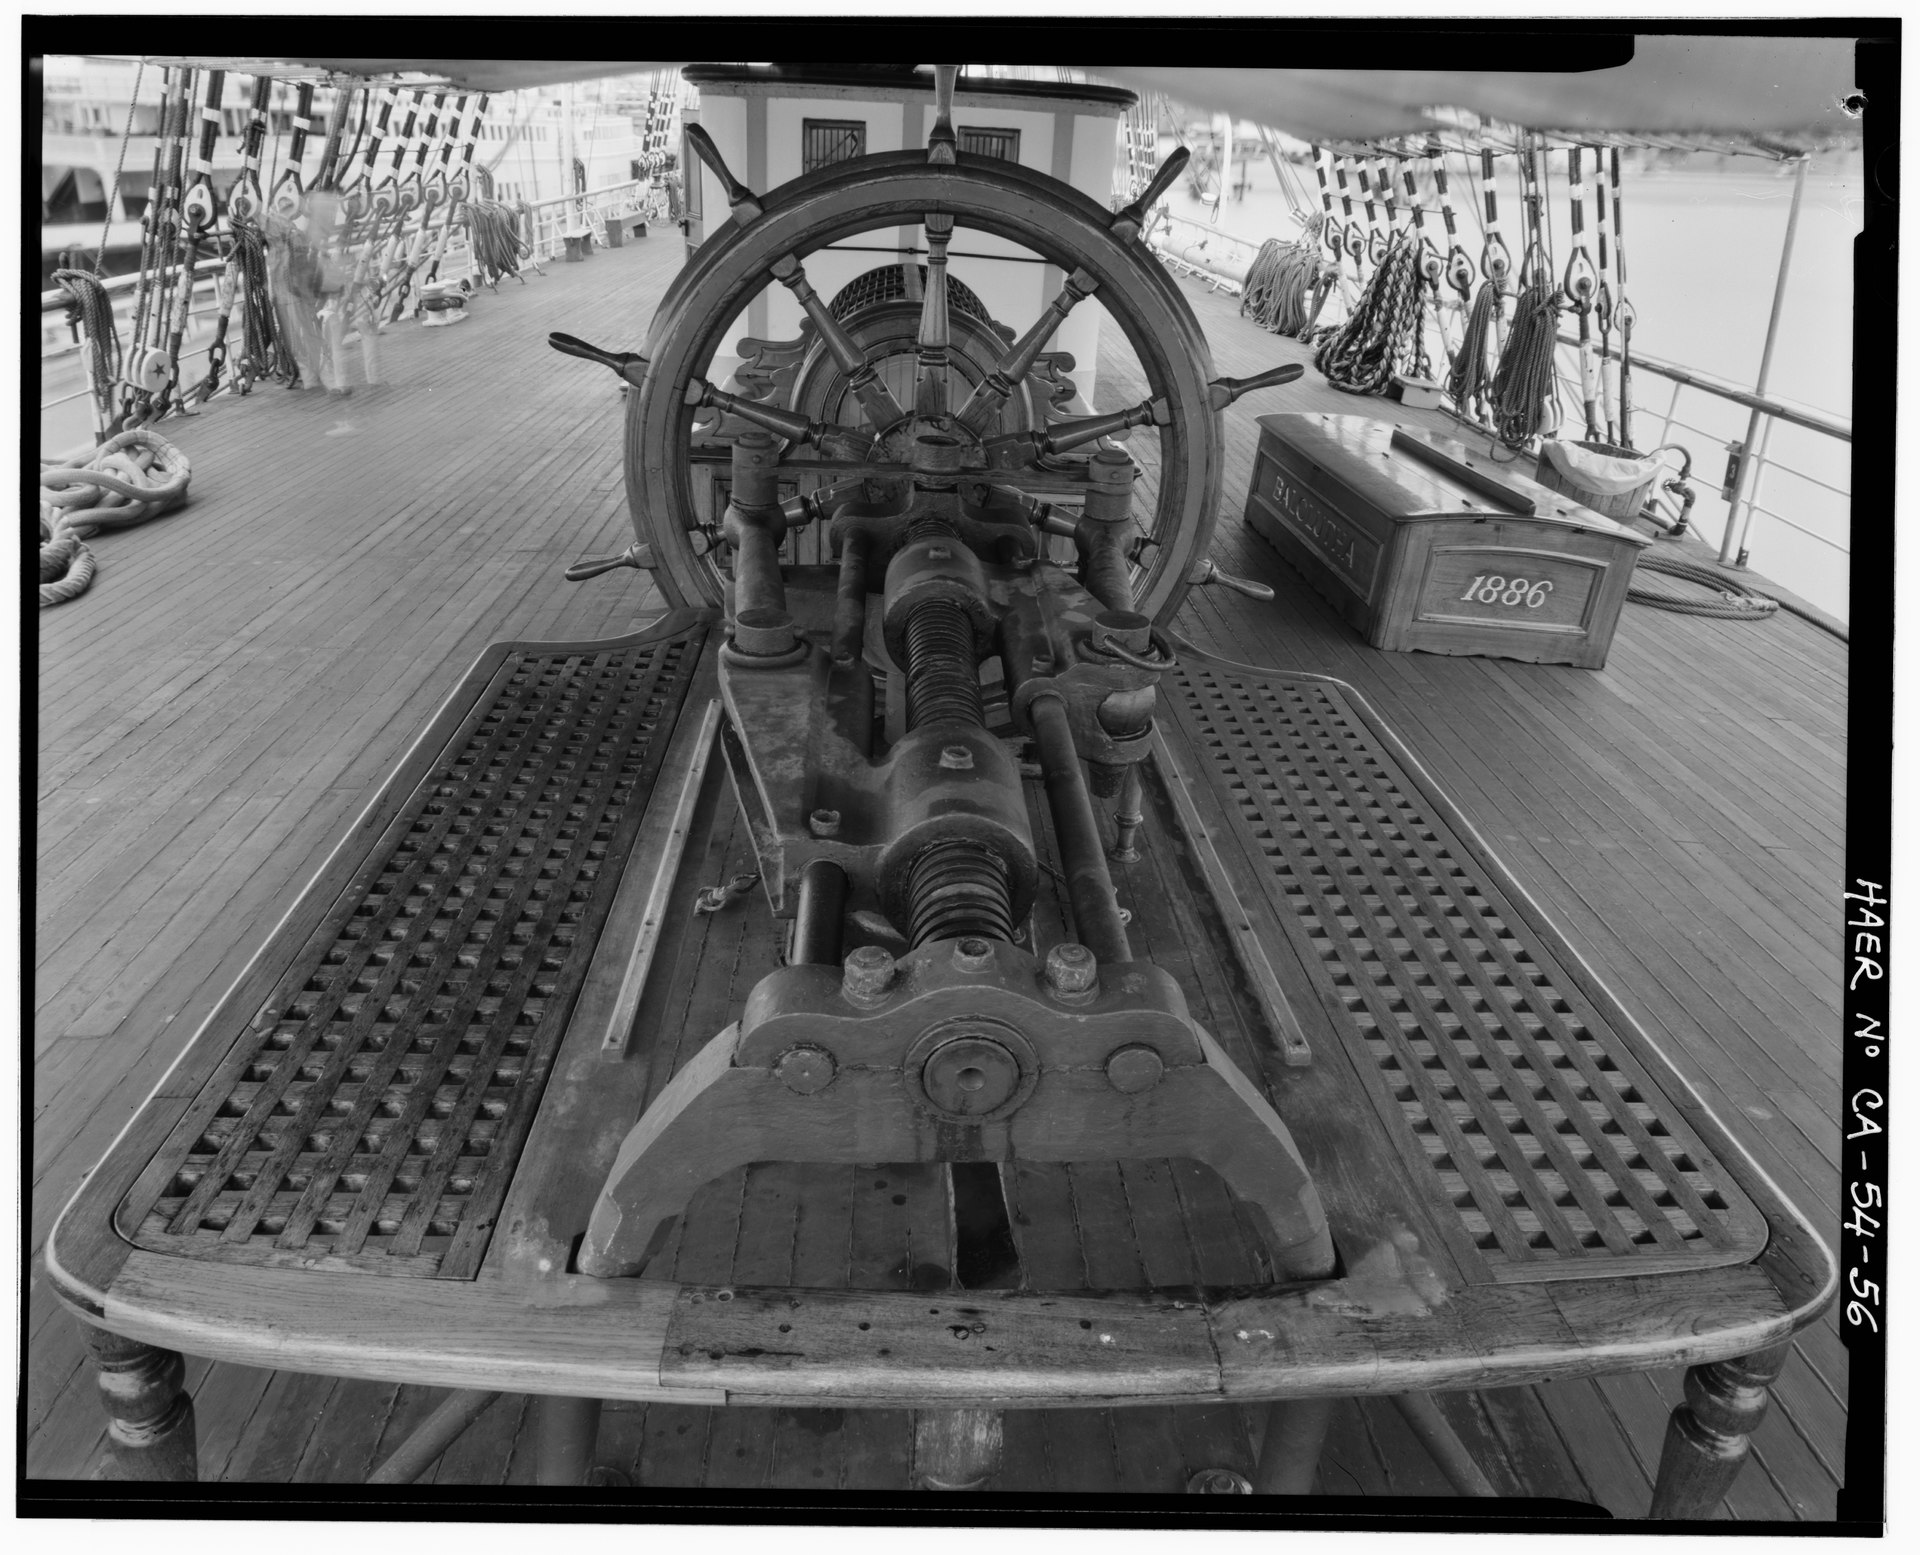
A sailor cannot push harder than the sea. So the gears are set up a special way. Many turns of the wheel move the rudder just a little. In return, a small push on the wheel becomes a huge push at the rudder. A push like this is called a force.
Nothing comes for free. The sailor does the same amount of work either way. The gears just spread it out. Turn the wheel four times instead of once, and you can push four times as hard. That is the deal, and it is always the same deal. You get more force by giving up distance. Or you get more speed by giving up force.
You see the same swap on a bike. In a low gear you can climb the hill. But your legs spin fast and you go slowly. A high gear is fast on flat ground but no good uphill. Same rider, same legs, a different swap.
Join a small motor straight to a big load. It does not move slowly. It does not move at all! It gets stuck, which is called a stall. It uses lots of power, gets hot, and in the end gives up. Gears are not just nice to have. They are what make a small motor useful.
Gears never give you something for nothing. They let you choose what to pay with.
When a small gear turns a large one, the force goes up and the speed goes down. How much depends on the number of teeth on each gear. That is called the ratio.
| Driver → driven | Ratio | Output speed | Output force |
|---|---|---|---|
| Same size | 1 : 1 | Unchanged | Unchanged |
| Small → large (8 to 24) | 1 : 3 | Three times slower | Three times stronger |
| Large → small (24 to 8) | 3 : 1 | Three times faster | Three times weaker |
Read the last two columns together. When one goes up, the other goes down. And always by the same amount. Someone says the gears made it stronger? Then ask, “How much slower?” There is always an answer.
A row of gears is called a gear train. Put two 1:3 steps in a row. You do not get 1:6. You get 1:9. Ratios multiply along a train. That is how a hoist can end up hundreds of times stronger than its motor. It is also hundreds of times slower.
Two meshed gears are a bargain. Whatever one of them gains in turns it loses in force, and whatever it loses in turns it gains in force. There is no arrangement of gears that gives you more of both, and no amount of building will find one.
Count the teeth on the gear you are turning (the driver) and the teeth on the one being turned (the follower). That is the whole calculation:
turns out = turns in × driver teeth ÷ follower teeth
An 8-tooth gear driving a 24 gives ⅓ of a turn out for every turn in — and three times the turning force. Turn the pair round and you get three turns out and a third of the force. Count the turns yourself below.
The number of teeth is the whole story. 8 teeth driving 24 means 8 ÷ 24 of a turn out for every turn in — and the force changes by exactly the opposite amount.
| Arrangement | Turns | Force | What it is for |
|---|---|---|---|
| Gearing down — small driving large | fewer | more | winches, lifts, robot arms, anything that has to move a weight |
| Gearing up — large driving small | more | less | fans, spinners, launchers, wheels on a light fast robot |
| 1 : 1 — same size | same | same | moving the drive to a different axle, or fixing a direction |
The names are worth getting right because they are backwards from what people expect: gearing down makes the output slower, not smaller, and it is the setting that makes a weak motor able to lift things.
Put several pairs in a row and the ratios multiply. Two 1:3 reductions in series give 1:9 — which is how a Medium Motor ends up able to raise something it could never shift directly. This is also how a gearbox with a sensible number of parts reaches a ratio that a single pair never could: a 40-tooth gear driven by an 8 is 1:5, and doing it twice is 1:25.
Only the first and last gear affect the ratio. Anything in the middle passes the motion along and changes nothing but the direction — which is a whole idea of its own, in Changing the direction of a turn.
Every mesh loses a little to friction, so a long train is less efficient than a short one. Gearing down far enough to lift a heavy load also makes the mechanism slow, and slow is not always acceptable. And a gear train that is geared down hard is very hard to turn backwards by hand, which is either a useful brake or a nuisance depending on what you are building.
A bicycle is the same idea with a chain instead of teeth in mesh: the low gear that gets you up a hill is turning the back wheel slowly and pushing hard, and the high gear you use going downhill does the opposite. Cars, drills, cranes and clocks are all making the same trade.
You timed things in Level 1, with the Stone Grinder. Today you add a ruler. And you make it a fair test: change one thing, and keep everything else the same. Now the swap is not just an idea. It is a number.
when program starts :: events hat
[A v] reset degrees counted :: motors
reset timer :: sensors
[A v] run for (3) [rotations v] at (50) % speed :: motors
write [Time:] at line (1) :: display
write (timer) at line (2) :: display
Every gear train is a choice about what you need more of. Say which one before you build it.
Gears do two jobs and they are worth keeping apart. One is the trade between turns and force — that is Gearing up and gearing down. The other is geometry: which way the far end turns, and about which axis.
This follows from what a tooth actually does. Where two gears touch, one tooth is pushing the other sideways — so they cannot possibly be going the same way round. Every mesh in a train flips the direction again.
A gear dropped between two others changes the direction and nothing else. Its own size cancels out — it takes exactly as much as it gives — so the ratio is still first gear ÷ last gear however big or small the middle one is.
That makes an idler the normal, sensible way to fix a direction. It costs one gear and one hole in a beam, and it is a far better answer than rewiring a motor or writing counterclockwise in half your program and forgetting it in the other half.
Watch the red marks, not the gears. Two gears meshed together can never turn the same way — everything else follows from that one fact.
Ordinary spur gears keep the two axles parallel. Some jobs need the output at right angles to the input — a motor lying flat in the chassis driving an upright turntable, or a horizontal axle driving a vertical drill.
The teeth still set the ratio in all of these. Changing the axis and changing the speed are separate decisions that happen to be made by the same pair of parts.
Two parts on the same axle turn together, at the same speed, in the same direction, with no losses. It is the simplest answer and worth reaching for first: if the motor can already do the job at its own speed and force, gears add friction, backlash and parts for nothing.
Gears earn their place when you need a different speed, a different force, a different direction, or the drive to come out somewhere the motor cannot reach.
A car’s differential is a set of bevel gears turning the drive shaft’s rotation through 90° to the wheels. A hand drill turns your horizontal cranking into vertical drilling with the same trick. Once you can see the corner, you start seeing it everywhere.
Say this back before moving on: “Stronger and slower, by the same amount.”
| Part | What it is doing here |
|---|---|
| EV3 Intelligent Brick | Times the lift. It is your measuring tool, so it must not change between tests. |
| Large Motor, the hoist | This stays the same. Same motor, same speed setting, every test. If anything is different, the gears did it. |
| The gear train (not electronic) | This is the part you change. Count the teeth on every gear in the row. The numbers are printed on the gears. You need them for your table. |
| The load (not electronic) | Something you can add to in equal steps. Bricks that are all the same are best. “Six bricks” is a measurement. “Heavy” is not. |
Sensors go in ports 1, 2, 3, 4. Motors go in ports A, B, C, D. You cannot swap them. If you do, nothing warns you. The robot just will not work.
| Part | Port | Why this one |
|---|---|---|
| Hoist motor (Large) | A | One motor with one job. Keep it in A for every version of the gear train. If not, the tests are not the same. |
| Sensors | none | The timer is inside the Brick. The count is inside the motor. |
Check your own build now:
Two routes, and either is fine. USB is the reliable one and the one to fall back on when a room’s Bluetooth is busy; Bluetooth leaves the robot free to move, which some models need.
Do these in order. Naming the Brick after you go looking for it in the list is how groups end up driving each other’s robots.
EV3 until somebody changes it.EV3.The two failures, every class, every time. The Brick has gone to sleep while you were building — press the centre button to wake it. Or you have paired with the group at the next table, which is why the name matters.
The long version, including Port View and how to read the port tiles, is in the Brick & Bluetooth guide.
Keep it the same all lesson. In a fair test, the connection is something you promise not to change. Swap it halfway through, and your early and late numbers can no longer be compared.
Only one thing changes: the gears. The program, the motor, the speed and the load steps all stay just as they are.
Step 5 is the point. You cannot make speed and force both better at once. They are two ways of using the same motor. The gears decide the swap. Nothing changes the total.
When someone says a machine is stronger, ask what it gave up. If they say “nothing”, they have not measured it.
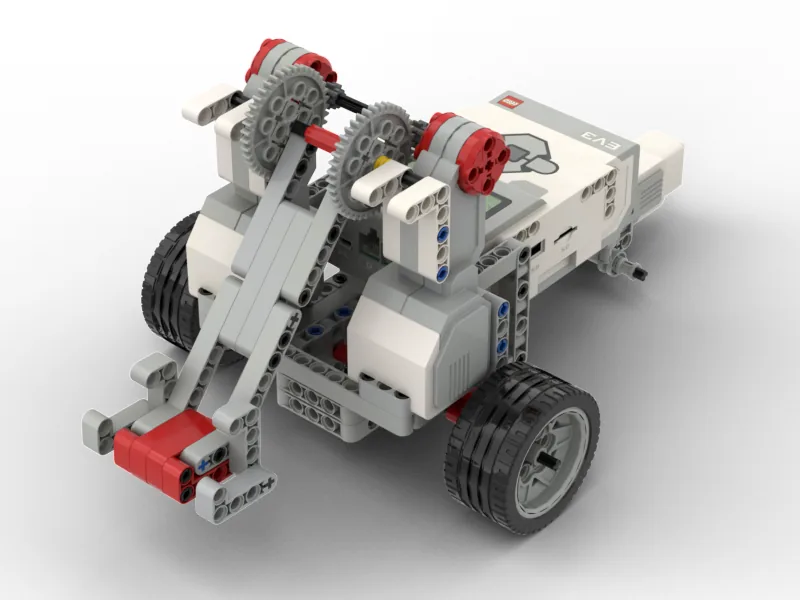
Build the model before you read any further. Everything after this is about making it do something, and none of it will make much sense with nothing on the table in front of you.
One page at a time — use Next and Previous, or the ← → keys. Fullscreen makes it big enough to build from.
Check the finished build against the picture before you switch anything on. A motor mounted the wrong way round is far easier to spot now than it is to debug later, when it looks like a program fault.
Turn the motor a set amount, and time it. Measure how high the load went. Then add weight until it will not lift any more.
when program starts :: events hat
clear display :: display
[A v] set motor to [hold position v] at stop :: motors
[A v] reset degrees counted :: motors
reset timer :: sensors
[A v] run for (3) [rotations v] at (50) % speed :: motors
write [Time:] at line (1) :: display
write (timer) at line (2) :: display
write [Degrees:] at line (4) :: display
write ([A v] degrees counted) at line (5) :: display
play beep (65) for (0.2) seconds :: sound
What success looks like: with a light load, three runs that give nearly the same time and height. The degrees read close to 1080. Now add weight, one brick at a time, all the same size. Run three times at each weight. Keep going until it stalls. The weight just before that is what this gear train can lift.
Stop as soon as it stalls. A stalled motor uses full power and turns it into heat. Take the load off. Let it rest. Write down the last weight that worked.
Work through them in order — each is harder than the last. The extra challenge comes after all three, and it is meant to make you plan before you build.
Work out your gear ratio two ways. First, work it out from the number of teeth. Then measure it. Turn the motor one full turn and see how far the drum moves. The two answers must agree.
Find the limit. Add weights one at a time. Use weights that are all the same. Do three runs with each one. Stop when the degrees reading comes up short. Write down the heaviest load your gears lifted, and how long it took.
Build a second set of gears with a different ratio. Test it the same way. Write down both ratios. Write down both times with no load, and both biggest loads. Did the trade come out the way the lesson said it would? Say so.
Design a lifter for a set job. Then say why you chose your ratio. Your teacher will give you a load and a time. Lift this much, in about this long. The fastest gears will not do. The strongest gears will not do either. The job needs one ratio in between. Your task is to find it. Work it out on paper before you build. Use what you measured in this lesson. Guess which ratio would lift that load. Guess what time that ratio would take. Write your guess down. You get marks for your thinking, as well as for the result. Then build it. Test it on the real job. When you show it, answer two questions. How close was your guessed time to the real one? If it was out, was the mistake in the ratio or in the friction? And you were given a load and a time. What would you have built if you had been given only one of them?